Alkatt/eval_LAVLA_Async_VI_100M_40k_b20_whiteblackcube_v2_2026_05_27_white_latency_bench_v7
收藏资源简介:
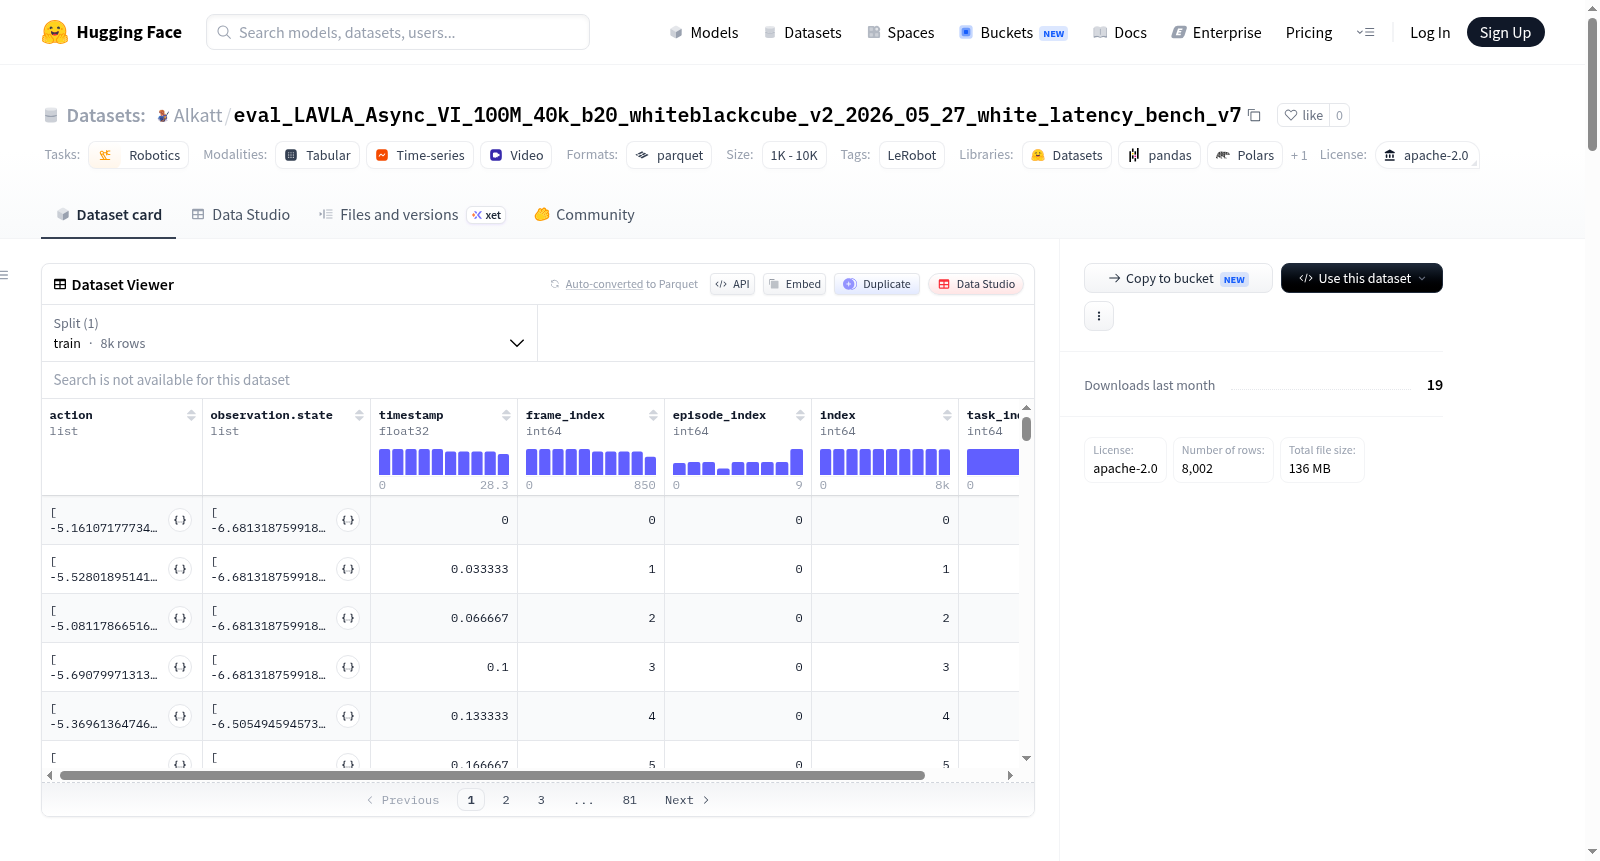
该数据集由LeRobot创建,用于机器人学任务。数据集包含10个episodes,总计8002帧,使用so_follower机器人类型。数据特征包括6维动作和状态(涉及肩部平移、肩部升降、肘部弯曲、腕部弯曲、腕部旋转和夹爪位置),以及来自三个摄像头的视频观测(camera1、camera2、camera3),每个视频分辨率为480x640,帧率为30fps,采用AV1编码。数据以parquet格式存储,总大小约为300MB(数据文件100MB,视频文件200MB),帧率为30fps,仅包含训练集。
This dataset was created using LeRobot for robotics tasks. It contains 10 episodes with a total of 8002 frames, utilizing a so_follower robot type. The features include 6-dimensional actions and states (covering shoulder pan, shoulder lift, elbow flex, wrist flex, wrist roll, and gripper positions), as well as video observations from three cameras (camera1, camera2, camera3), each with a resolution of 480x640, a frame rate of 30fps, and AV1 encoding. The data is stored in parquet format, with a total size of approximately 300MB (100MB for data files and 200MB for video files), a frame rate of 30fps, and includes only a training set.