assemble_box_with_phone_stand0430_merged
收藏资源简介:
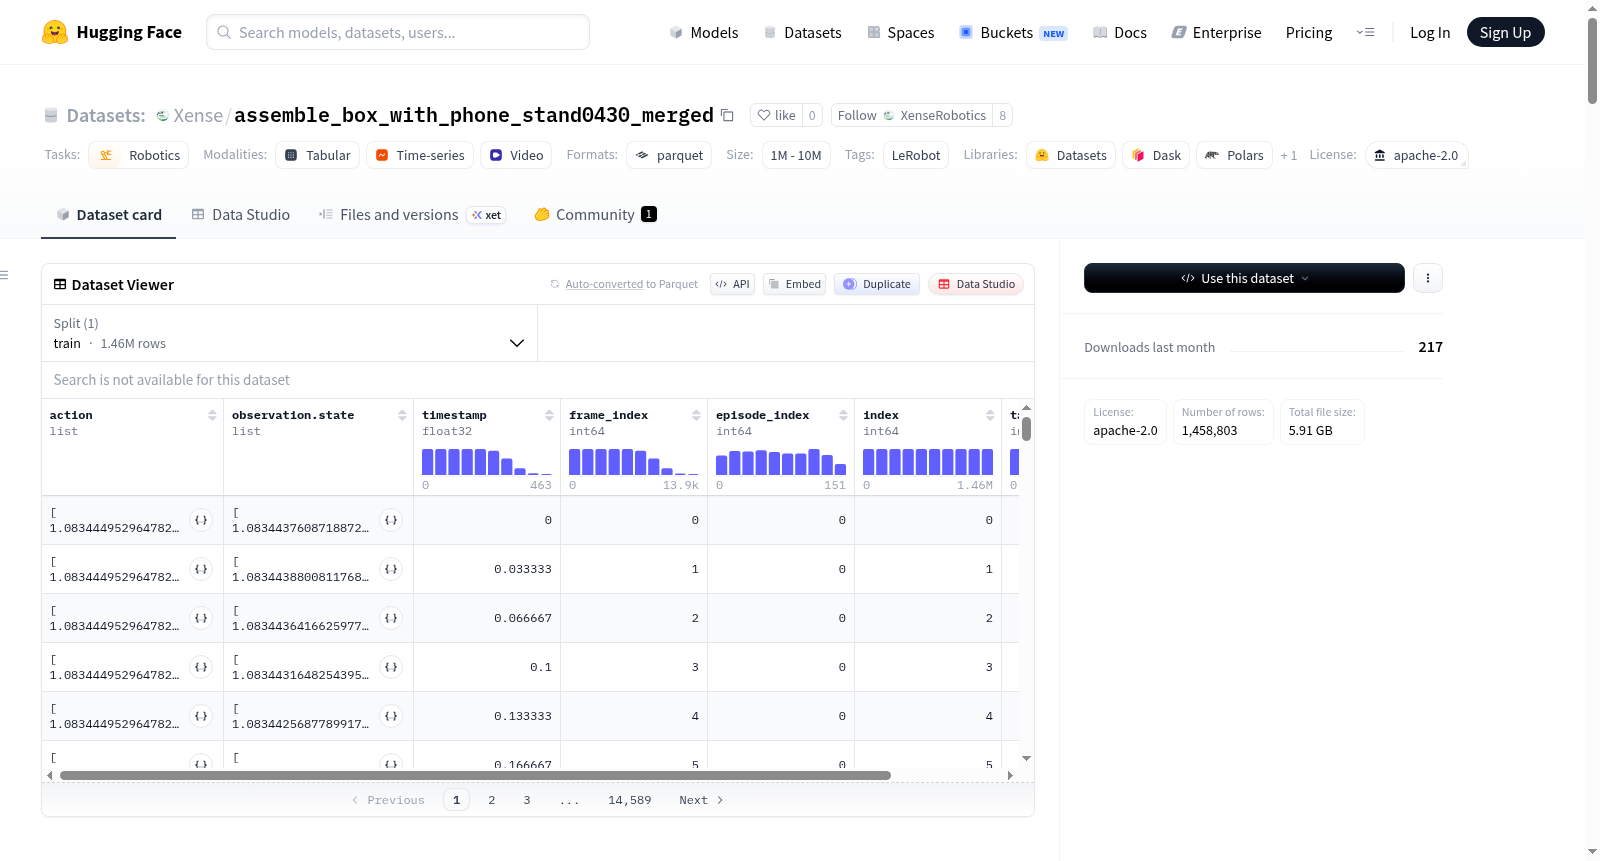
该数据集是一个机器人学数据集,使用LeRobot框架创建。它包含152个完整的操作序列(episodes),总计超过145万帧数据,采集帧率为30 FPS。数据以分块的Parquet文件格式存储,并包含关联的MP4视频文件。数据集的核心内容包括机器人执行的动作以及从多个传感器获取的观测。动作数据描述了机器人左右机械臂末端执行器(TCP)的6维位姿(位置和旋转)以及左右夹爪的开合位置,共计20个浮点数值。观测数据包含两部分:1) 状态观测:与动作数据同构,记录了同一时刻机械臂的实际状态,同样为20维浮点向量;2) 图像观测:来自五个不同视角的同步视频流,包括一个头部固定摄像头、左右腕部摄像头以及左右触觉传感器摄像头。所有视频均为彩色(RGB),头部和腕部摄像头分辨率为640x480,触觉摄像头分辨率为700x400。此外,数据集中还包含了时间戳、帧索引、episode索引等用于时序对齐和组织的元数据字段。该数据集适用于机器人模仿学习、视觉-动作策略学习、多模态感知与控制等研究任务。
This robotics dataset was developed using the LeRobot framework. It contains 152 complete manipulation episodes, totaling over 1.45 million frames of data collected at 30 FPS. The data is stored in chunked Parquet file format, with associated MP4 video files included. The core content of the dataset consists of actions executed by the robot and observations acquired from multiple sensors. The action data describes the 6-dimensional poses (position and rotation) of the robot's left and right robotic arm tool center points (TCPs), as well as the opening and closing positions of the left and right grippers, totaling 20 floating-point values. The observation data has two parts: 1) State observations: isomorphic to the action data, which record the actual states of the robotic arm at the corresponding time steps, also as 20-dimensional floating-point vectors; 2) Image observations: synchronized video streams from five distinct viewpoints, including one fixed robot head camera, left and right wrist cameras, and left and right tactile sensor cameras. All videos are in RGB color format. The resolutions of the head and wrist cameras are 640x480, while the tactile sensor cameras have a resolution of 700x400. Additionally, the dataset includes metadata fields such as timestamps, frame indices, and episode indices for temporal alignment and dataset organization. This dataset is applicable to research tasks including robotic imitation learning, vision-action policy learning, multimodal perception and control, and other related research.