DAVIAN-Robotics/dh_bucker
收藏资源简介:
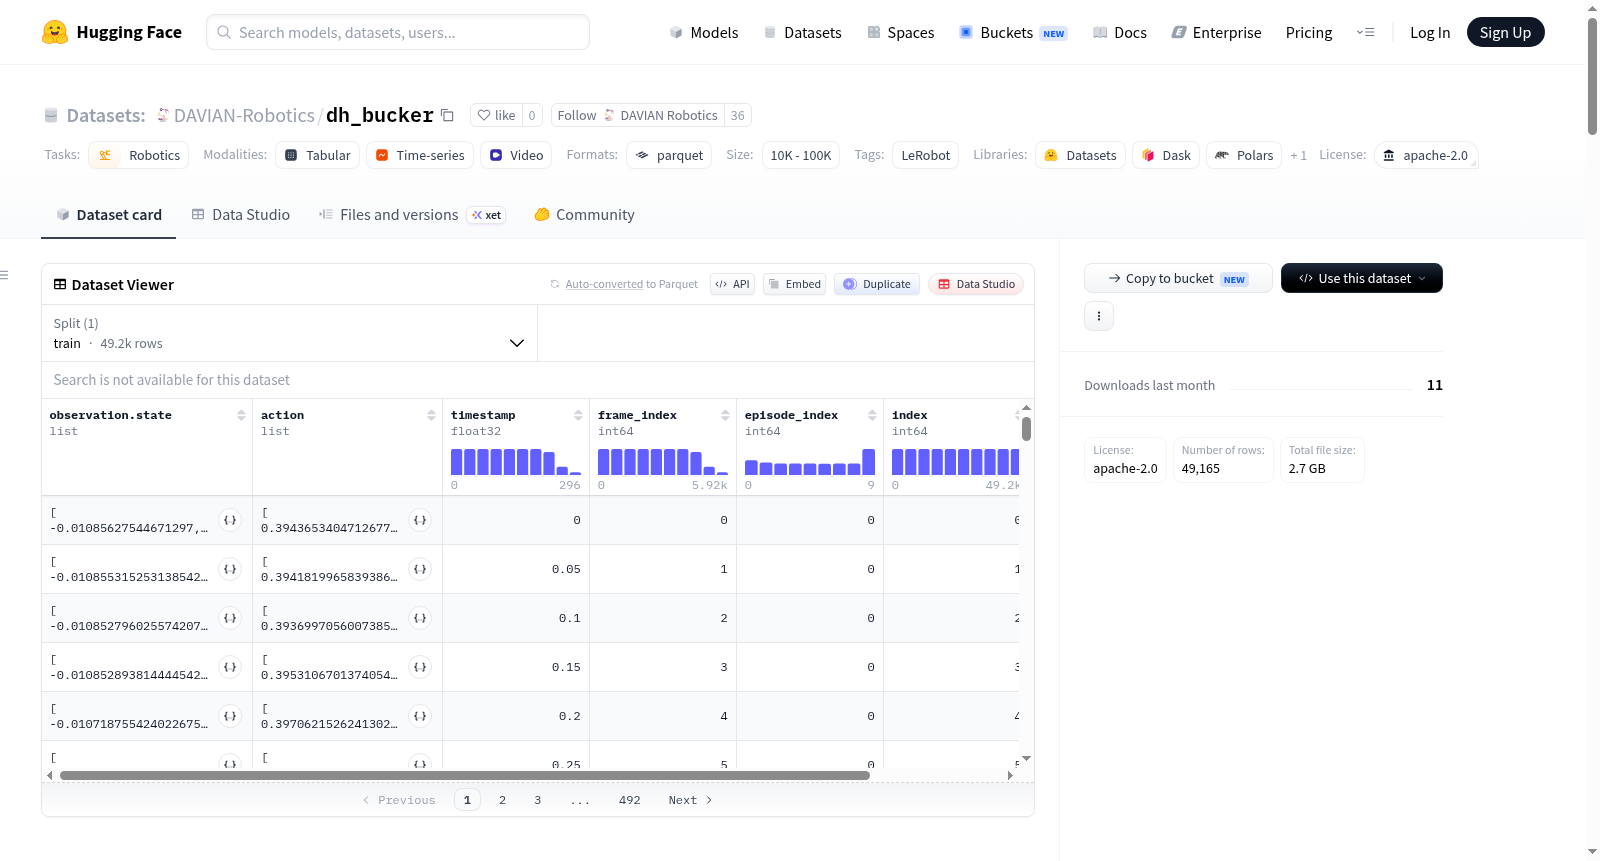
该数据集是一个机器人学习数据集,使用LeRobot工具创建。它包含10个完整的情节,总计49165帧数据,专为机器人任务设计。数据集基于Franka机器人平台,采集了多模态观测数据,包括机器人的状态(如关节位置、速度、末端执行器位姿和速度、夹爪位置和抓取状态)、动作(末端执行器位姿和夹爪控制)以及来自三个摄像头(左后、腕部和右后)的RGB视频,每个视频的分辨率为480x640,帧率为20fps。数据以Parquet格式存储,并包含时间戳、帧索引、情节索引等元数据。数据集适用于机器人控制、模仿学习或强化学习等研究任务。
This is a robotics learning dataset created using the LeRobot toolkit. It contains 10 full episodes and a total of 49,165 frames of data, specifically designed for robotics tasks. Built on the Franka robotic platform, this dataset collects multimodal observation data, including robot states (such as joint positions, joint velocities, end-effector poses and velocities, gripper positions and grasp states), actions (end-effector poses and gripper control), as well as RGB videos from three cameras: left rear, wrist, and right rear. Each video has a resolution of 480×640 and a frame rate of 20 fps. The data is stored in Parquet format, and includes metadata such as timestamps, frame indices, and episode indices. This dataset is applicable to research tasks including robotics control, imitation learning, and reinforcement learning.