shirasu206/dual_arm_ur5e_ur3e_20260530_v4
收藏资源简介:
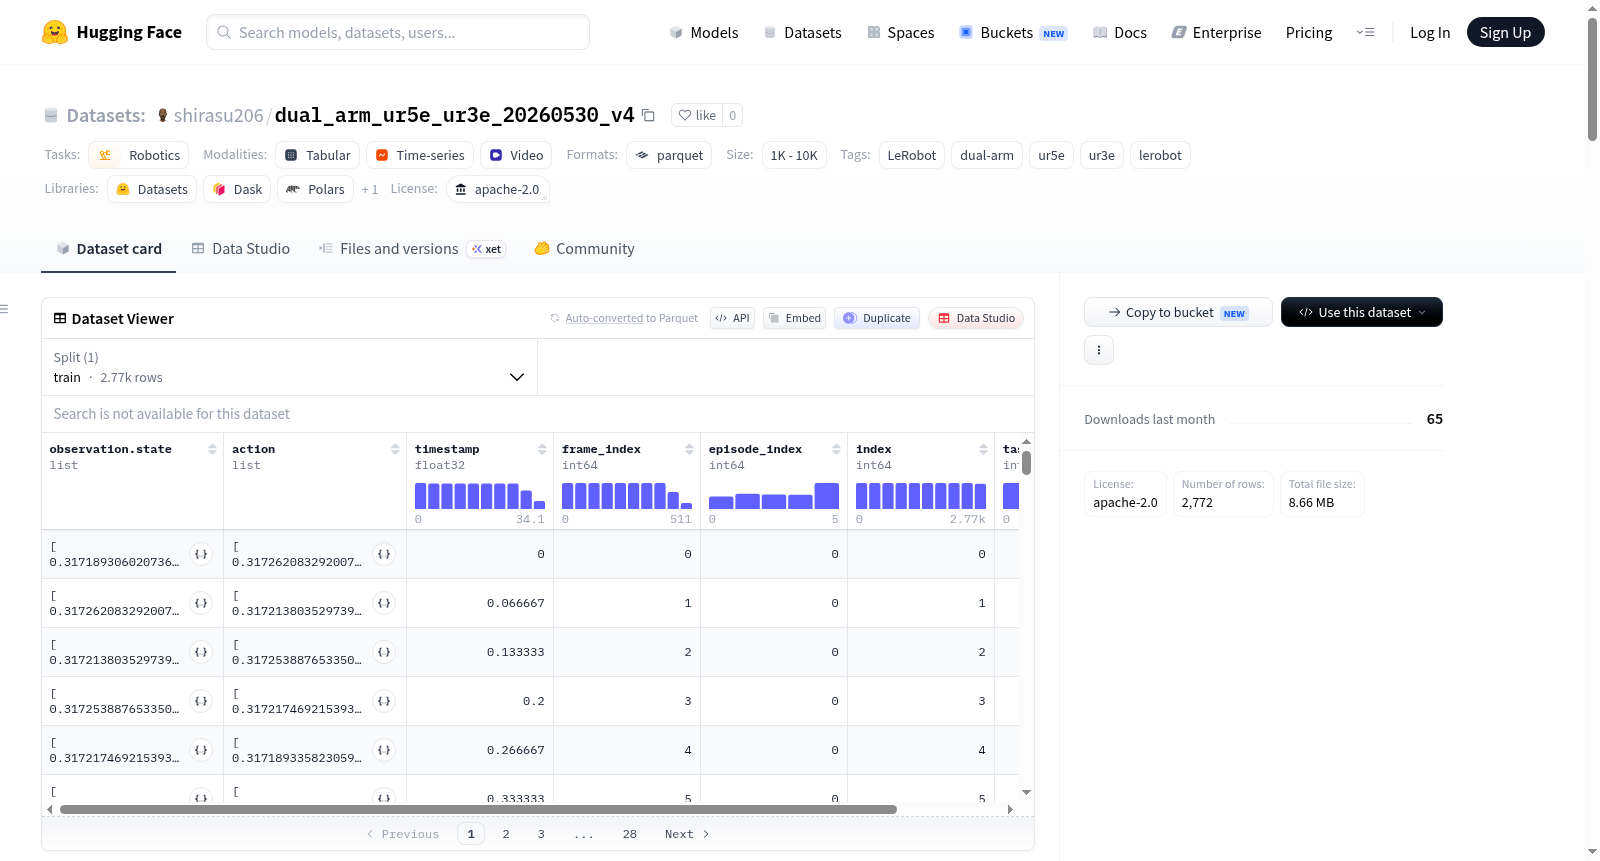
该数据集是一个机器人学数据集,专注于双UR机器人(UR5e和UR3e)的交互任务,使用LeRobot平台创建。数据集包含6个总集数,2772个总帧数,帧率为15fps,仅有一个任务类型。数据以Parquet文件格式存储,并包括视频和状态特征。观察特征包括三个视频图像:基础图像、UR5e图像和UR3e图像,每个图像的分辨率为224x224x3(高度、宽度、通道数),使用h264编码和yuv420p像素格式。状态特征是一个14维的浮点数组,表示两个机器人的关节位置和夹爪状态。动作特征也是一个14维的浮点数组,对应机器人的控制动作。其他特征包括时间戳、帧索引、集索引、索引和任务索引。数据集结构支持训练分割,所有数据用于训练。
This dataset is a robotics dataset focused on interaction tasks of dual UR robots (UR5e and UR3e), developed using the LeRobot platform. It contains 6 total episodes, 2772 total frames with a frame rate of 15 fps, and only one task type. The data is stored in Parquet file format, and includes video and state features. The observation features consist of three video images: base image, UR5e image, and UR3e image, each with a resolution of 224x224x3 (height, width, number of channels), utilizing h264 encoding and yuv420p pixel format. The state features are a 14-dimensional floating-point array representing the joint positions and gripper states of the two robots. The action features are also a 14-dimensional floating-point array corresponding to the control actions of the robots. Other features include timestamp, frame index, episode index, index, and task index. The dataset structure supports training splits, with all data used for training.