eval2_rgb_g_eval1prompt
收藏资源简介:
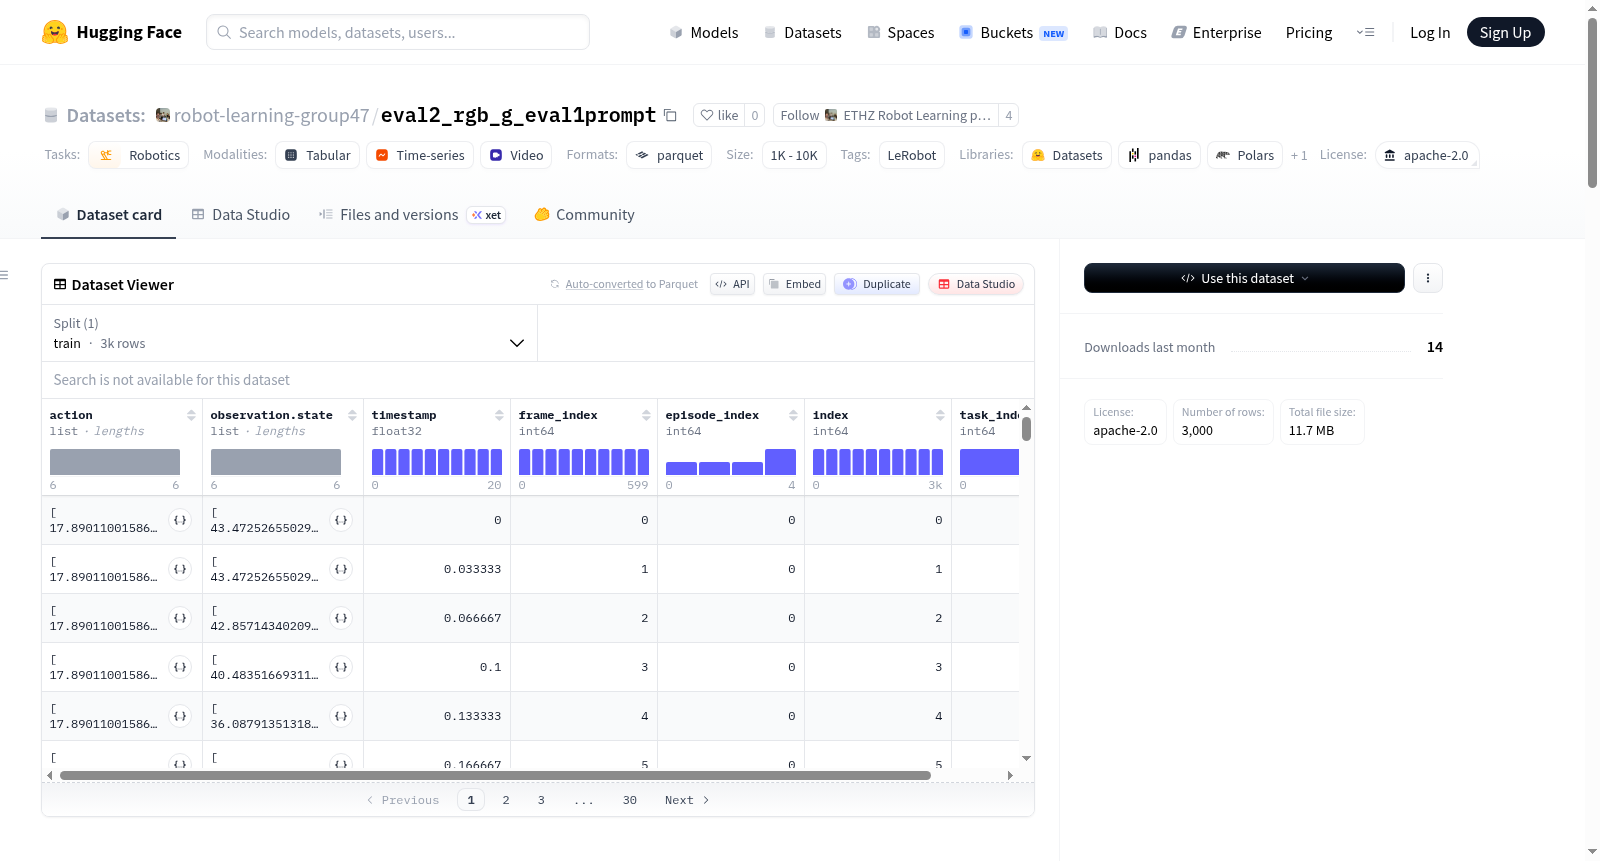
该数据集是一个机器人操作数据集,使用LeRobot工具创建。数据集包含机械臂(so_follower类型)执行任务时采集的时序数据,适用于机器人模仿学习、强化学习等任务。数据集包含5个完整的episode,总计3000帧数据,对应1个任务。数据以分块形式存储,包含两种模态:结构化数据(Parquet格式,总大小约100MB)和视频数据(MP4格式,总大小约200MB),视频帧率为30fps。每个数据样本包含以下字段:动作(action,6维浮点向量,表示机械臂的肩部平移、肩部抬升、肘部弯曲、腕部弯曲、腕部旋转和夹爪位置)、观测状态(observation.state,6维浮点向量,与动作空间相同)、前视RGB图像观测(observation.images.front,分辨率480x640,3通道)、时间戳(timestamp)、帧索引(frame_index)、episode索引(episode_index)、全局索引(index)和任务索引(task_index)。数据已划分为训练集(包含全部5个episode)。
This is a robotic manipulation dataset constructed using the LeRobot toolkit. It contains time-series data collected when a so_follower-type robotic arm executes tasks, and is applicable to robotic imitation learning, reinforcement learning and other related tasks. The dataset includes 5 complete episodes, totaling 3000 frames of data, corresponding to one single task. The data is stored in chunks and encompasses two modalities: structured data in Parquet format with a total size of approximately 100 MB, and video data in MP4 format with a total size of approximately 200 MB; the video frame rate is 30 fps. Each data sample contains the following fields: 1. action: a 6-dimensional floating-point vector representing the shoulder translation, shoulder elevation, elbow flexion, wrist flexion, wrist rotation and gripper position of the robotic arm; 2. observation.state: a 6-dimensional floating-point vector that matches the action space; 3. observation.images.front: front-facing RGB image observations with a resolution of 480x640 and 3 channels; 4. timestamp: timestamp; 5. frame_index: frame index; 6. episode_index: episode index; 7. index: global index; 8. task_index: task index. The data has been split into a training set that includes all 5 episodes.
数据集概述
数据集名称:eval2_rgb_g_eval1prompt
来源平台:Hugging Face Datasets
许可证:Apache-2.0
任务类别:机器人技术(Robotics)
创建工具:基于 LeRobot 框架构建
数据集规模与结构
- 总片段数(episodes):5
- 总帧数(frames):3000
- 任务数量:1
- 帧率(FPS):30
- 分块大小:1000
- 数据集大小:
- 数据文件:100 MB
- 视频文件:200 MB
- 数据划分:仅包含训练集(
train: 0:5),即全部5个片段用于训练
数据集组成
数据以 Parquet 文件和 MP4 视频文件存储:
| 文件类型 | 路径模式 |
|---|---|
| 数据文件 | data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet |
| 视频文件 | videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4 |
机器人类型与特征
- 机器人型号:
so_follower - 动作与状态特征(均为6维浮点向量,包含以下关节位置):
shoulder_pan.posshoulder_lift.poselbow_flex.poswrist_flex.poswrist_roll.posgripper.pos
视觉观测
- 图像键名:
observation.images.front - 分辨率:480 × 640 像素
- 颜色通道:3(RGB)
- 编码格式:AV1
- 像素格式:yuv420p
- 帧率:30 FPS
- 是否为深度图:否
其他数据字段
| 字段名 | 数据类型 | 形状 | 说明 |
|---|---|---|---|
timestamp |
float32 | [1] | 时间戳 |
frame_index |
int64 | [1] | 帧索引 |
episode_index |
int64 | [1] | 片段索引 |
index |
int64 | [1] | 全局索引 |
task_index |
int64 | [1] | 任务索引 |
引用信息
当前数据集的 BibTeX 引用信息尚未提供,标记为 [More Information Needed]。