HSP-IIT/toast_prep_merged
收藏资源简介:
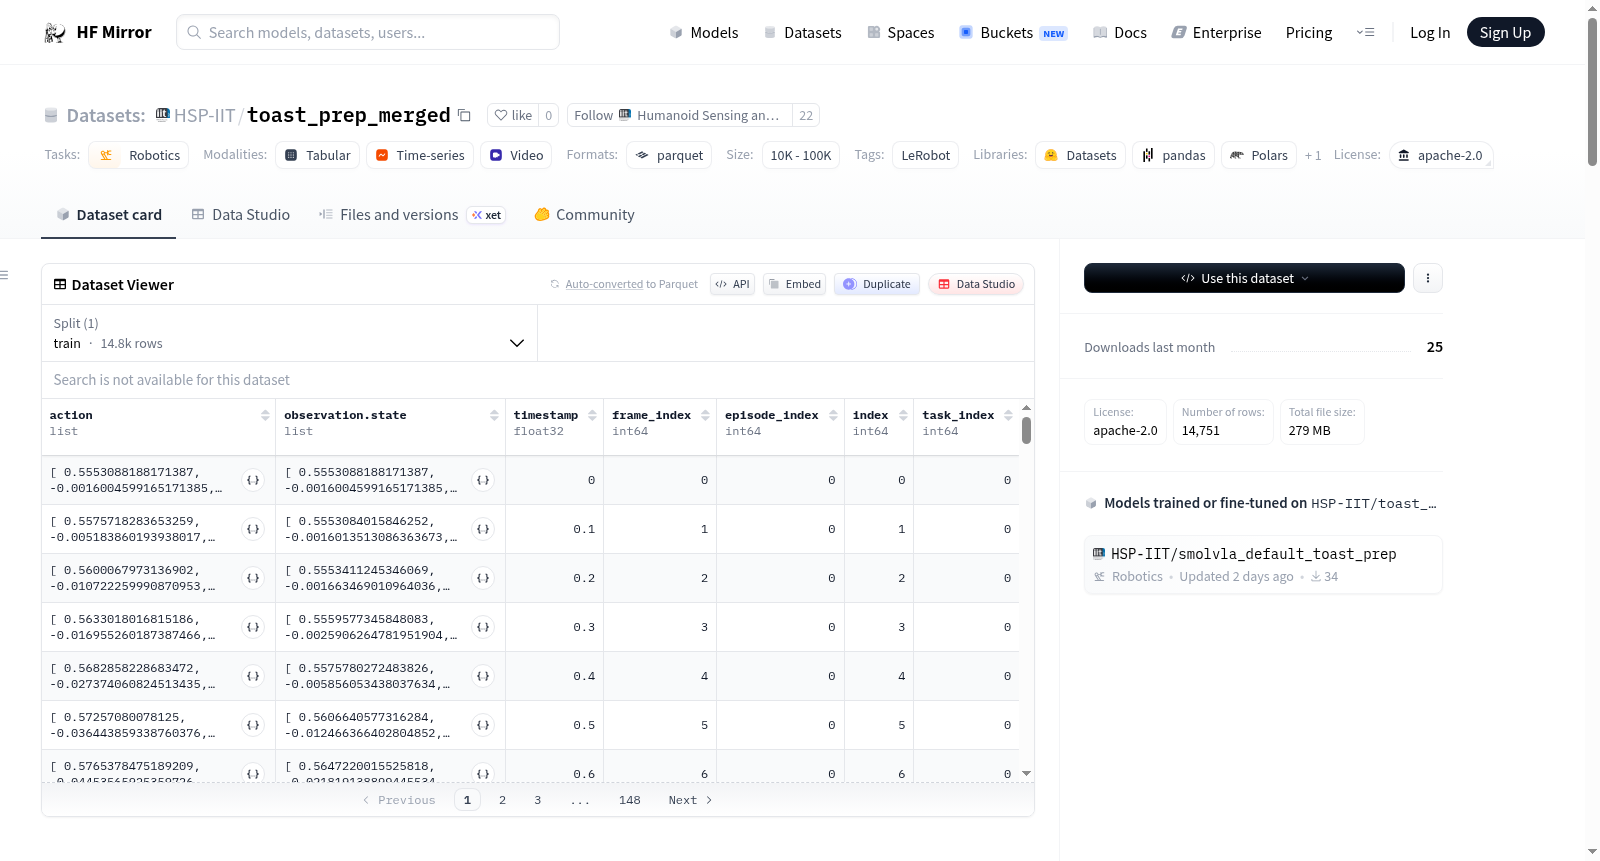
该数据集是使用LeRobot创建的机器人操作数据集,专用于多任务机器人学习。数据集包含101个episodes,总计14751帧,覆盖2个不同任务。数据以10fps的帧率采集,包括动作、观测状态、图像和时间戳等特征。动作和观测状态均包含7维浮点向量,表示机器人的位置、方向(x、y、z坐标和方向向量)和夹爪状态。图像特征包括来自手腕和左摄像头的RGB视频,分辨率为480x640,3通道,使用AV1编解码器。数据集结构分为训练集(所有episodes),数据以parquet文件存储,总大小约100MB,视频文件约200MB。机器人类型为自定义操作器,适用于机器人控制、模仿学习等研究。
This is a robotic manipulation dataset developed using LeRobot, specifically tailored for multi-task robotic learning. The dataset contains 101 episodes, with a total of 14751 frames, covering 2 distinct tasks. Data is collected at a frame rate of 10 fps, and includes features such as actions, observation states, RGB images, and timestamps. Both actions and observation states are 7-dimensional floating-point vectors, which represent the robot's position, orientation (x, y, z coordinates and orientation vector), and gripper status. The image features consist of RGB videos captured by the wrist and left cameras, with a resolution of 480x640, 3 channels, and encoded using the AV1 codec. The dataset structure is organized into a training set (all episodes), where the tabular data is stored in Parquet files with a total size of approximately 100 MB, and the video files amount to around 200 MB. The robotic platform employed is a custom manipulator, making this dataset suitable for research in areas such as robotic control and imitation learning.