Robot-obstacles-panda (ROP)
收藏资源简介:
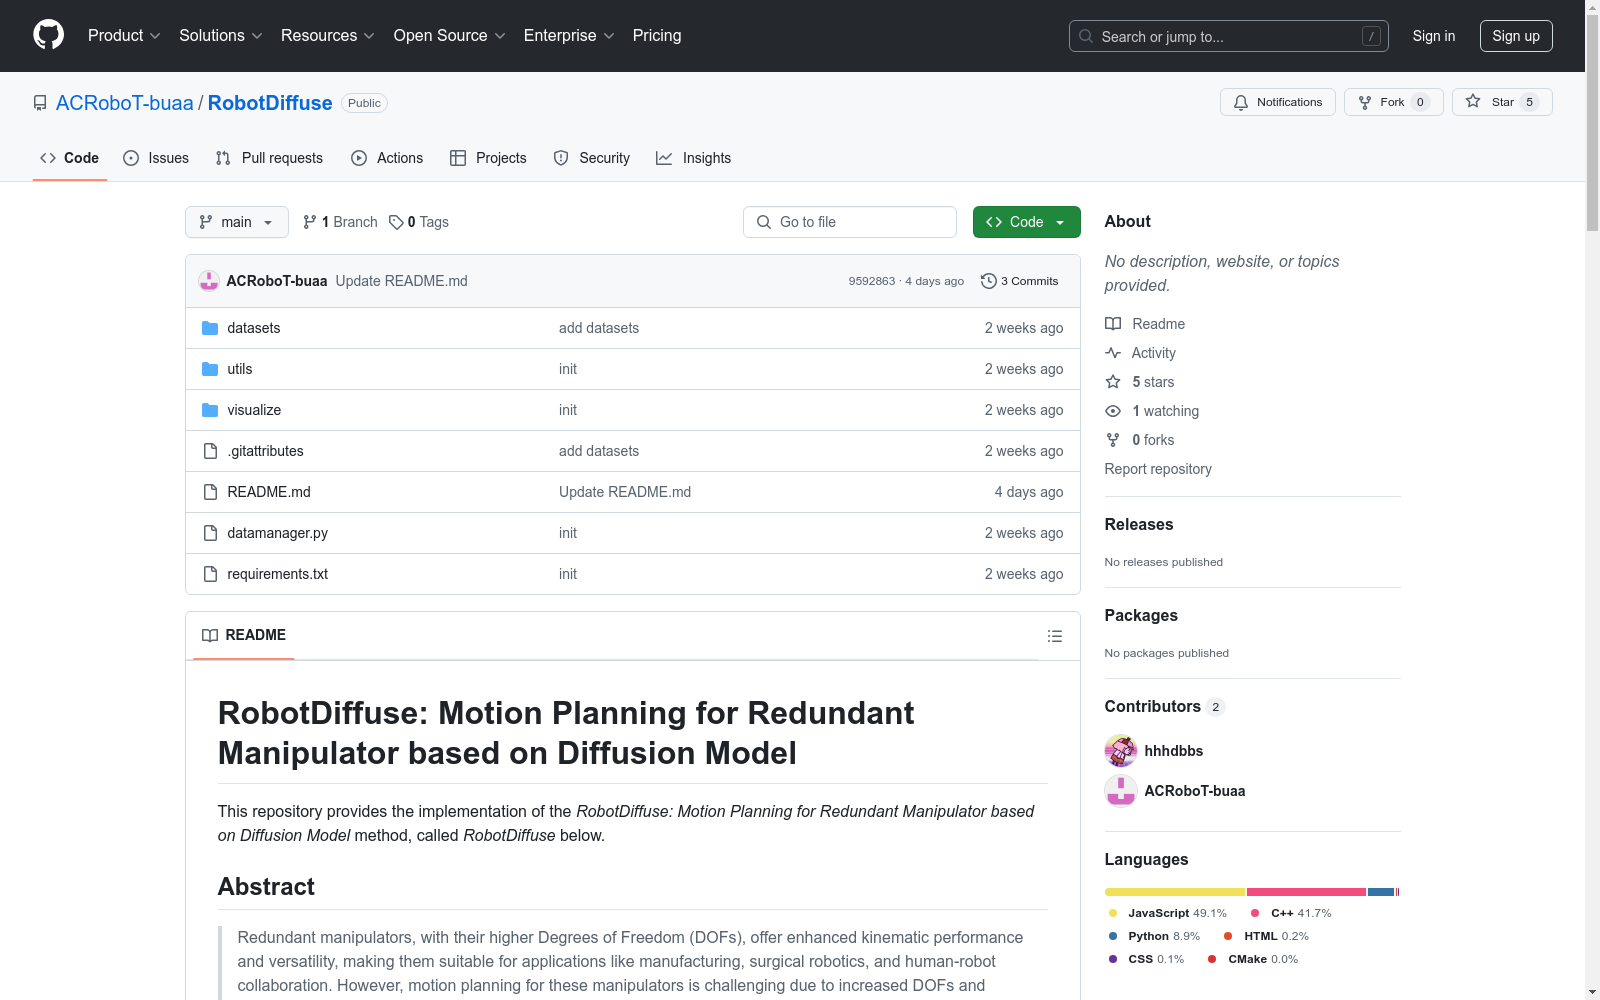
为了在更复杂的避障场景中验证我们的方法,我们特别制作了一个数据集管道,并使用Pybullet生成了Robot-obstacles-panda (ROP)数据集。该仓库还包括ROP的数据加载代码和数据生成代码。
To validate our proposed method in more complex obstacle avoidance scenarios, we specifically developed a dataset pipeline and generated the Robot-obstacles-panda (ROP) dataset using PyBullet. This repository also contains the data loading code and data generation code for the ROP dataset.
RobotDiffuse 数据集概述
数据集简介
RobotDiffuse 是一个基于扩散模型的冗余机械臂运动规划方法。该方法通过结合物理约束和点云编码器,并采用仅编码器的Transformer结构,提升了模型在捕捉时间依赖性和生成更平滑、更连贯的运动规划方面的能力。数据集包含3500万个机器人姿态和14万个避障场景。
数据集内容
- 数据生成:数据集通过Pybullet生成,包含机器人避障场景的数据生成代码和数据加载代码。
- 使用
datagen.py生成单个环境类型的数据。 - 使用
datamerge.py清理并合并数据,生成robot.npz文件。
- 使用
- 数据加载:使用
datamanager.py加载robot.npz文件,并分割训练集和验证集。
数据集结构
- 数据集代码:位于
datasets目录下,包含数据生成管道代码。 - 可视化代码:位于
visualize目录下,提供基于Web的轻量级可视化方案。 - 工具代码:位于
Utils目录下。
基线方法
- RRT*
- MPNet
- MPINet
- MPD
引用
如果使用该数据集或代码,请引用以下论文: bibtex @article{zhang2024robotdiffuse, title={RobotDiffuse: Motion Planning for Redundant Manipulator based on Diffusion Model}, author={Zhang, Xiaohan and Mou, Xudong and Wang, Rui and Wo, Tianyu and Gu, Ningbo and Wang, Tiejun and Xu, Cangbai and Liu, Xudong}, journal={arXiv preprint arXiv:2412.19500}, year={2024} }
相关链接