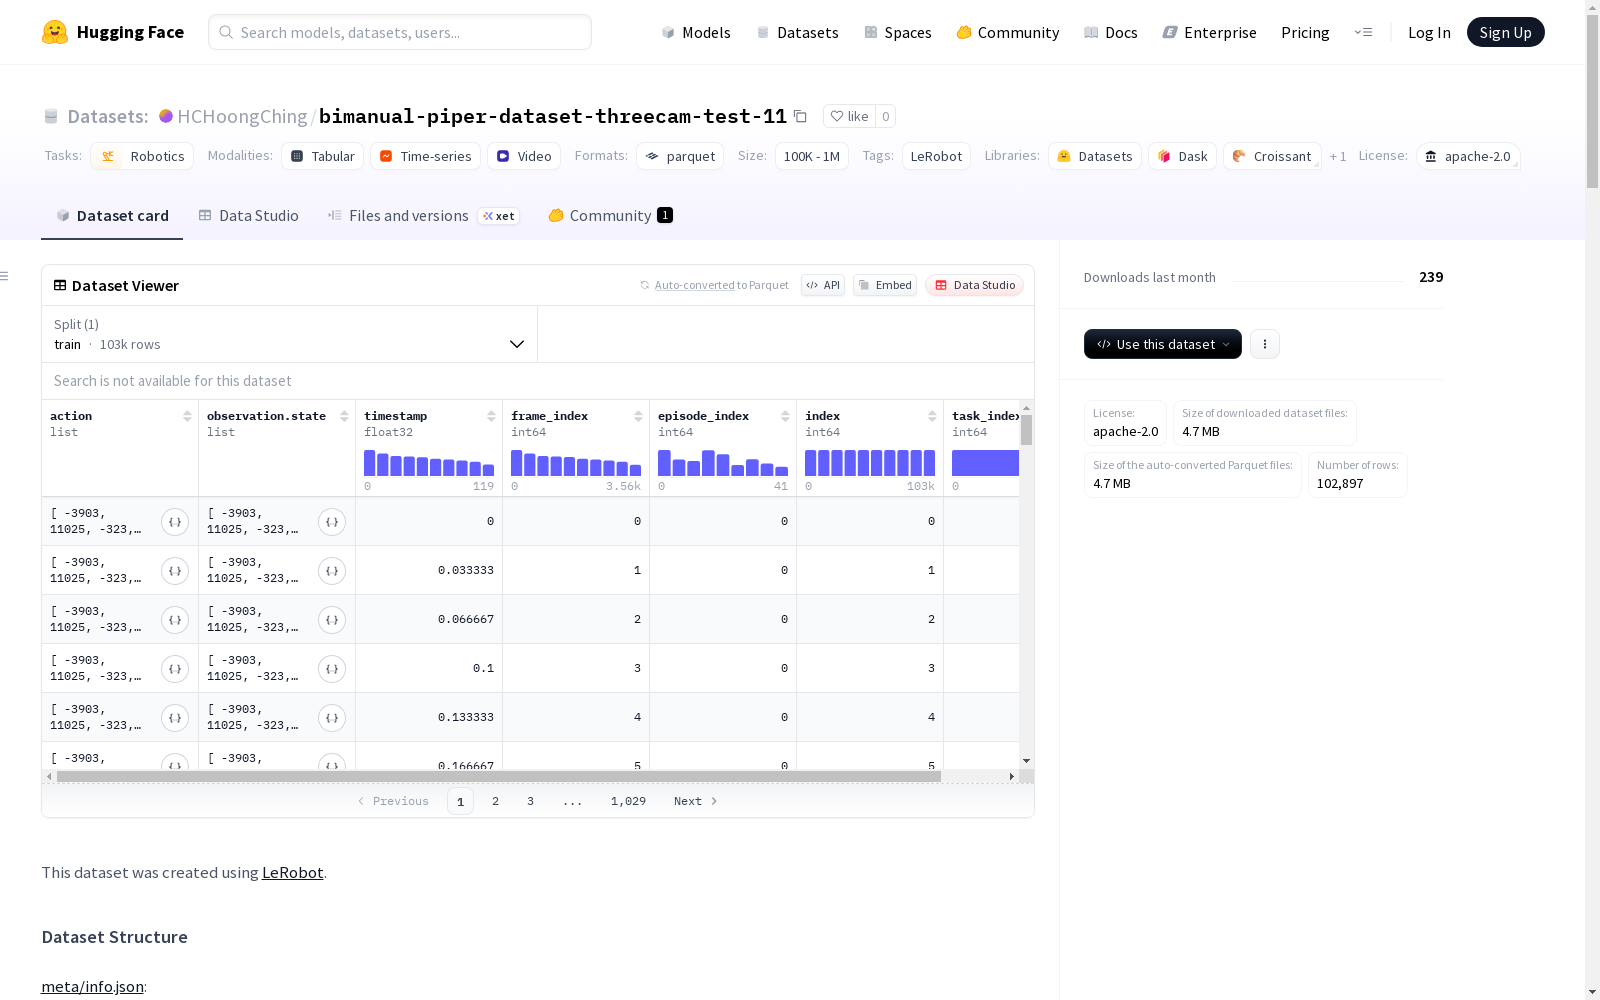
bimanual-piper-dataset-threecam-test-11
收藏资源简介:
该数据集是一个机器人技术相关的数据集,包含了一个名为bi_piper的机器人类型的数据。总共有3个剧集,10691个帧,1个任务,9个视频和1个数据块,每个数据块的大小为1000。数据集采用30帧每秒的帧率,并且数据被分为训练集。数据以Parquet文件格式存储,并包括动作、观察状态、顶部图像、右侧图像、左侧图像、时间戳、帧索引、剧集索引、索引和任务索引等特征。每个特征都有详细的数据类型、形状和名称描述。
This is a robotics-related dataset containing data for a robot type named bi_piper. It includes a total of 3 episodes, 10691 frames, 1 task, 9 videos, and 1 data block, where each data block has a size of 1000. The dataset operates at a frame rate of 30 frames per second, and the data is split into the training set. It is stored in Parquet file format and includes features such as actions, observation states, top images, right-side images, left-side images, timestamps, frame indices, episode indices, indices, and task indices. Each feature has detailed descriptions of its data type, shape, and name.
数据集概述
基本信息
- 许可证: Apache-2.0
- 任务类别: 机器人技术
- 标签: LeRobot
- 创建工具: LeRobot
数据集结构
统计信息
- 总回合数: 3
- 总帧数: 10691
- 总任务数: 1
- 总视频数: 9
- 总块数: 1
- 块大小: 1000
- 帧率: 30 FPS
- 分割: 训练集包含所有3个回合
数据特征
动作特征
- 数据类型: float32
- 维度: 14
- 关节位置:
- 左机械臂: joint_1至joint_6,gripper
- 右机械臂: joint_1至joint_6,gripper
观测特征
状态观测
- 数据类型: float32
- 维度: 14
- 关节位置:
- 左机械臂: joint_1至joint_6,gripper
- 右机械臂: joint_1至joint_6,gripper
图像观测
- 顶部摄像头:
- 分辨率: 240×320×3
- 视频编码: AV1
- 像素格式: yuv420p
- 非深度图
- 右侧摄像头:
- 分辨率: 240×320×3
- 视频编码: AV1
- 像素格式: yuv420p
- 非深度图
- 左侧摄像头:
- 分辨率: 240×320×3
- 视频编码: AV1
- 像素格式: yuv420p
- 非深度图
元数据特征
- 时间戳: float32
- 帧索引: int64
- 回合索引: int64
- 索引: int64
- 任务索引: int64
机器人类型
- 机器人型号: bi_piper
代码库版本
- 版本: v2.1
数据格式
- 数据文件: Parquet格式
- 数据路径: data/chunk-{episode_chunk:03d}/episode_{episode_index:06d}.parquet
- 视频路径: videos/chunk-{episode_chunk:03d}/{video_key}/episode_{episode_index:06d}.mp4