gsethia08/part1-fidget_magnetic_spinner_rings
收藏资源简介:
--- license: apache-2.0 task_categories: - robotics tags: - LeRobot configs: - config_name: default data_files: data/*/*.parquet --- This dataset was created using [LeRobot](https://github.com/huggingface/lerobot). <a class="flex" href="https://huggingface.co/spaces/lerobot/visualize_dataset?path=gsethia08/part1-fidget_magnetic_spinner_rings"> <img class="block dark:hidden" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl.svg"/> <img class="hidden dark:block" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl-dark.svg"/> </a> ## Dataset Description - **Homepage:** [More Information Needed] - **Paper:** [More Information Needed] - **License:** apache-2.0 ## Dataset Structure [meta/info.json](meta/info.json): ```json { "codebase_version": "v3.0", "robot_type": "hand", "total_episodes": 1075, "total_frames": 847368, "total_tasks": 26, "chunks_size": 1000, "data_files_size_in_mb": 100, "video_files_size_in_mb": 200, "fps": 30, "splits": { "train": "0:1075" }, "data_path": "data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet", "video_path": "videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4", "features": { "observation.camera.ego": { "dtype": "video", "shape": [ 1080, 1920, 3 ], "names": [ "height", "width", "rgb" ], "info": { "video.height": 1080, "video.width": 1920, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 30, "video.channels": 3, "has_audio": false } }, "observation.state": { "dtype": "float32", "shape": [ 48 ], "names": { "axes": [ "left_wrist_x", "left_wrist_y", "left_wrist_z", "left_rot_0", "left_rot_1", "left_rot_2", "left_rot_3", "left_rot_4", "left_rot_5", "left_thumb_x", "left_thumb_y", "left_thumb_z", "left_index_x", "left_index_y", "left_index_z", "left_middle_x", "left_middle_y", "left_middle_z", "left_ring_x", "left_ring_y", "left_ring_z", "left_little_x", "left_little_y", "left_little_z", "right_wrist_x", "right_wrist_y", "right_wrist_z", "right_rot_0", "right_rot_1", "right_rot_2", "right_rot_3", "right_rot_4", "right_rot_5", "right_thumb_x", "right_thumb_y", "right_thumb_z", "right_index_x", "right_index_y", "right_index_z", "right_middle_x", "right_middle_y", "right_middle_z", "right_ring_x", "right_ring_y", "right_ring_z", "right_little_x", "right_little_y", "right_little_z" ] } }, "camera.extrinsics": { "dtype": "float32", "shape": [ 16 ], "names": { "axes": [ "extrinsic_0", "extrinsic_1", "extrinsic_2", "extrinsic_3", "extrinsic_4", "extrinsic_5", "extrinsic_6", "extrinsic_7", "extrinsic_8", "extrinsic_9", "extrinsic_10", "extrinsic_11", "extrinsic_12", "extrinsic_13", "extrinsic_14", "extrinsic_15" ] } }, "camera.intrinsics": { "dtype": "float32", "shape": [ 9 ], "names": { "axes": [ "intrinsic_0", "intrinsic_1", "intrinsic_2", "intrinsic_3", "intrinsic_4", "intrinsic_5", "intrinsic_6", "intrinsic_7", "intrinsic_8" ] } }, "action": { "dtype": "float32", "shape": [ 48 ], "names": { "axes": [ "action_0", "action_1", "action_2", "action_3", "action_4", "action_5", "action_6", "action_7", "action_8", "action_9", "action_10", "action_11", "action_12", "action_13", "action_14", "action_15", "action_16", "action_17", "action_18", "action_19", "action_20", "action_21", "action_22", "action_23", "action_24", "action_25", "action_26", "action_27", "action_28", "action_29", "action_30", "action_31", "action_32", "action_33", "action_34", "action_35", "action_36", "action_37", "action_38", "action_39", "action_40", "action_41", "action_42", "action_43", "action_44", "action_45", "action_46", "action_47" ] } }, "language_instruction": { "dtype": "string", "shape": [ 1 ], "names": null }, "timestamp": { "dtype": "float32", "shape": [ 1 ], "names": null }, "frame_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "episode_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "task_index": { "dtype": "int64", "shape": [ 1 ], "names": null } } } ``` ## Citation **BibTeX:** ```bibtex [More Information Needed] ```
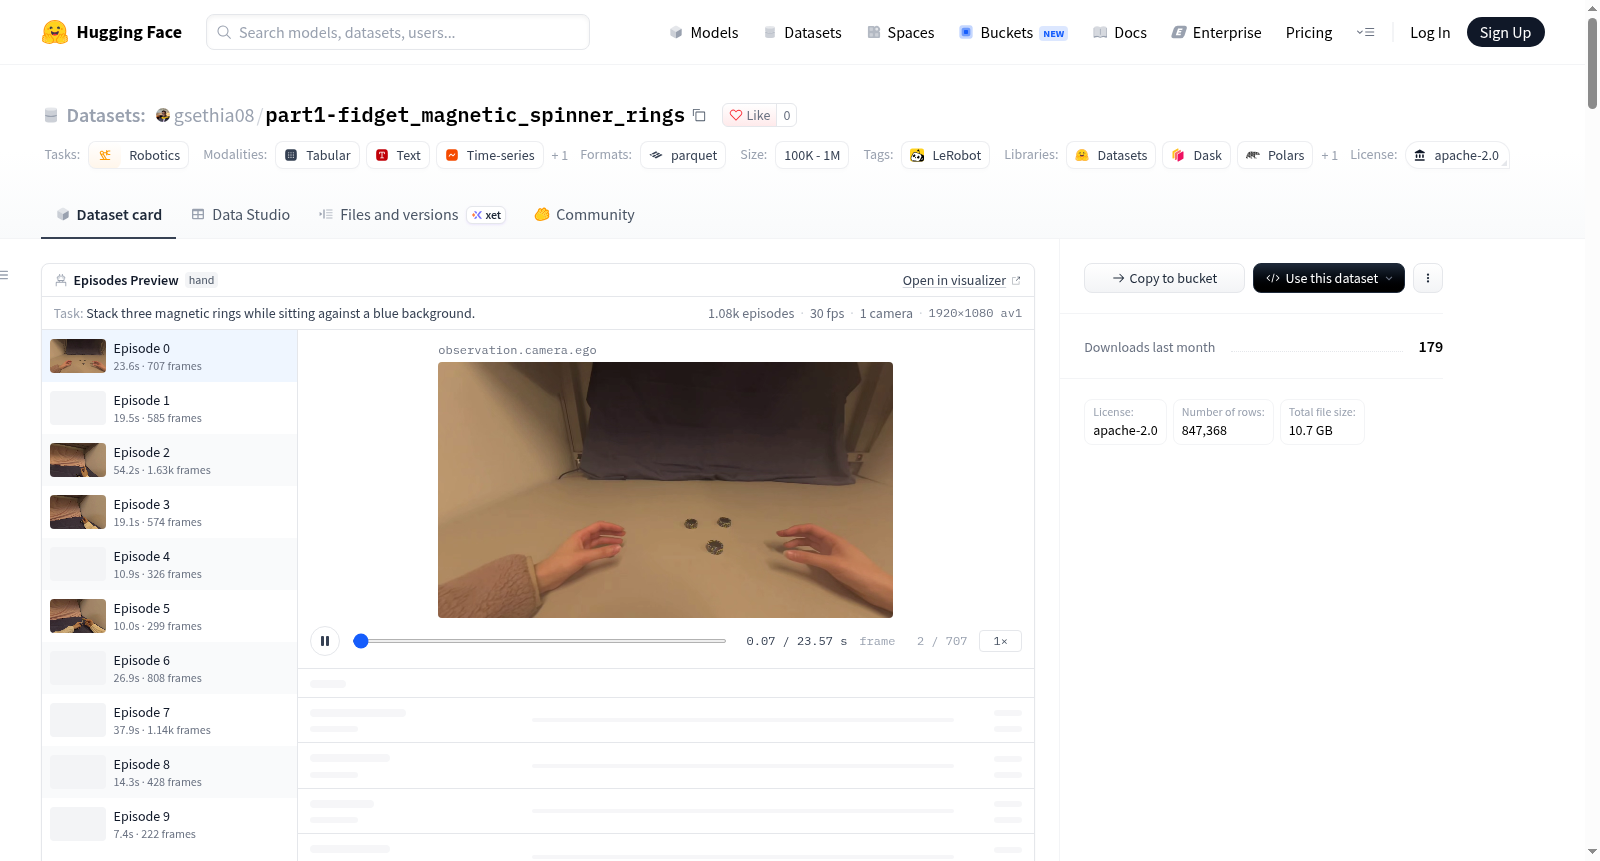
This dataset is a hand robot dataset for robotics learning, created using the LeRobot tool. It contains 1075 episodes and 847368 frames, covering 26 different tasks. The data is stored in parquet format, with videos in mp4 format at 30fps. The dataset features include observations (such as RGB camera images at 1080x1920 resolution, 48-dimensional hand state vectors), camera intrinsics and extrinsics, 48-dimensional action vectors, language instructions, timestamps, frame indices, episode indices, and task indices. All data is used for training, with no validation or test splits.