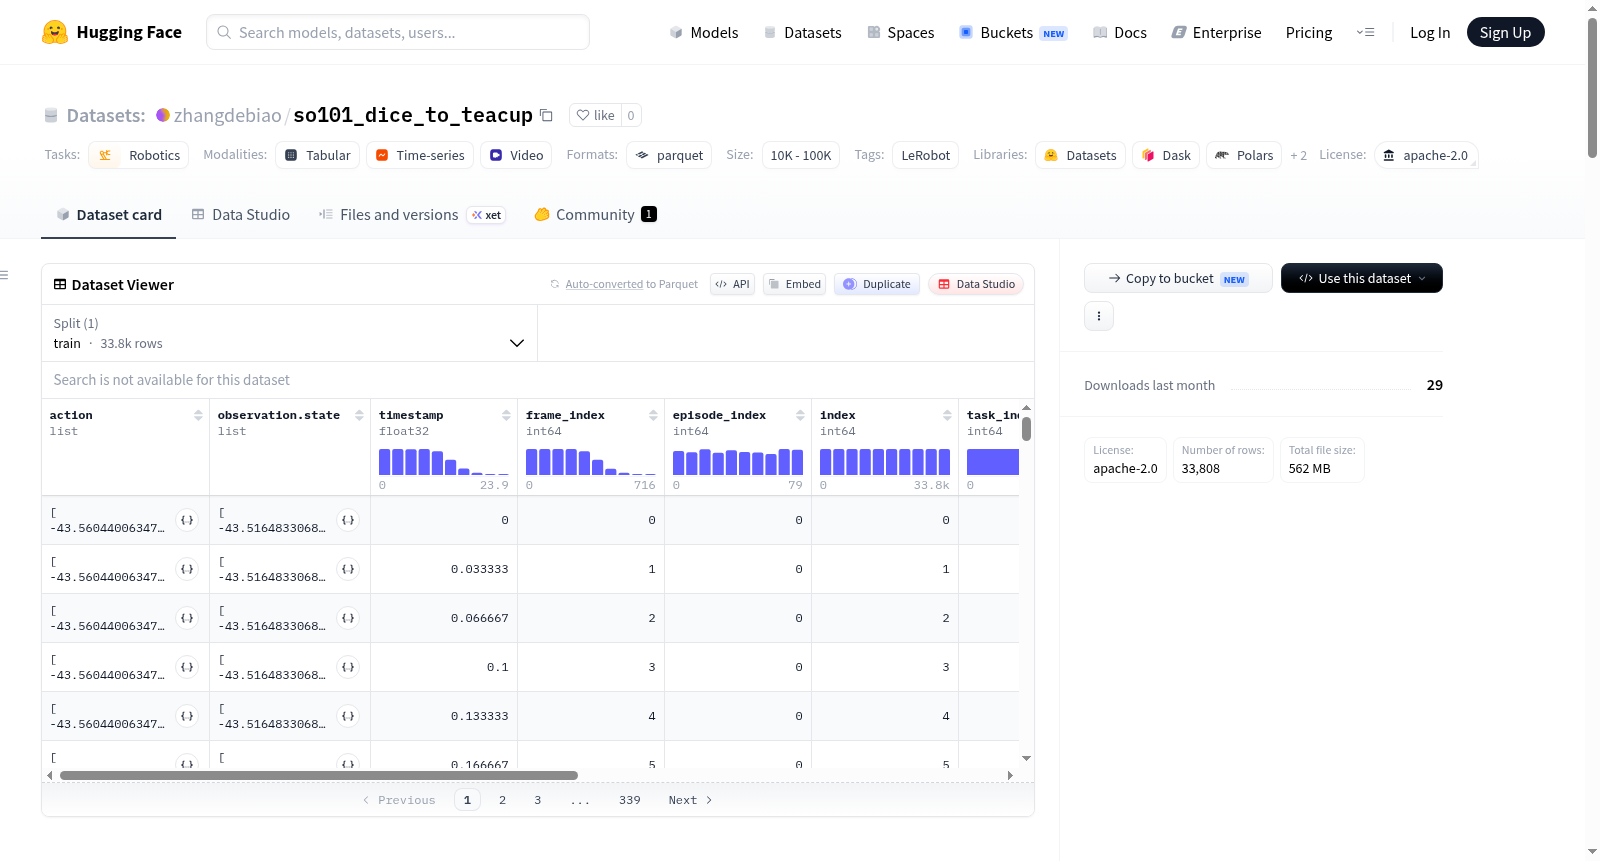
so101_dice_to_teacup
收藏资源简介:
该数据集是使用LeRobot框架创建的机器人操作数据集,主要用于机器人模仿学习、行为克隆等任务。数据集包含80个episode,共33808帧,总任务数为1。每个episode记录了机器人(so_follower类型)的6维关节动作(shoulder_pan、shoulder_lift、elbow_flex、wrist_flex、wrist_roll、gripper位置)和对应的状态观测,同时提供前视和顶视两个视角的摄像头视频(分辨率480×640,AV1编码,30fps)。数据以parquet文件存储,视频以mp4文件存储,总数据大小约100MB,视频大小约200MB。所有数据默认划分为训练集(episode 0-79)。数据集名称中的“pickplace”暗示其主要涉及拾取和放置操作。
This robotic manipulation dataset was developed using the LeRobot framework, and is mainly used for tasks such as robot imitation learning and behavioral cloning. The dataset contains 80 episodes, totaling 33,808 frames, with a total of 1 unique task. Each episode records the 6-dimensional joint actions (shoulder_pan, shoulder_lift, elbow_flex, wrist_flex, wrist_roll, and gripper position) of the so_follower-type robot, along with corresponding state observations. Additionally, it provides camera videos from two perspectives: front view and top view, with a resolution of 480×640, AV1 encoded, and 30 fps. The structured data is stored in Parquet files, while the videos are stored in MP4 files. The total size of the structured data is approximately 100 MB, and the total size of the video files is approximately 200 MB. All data is by default split into the training set (episodes 0-79). The term "pickplace" in the dataset name indicates that it primarily focuses on pick-and-place manipulation tasks.
数据集概述
- 数据集名称: so101_dice_to_teacup
- 数据集地址: https://huggingface.co/datasets/zhangdebiao/so101_dice_to_teacup
- 许可证: Apache-2.0
- 任务类别: 机器人 (robotics)
- 标签: LeRobot
数据集结构
该数据集由 LeRobot 创建,数据以 Parquet 格式存储,路径为 data/*/*.parquet。
数据规模
- 总片段数 (Episodes): 80
- 总帧数 (Frames): 33,808
- 总任务数 (Tasks): 1
- 数据文件大小: 约 100 MB
- 视频文件大小: 约 200 MB
- 训练集划分:
train包含全部 80 个片段(即0:80)
特征信息
数据集的每个样本包含以下特征:
- action (
float32, 形状[6]): 机器人动作,包含6个关节位置(shoulder_pan, shoulder_lift, elbow_flex, wrist_flex, wrist_roll, gripper) - observation.state (
float32, 形状[6]): 机器人状态观测,同样包含6个关节位置 - observation.images.front (
video, 480×640×3, 30fps, AV1编码): 前方摄像头图像 - observation.images.top (
video, 480×640×3, 30fps, AV1编码): 顶部摄像头图像 - timestamp (
float32, 形状[1]): 时间戳 - frame_index (
int64, 形状[1]): 帧索引 - episode_index (
int64, 形状[1]): 片段索引 - index (
int64, 形状[1]): 整体索引 - task_index (
int64, 形状[1]): 任务索引
机器人类型
- 机器人类型:
so_follower(SO 系列跟随机器人)
数据采集参数
- 采集帧率 (fps): 30
- LeRobot 代码版本: v3.0
- 视频编码: AV1
- 视频像素格式: yuv420p
- CRF 值: 30
引用信息
数据集的 BibTeX 引用信息目前未提供(标注为 [More Information Needed])。