u850-fridge-drink-05
收藏资源简介:
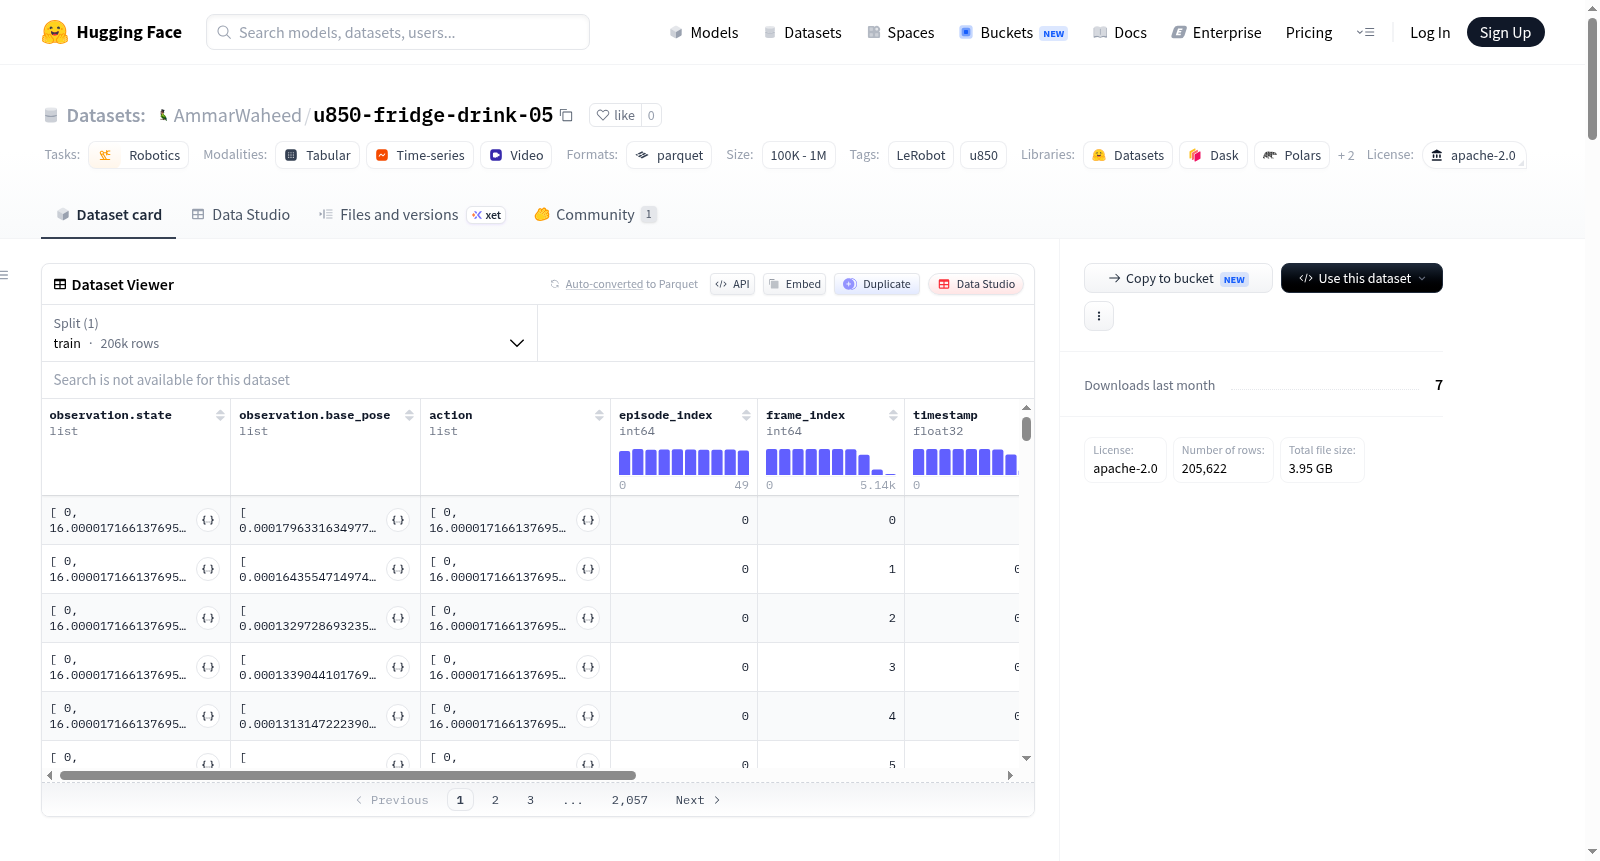
该数据集由LeRobot平台创建,专注于机器人学领域,具体针对u850型机器人。数据集包含50个episodes,总计205,622帧和150个视频,所有数据划分为训练集。数据以.parquet文件格式存储,视频为.mp4格式,帧率为50 fps。数据集结构丰富,包含多种观察和动作字段:观察部分包括机器人状态(10维浮点数组,涵盖7个关节和夹爪)、基座姿态(3维浮点数组,表示x、y和偏航角),以及来自左、右和腕部摄像头的图像(均为480x640x3的视频,采用h264编解码器)。动作字段为10维浮点数组,对应关节和夹爪控制。此外,还包含episode索引、帧索引、时间戳、下一帧完成标志、校正标志和任务索引等元数据。该数据集适用于机器人控制、模仿学习或强化学习任务,可用于训练或评估机器人行为模型。
This dataset is created by the LeRobot platform and focuses on the field of robotics, specifically targeting the u850 robot. It contains 50 episodes, totaling 205,622 frames and 150 videos, all allocated to the training set. The data is stored in .parquet file format, with videos in .mp4 format at a frame rate of 50 fps. The dataset has a rich structure, including various observation and action fields: the observation part comprises robot state (a 10-dimensional floating-point array covering 7 joints and a gripper), base pose (a 3-dimensional floating-point array representing x, y, and yaw angle), and images from left, right, and wrist cameras (all videos at 480x640x3 resolution using the h264 codec). The action field is a 10-dimensional floating-point array corresponding to joint and gripper control. Additionally, metadata such as episode index, frame index, timestamp, next frame completion flag, correction flag, and task index are included. This dataset is suitable for robot control, imitation learning, or reinforcement learning tasks, and can be used to train or evaluate robot behavior models.
数据集概要
- 数据集名称: u850-fridge-drink-05
- 许可证: Apache-2.0
- 任务类别: 机器人学 (robotics)
- 创建工具: LeRobot
- 机器人型号: u850
数据集结构
- 代码版本: v2.0
- 总集数: 50
- 总帧数: 205,622
- 总任务数: 1
- 总视频数: 150
- 总块数: 1
- 帧率 (FPS): 50
- 数据路径:
data/chunk-{episode_chunk:03d}/episode_{episode_index:06d}.parquet - 视频路径:
videos/chunk-{episode_chunk:03d}/{video_key}/episode_{episode_index:06d}.mp4 - 训练集划分: 第0至49集作为训练数据
特征字段
| 特征名称 | 数据类型 | 形状 | 说明 |
|---|---|---|---|
observation.state |
float32 | (10,) | 机器人关节状态(joint1-6 和 gripper) |
observation.images.left |
video | (480, 640, 3) | 左侧摄像头图像(H.264编码,50fps) |
observation.images.right |
video | (480, 640, 3) | 右侧摄像头图像(H.264编码,50fps) |
observation.images.wrist |
video | (480, 640, 3) | 腕部摄像头图像(H.264编码,50fps) |
observation.base_pose |
float32 | (3,) | 机器人基座姿态(base_x, base_y, base_yaw) |
action |
float32 | (10,) | 动作指令(joint1-6 和 gripper) |
episode_index |
int64 | (1,) | 集索引 |
frame_index |
int64 | (1,) | 帧索引 |
timestamp |
float32 | (1,) | 时间戳 |
next.done |
bool | (1,) | 是否结束标志 |
correction |
bool | (1,) | 修正标志 |
index |
int64 | (1,) | 索引 |
task_index |
int64 | (1,) | 任务索引 |
引用信息
- 主页: [More Information Needed]
- 论文: [More Information Needed]
- BibTeX: [More Information Needed]