ddduk/Pick_and_place_blue_box
收藏资源简介:
--- license: apache-2.0 task_categories: - robotics tags: - LeRobot configs: - config_name: default data_files: data/*/*.parquet --- This dataset was created using [LeRobot](https://github.com/huggingface/lerobot). <a class="flex" href="https://huggingface.co/spaces/lerobot/visualize_dataset?path=ddduk/Pick_and_place_blue_box_final"> <img class="block dark:hidden" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl.svg"/> <img class="hidden dark:block" src="https://huggingface.co/datasets/huggingface/badges/resolve/main/visualize-this-dataset-xl-dark.svg"/> </a> ## Dataset Description - **Homepage:** [More Information Needed] - **Paper:** [More Information Needed] - **License:** apache-2.0 ## Dataset Structure [meta/info.json](meta/info.json): ```json { "codebase_version": "v3.0", "fps": 30, "features": { "action": { "dtype": "float32", "names": [ "shoulder_pan.pos", "shoulder_lift.pos", "elbow_flex.pos", "wrist_flex.pos", "wrist_roll.pos", "gripper.pos" ], "shape": [ 6 ] }, "observation.state": { "dtype": "float32", "names": [ "shoulder_pan.pos", "shoulder_lift.pos", "elbow_flex.pos", "wrist_flex.pos", "wrist_roll.pos", "gripper.pos" ], "shape": [ 6 ] }, "observation.images.top": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 30, "video.channels": 3, "has_audio": false, "video.g": 2, "video.crf": 30, "video.preset": 12, "video.fast_decode": 0, "video.video_backend": "pyav", "video.extra_options": {} } }, "observation.images.wrist": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 30, "video.channels": 3, "has_audio": false, "video.g": 2, "video.crf": 30, "video.preset": 12, "video.fast_decode": 0, "video.video_backend": "pyav", "video.extra_options": {} } }, "timestamp": { "dtype": "float32", "shape": [ 1 ], "names": null }, "frame_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "episode_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "task_index": { "dtype": "int64", "shape": [ 1 ], "names": null } }, "total_episodes": 20, "total_frames": 8718, "total_tasks": 2, "chunks_size": 1000, "data_files_size_in_mb": 100, "video_files_size_in_mb": 200, "data_path": "data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet", "video_path": "videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4", "robot_type": "so_follower", "splits": { "train": "0:20" } } ``` ## Citation **BibTeX:** ```bibtex [More Information Needed] ```
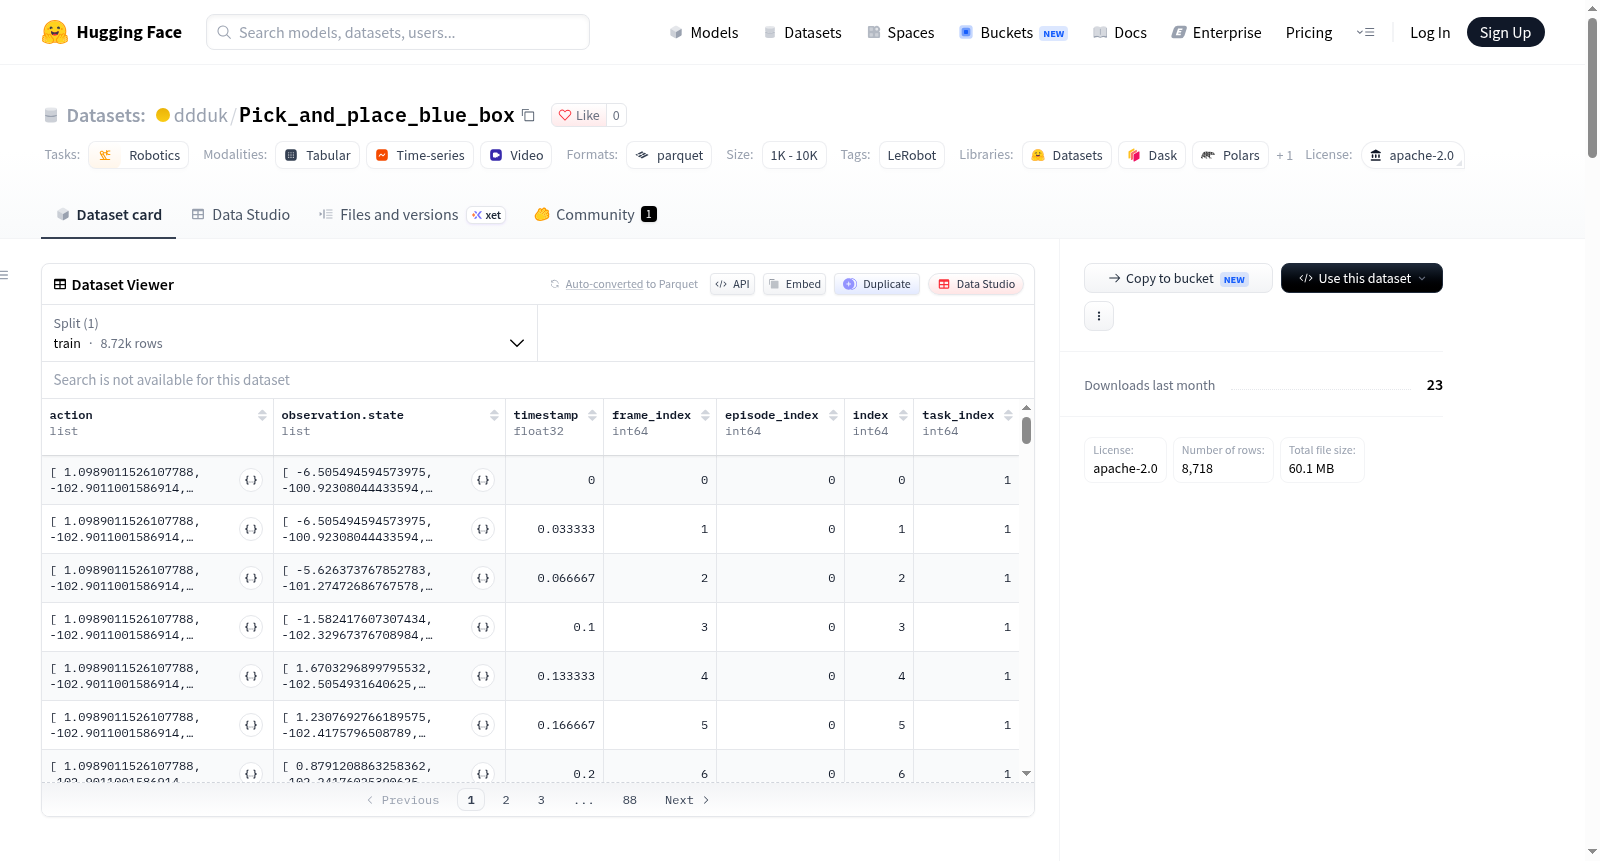
This dataset is for robotics manipulation tasks, specifically the Pick and place blue box task, created using the LeRobot tool. It includes joint position data for the robotic arm (such as shoulder pan, shoulder lift, elbow flex, wrist flex, wrist roll, and gripper positions), as well as video observations from top and wrist cameras. The data is collected at 30fps, with a total of 20 episodes, 8718 frames, and 2 tasks. The dataset structure features actions, observation states, image videos, timestamps, frame indices, episode indices, indices, and task indices, making it suitable for robotics learning and control research.