HyeonseokE/SO101-cap_fold_towel_10fps_stride3_40epi
收藏资源简介:
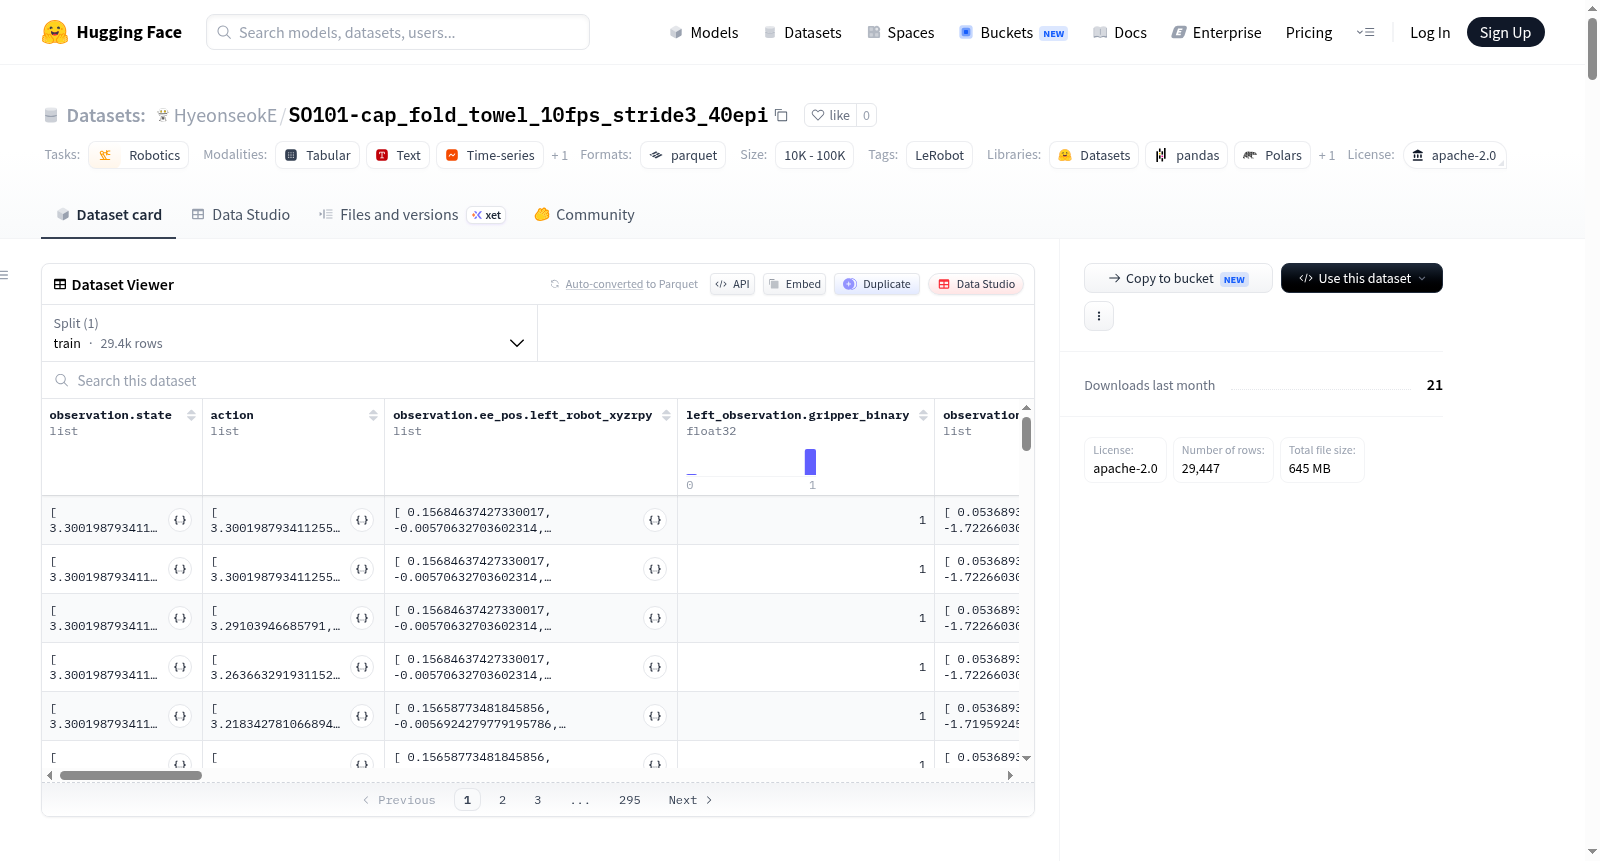
该数据集是使用LeRobot框架创建的机器人学数据集,专注于一个具体任务:折叠毛巾(cap_fold_towel)。数据集包含40个完整的情节(episodes),总计29447帧数据,帧率为每秒10帧。数据以parquet格式和视频文件存储。特征包括机器人状态观察(如左右臂的12个关节位置、末端执行器的XYZRPY坐标)、机器人动作(对应关节位置)、多视角图像观察(来自顶部摄像头、左腕摄像头和右腕摄像头的480x640分辨率RGB视频)、技能相关信息(如自然语言指令、验证问题、技能类型、进度和关节/笛卡尔空间的目标位置),以及时间戳、帧索引、情节索引等元数据。机器人类型为so101_follower,表示一个双臂机器人系统。数据集适用于机器人学习、模仿学习或强化学习任务的研究和开发。
This dataset is a robotics dataset created using the LeRobot framework, focusing on a specific task: cap_fold_towel. It contains 40 total episodes with 29,447 frames at a frame rate of 10 fps. Data is stored in parquet and video file formats. Features include robot state observations (e.g., 12 joint positions for left and right arms, end-effector XYZRPY coordinates), robot actions (corresponding joint positions), multi-view image observations (RGB videos from top, left wrist, and right wrist cameras at 480x640 resolution), skill-related information (e.g., natural language instructions, verification questions, skill type, progress, and goal positions in joint/Cartesian space), and metadata such as timestamps, frame indices, and episode indices. The robot type is so101_follower, indicating a dual-arm robot system. The dataset is suitable for research and development in robot learning, imitation learning, or reinforcement learning tasks.