ankile/real01c-insert-marker-d1-baseline-uniform-r1-25k-nocf
收藏资源简介:
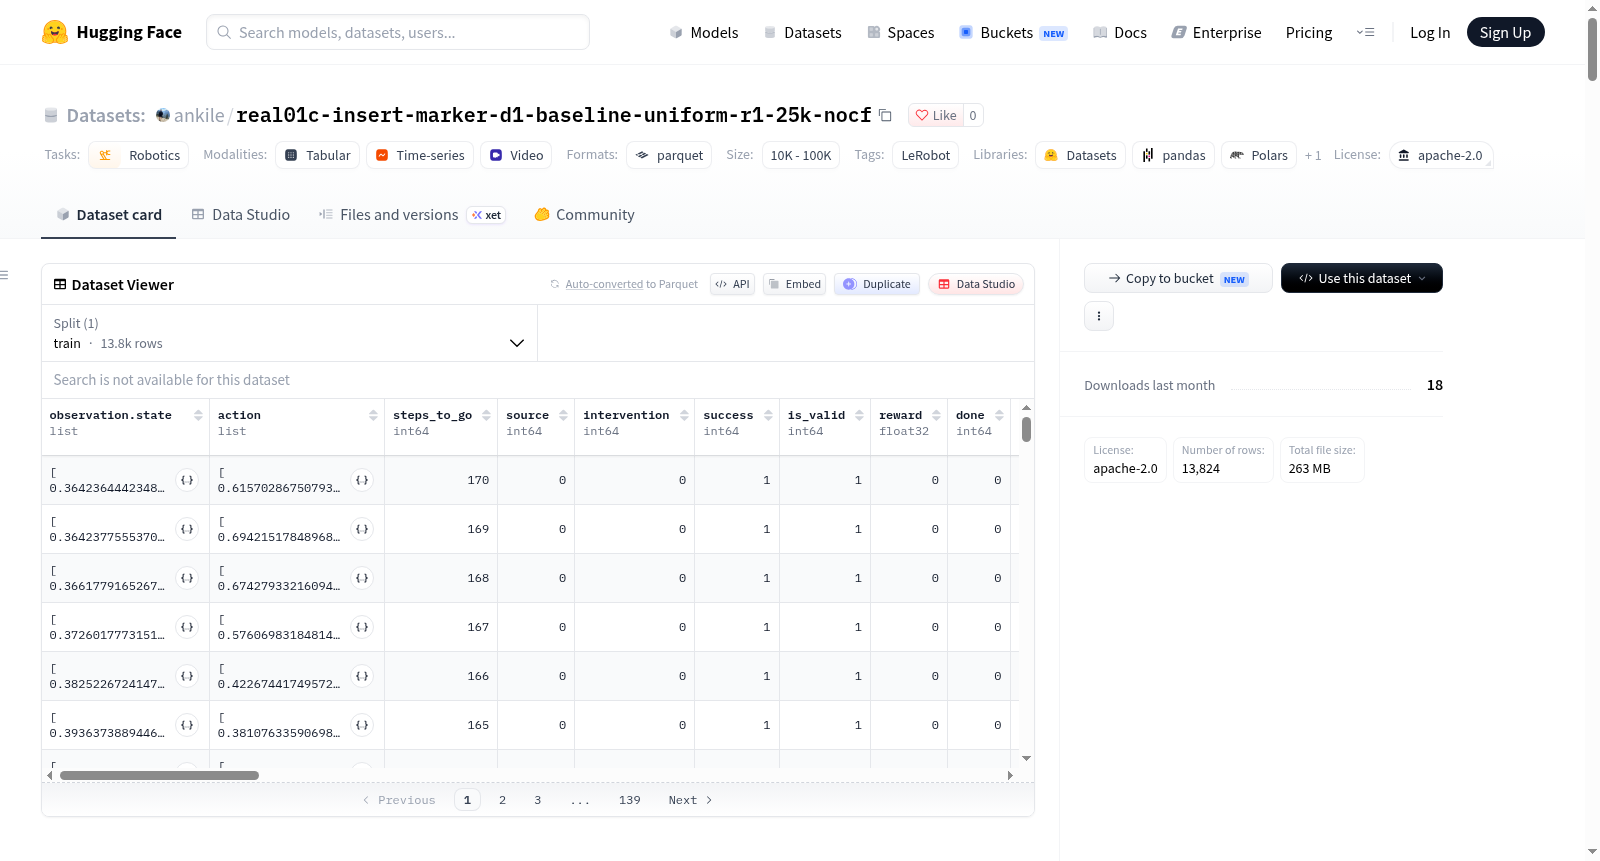
--- license: apache-2.0 task_categories: - robotics tags: - LeRobot configs: - config_name: default data_files: data/*/*.parquet --- This dataset was created using [LeRobot](https://github.com/huggingface/lerobot). ## Dataset Description - **Homepage:** [More Information Needed] - **Paper:** [More Information Needed] - **License:** apache-2.0 ## Dataset Structure [meta/info.json](meta/info.json): ```json { "codebase_version": "v3.0", "robot_type": "franka", "total_episodes": 50, "total_frames": 13824, "total_tasks": 1, "chunks_size": 1000, "data_files_size_in_mb": 100, "video_files_size_in_mb": 200, "fps": 15, "splits": { "train": "0:50" }, "data_path": "data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet", "video_path": "videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4", "features": { "observation.state": { "dtype": "float32", "shape": [ 7 ], "names": [ "cart_pos_x", "cart_pos_y", "cart_pos_z", "cart_rot_x", "cart_rot_y", "cart_rot_z", "gripper_position" ] }, "action": { "dtype": "float32", "shape": [ 7 ], "names": [ "vel_x", "vel_y", "vel_z", "vel_roll", "vel_pitch", "vel_yaw", "gripper_action" ] }, "steps_to_go": { "dtype": "int64", "shape": [ 1 ], "names": [ "steps_to_go" ] }, "source": { "dtype": "int64", "shape": [ 1 ], "names": [ "source_id" ] }, "intervention": { "dtype": "int64", "shape": [ 1 ], "names": [ "intervention_flag" ] }, "success": { "dtype": "int64", "shape": [ 1 ], "names": [ "success_flag" ] }, "is_valid": { "dtype": "int64", "shape": [ 1 ], "names": [ "is_valid_flag" ] }, "reward": { "dtype": "float32", "shape": [ 1 ], "names": [ "reward" ] }, "done": { "dtype": "int64", "shape": [ 1 ], "names": [ "done_flag" ] }, "arm_id": { "dtype": "int64", "shape": [ 1 ], "names": [ "arm_id" ] }, "policy_id": { "dtype": "int64", "shape": [ 1 ], "names": [ "policy_id" ] }, "manifest_idx": { "dtype": "int64", "shape": [ 1 ], "names": [ "manifest_idx" ] }, "pen_x": { "dtype": "float32", "shape": [ 1 ], "names": [ "pen_x" ] }, "pen_y": { "dtype": "float32", "shape": [ 1 ], "names": [ "pen_y" ] }, "pen_yaw": { "dtype": "float32", "shape": [ 1 ], "names": [ "pen_yaw" ] }, "action.cartesian_velocity": { "dtype": "float32", "shape": [ 6 ], "names": [ "x", "y", "z", "roll", "pitch", "yaw" ] }, "action.cartesian_position": { "dtype": "float32", "shape": [ 6 ], "names": [ "x", "y", "z", "roll", "pitch", "yaw" ] }, "action.joint_velocity": { "dtype": "float32", "shape": [ 7 ], "names": [ "joint_0", "joint_1", "joint_2", "joint_3", "joint_4", "joint_5", "joint_6" ] }, "action.joint_position": { "dtype": "float32", "shape": [ 7 ], "names": [ "joint_0", "joint_1", "joint_2", "joint_3", "joint_4", "joint_5", "joint_6" ] }, "action.gripper_position": { "dtype": "float32", "shape": [ 1 ], "names": [ "gripper" ] }, "action.gripper_velocity": { "dtype": "float32", "shape": [ 1 ], "names": [ "gripper" ] }, "observation.state.cartesian_position": { "dtype": "float32", "shape": [ 6 ], "names": [ "x", "y", "z", "roll", "pitch", "yaw" ] }, "observation.state.joint_position": { "dtype": "float32", "shape": [ 7 ], "names": [ "joint_0", "joint_1", "joint_2", "joint_3", "joint_4", "joint_5", "joint_6" ] }, "observation.state.joint_velocity": { "dtype": "float32", "shape": [ 7 ], "names": [ "joint_0", "joint_1", "joint_2", "joint_3", "joint_4", "joint_5", "joint_6" ] }, "observation.state.cartesian_velocity": { "dtype": "float32", "shape": [ 6 ], "names": [ "x", "y", "z", "roll", "pitch", "yaw" ] }, "observation.state.gripper_position": { "dtype": "float32", "shape": [ 1 ], "names": [ "gripper" ] }, "observation.images.18650758_left": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "h264", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 15, "video.channels": 3, "has_audio": false } }, "observation.images.25916956_left": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "h264", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 15, "video.channels": 3, "has_audio": false } }, "timestamp": { "dtype": "float32", "shape": [ 1 ], "names": null }, "frame_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "episode_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "task_index": { "dtype": "int64", "shape": [ 1 ], "names": null } } } ``` ## Citation **BibTeX:** ```bibtex [More Information Needed] ```
This dataset is a robotics control dataset created using LeRobot, collected with a Franka robot. It contains 50 training episodes, totaling 13,824 frames at 15fps. Features include robot state observations (e.g., Cartesian position, joint position, velocity), actions (e.g., Cartesian velocity, joint velocity), intervention flags, success flags, rewards, and video observations from two cameras (resolution 480x640). The dataset is designed for robot learning tasks, supporting reinforcement learning or imitation learning research.