HyeonseokE/SO101-DistributeChoco_Ours_80epi
收藏资源简介:
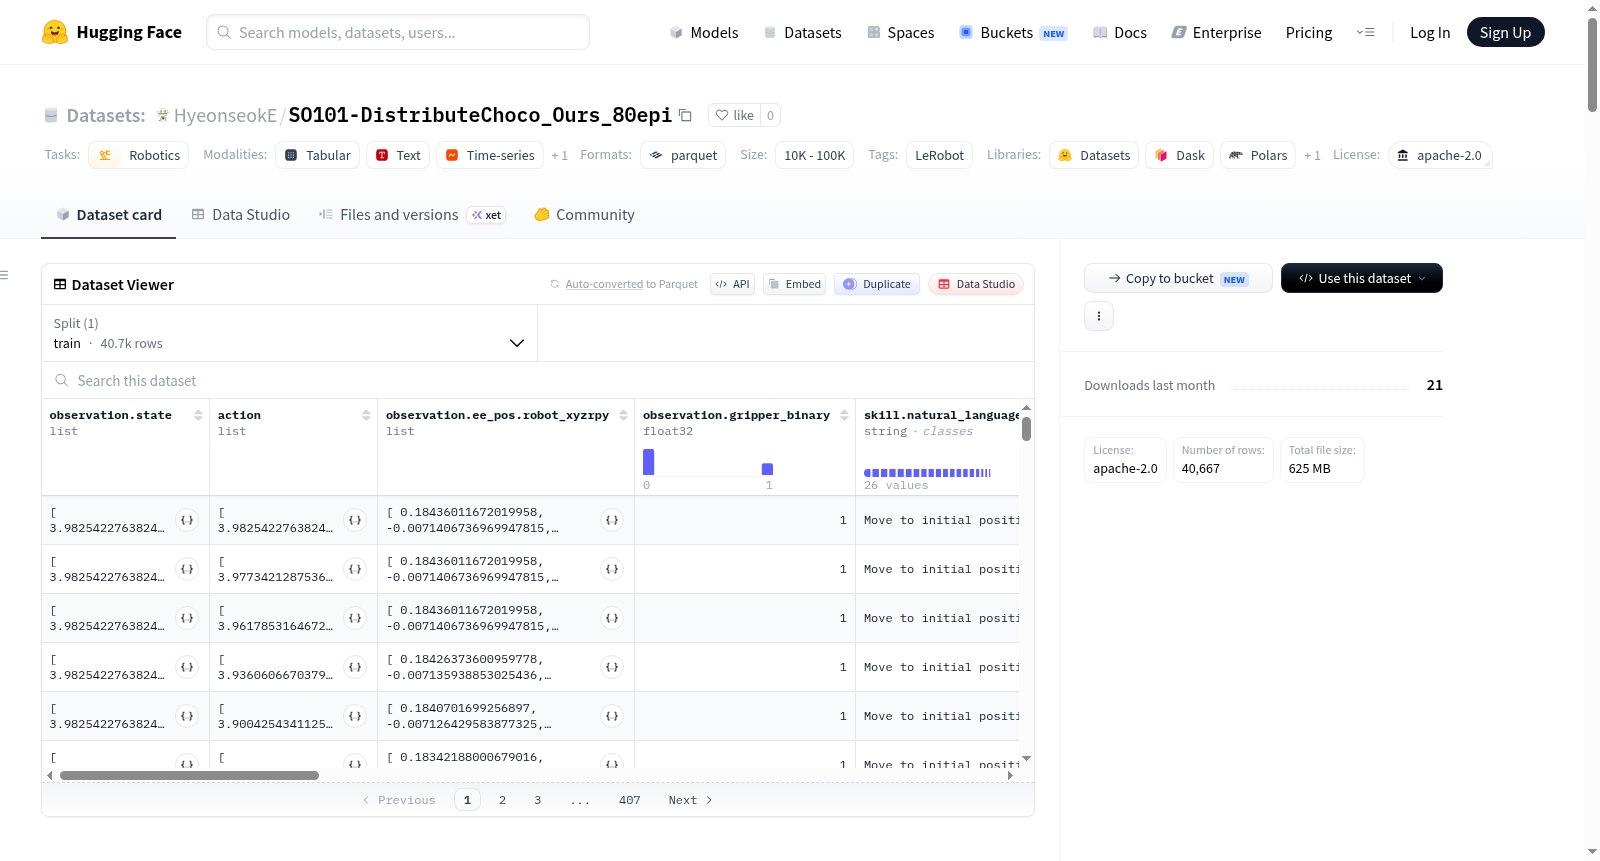
该数据集使用LeRobot框架创建,专注于机器人操作任务。数据集包含80个训练片段,总计40667帧数据,帧率为10fps。机器人类型为so101_follower,数据以parquet格式存储,并附带MP4格式的视频文件。数据集特征包括:机器人关节状态观测(6维位置)、对应的动作控制(6维关节位置)、来自顶部和左腕摄像头的图像观测(分辨率480x640,RGB三通道)、末端执行器的位置和姿态(XYZRPY)、二进制夹爪状态、技能和子任务的自然语言描述、技能类型和进度、目标关节位置和末端位姿、子任务对象名称和目标位置,以及时间戳、帧索引、片段索引等元数据。该数据集适用于机器人模仿学习、强化学习及多模态任务研究。
This dataset was created using the LeRobot framework and focuses on robotic manipulation tasks. It consists of 80 training episodes with a total of 40,667 frames at 10 fps. The robot type is so101_follower, and data is stored in parquet format along with MP4 video files. Dataset features include: robot joint state observations (6-dimensional positions), corresponding action controls (6-dimensional joint positions), image observations from top and left-wrist cameras (resolution 480x640, RGB three channels), end-effector position and orientation (XYZRPY), binary gripper state, natural language descriptions for skills and subtasks, skill type and progress, target joint positions and end-effector poses, subtask object names and target positions, as well as metadata such as timestamps, frame indices, and episode indices. This dataset is suitable for research in robot imitation learning, reinforcement learning, and multimodal tasks.