ankile/square-01a-ours-mining-shape-beta05-r3-diagnostic-rollouts
收藏资源简介:
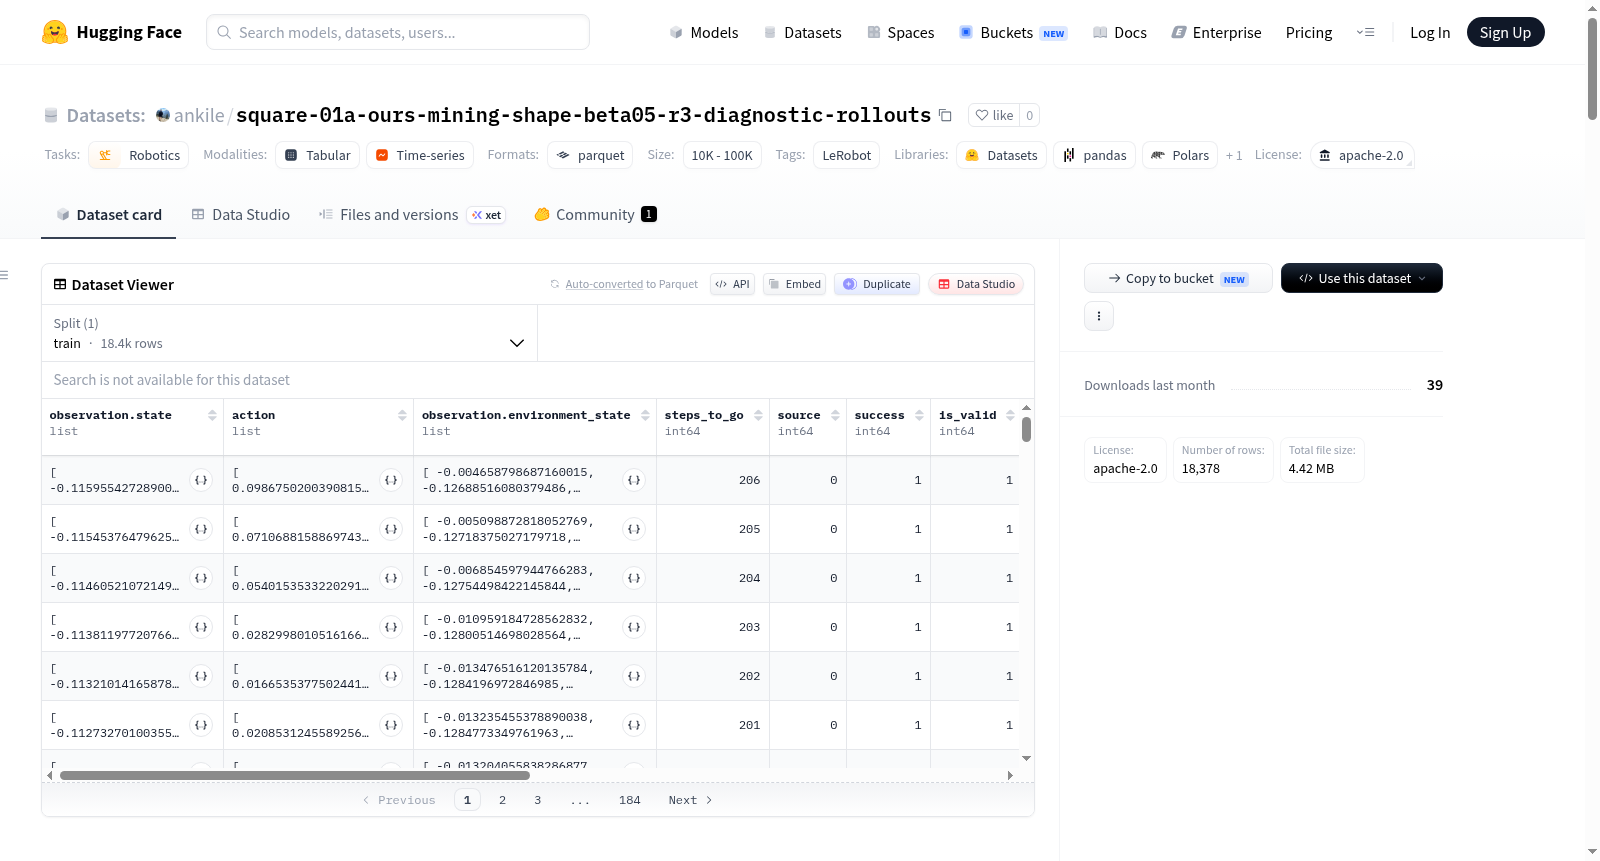
该数据集使用LeRobot创建,专注于机器人任务,具体涉及Panda机器人。数据集包含100个episodes,总计18378帧,数据以parquet格式存储,视频以mp4格式存储,帧率为20fps。特征包括观察状态(如末端执行器位置和姿态、夹爪位置)、动作(如末端执行器位置和旋转变化、夹爪动作)、环境状态(如螺母相对于末端执行器的位置和姿态)、步骤剩余、来源标识、成功标志、有效性标志、奖励、完成标志、初始模拟位置和速度、时间戳、帧索引、episode索引、索引和任务索引。这些数据适用于机器人学习和控制研究。
This dataset was created using LeRobot and focuses on robotics tasks, specifically involving the Panda robot. It contains 100 episodes with a total of 18378 frames, stored in parquet format for data and mp4 format for videos, with a frame rate of 20fps. Features include observation state (e.g., end-effector position and orientation, gripper positions), action (e.g., changes in end-effector position and rotation, gripper action), environment state (e.g., nut position and orientation relative to the end-effector), steps to go, source identifier, success flag, validity flag, reward, done flag, initial simulation positions and velocities, timestamp, frame index, episode index, index, and task index. This data is suitable for robotics learning and control research.