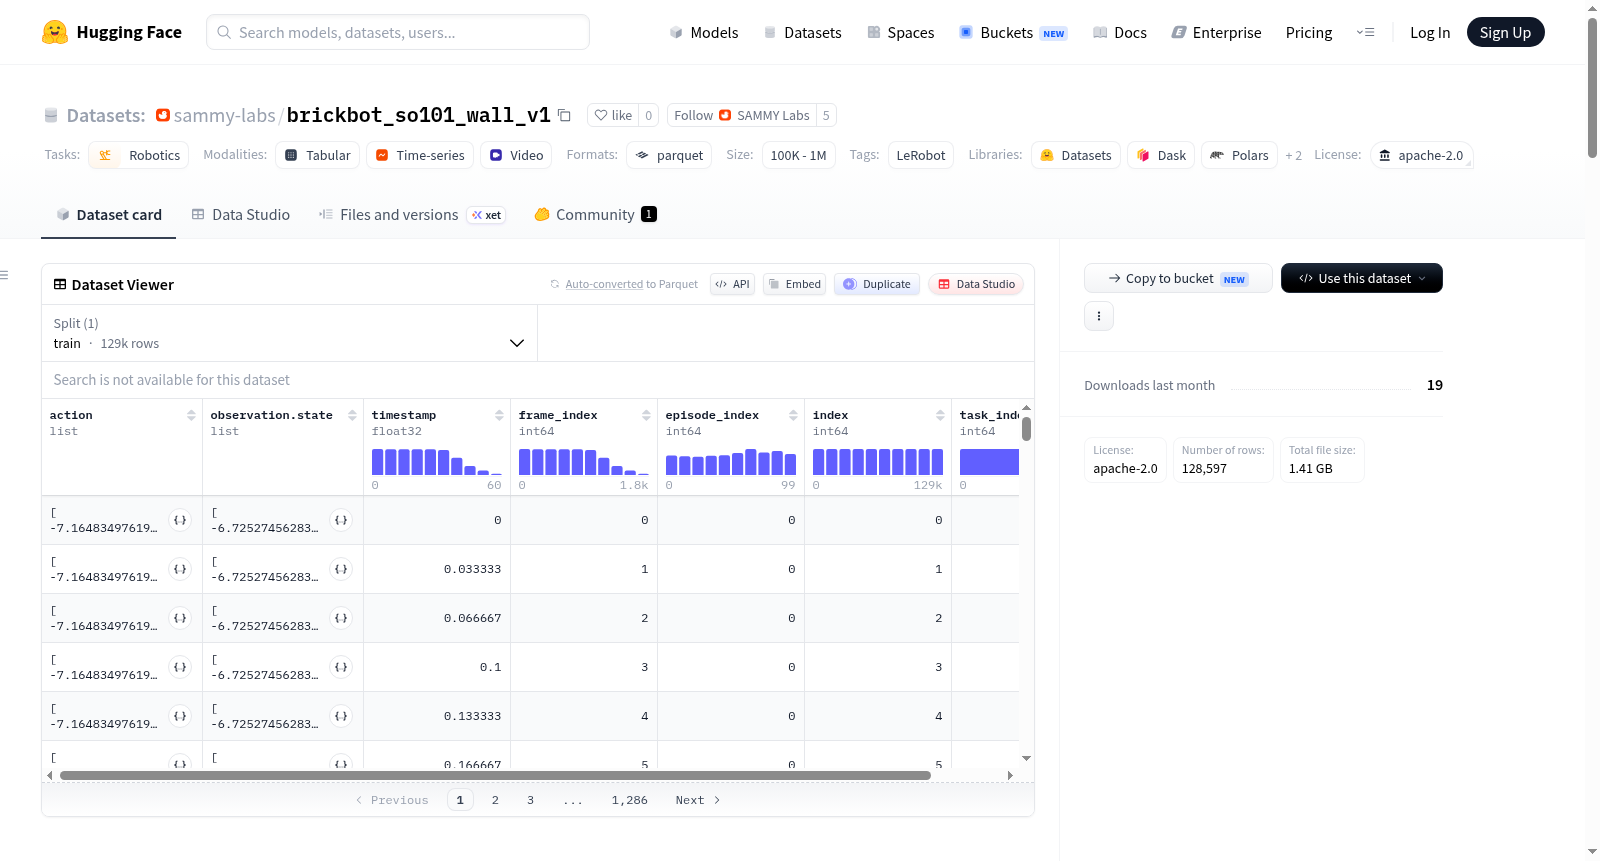
brickbot_so101_wall_v1
收藏资源简介:
该数据集是使用LeRobot框架创建的机器人操作数据集,主要用于机器人模仿学习或强化学习任务。数据集中包含100个episodes,共128,597帧,所有帧属于同一个任务(task_index均为0)。机器人类型为so_follower,动作和状态都包含6维关节位置(shoulder_pan, shoulder_lift, elbow_flex, wrist_flex, wrist_roll, gripper)。观测包括两个摄像头图像:正面摄像头(front)和腕部摄像头(wrist),分辨率均为480x640,帧率为30fps,视频编码为AV1,格式为mp4。数据以parquet文件存储,视频以mp4文件存储,分别位于data/和videos/目录下,并按chunk和file组织。数据集仅包含一个训练集(split为train),覆盖所有episodes。许可证为Apache-2.0。
This dataset is a robot manipulation dataset created using the LeRobot framework, primarily used for robot imitation learning or reinforcement learning tasks. It contains 100 episodes with a total of 128,597 frames, all belonging to the same task (task_index is 0). The robot type is so_follower, and both actions and states include 6-dimensional joint positions (shoulder_pan, shoulder_lift, elbow_flex, wrist_flex, wrist_roll, gripper). Observations include two camera images: front camera and wrist camera, both with resolution 480x640, frame rate 30fps, video codec AV1, and format mp4. Data is stored as parquet files, and videos as mp4 files, located in data/ and videos/ directories respectively, organized by chunk and file. The dataset contains only one training split (train), covering all episodes. The license is Apache-2.0.
数据集详情:brickbot_so101_wall_v1
基本信息
- 任务类型:机器人技术(robotics)
- 许可证:Apache-2.0
- 数据集创建工具:LeRobot(由Hugging Face开发)
- 主页:尚未提供
- 论文:尚未提供
数据集规模
- 总片段数(Episodes):100
- 总帧数(Frames):128,597
- 总任务数:1
- 机器人类型:so_follower
- 采样频率:30 FPS
- 数据划分:训练集包含全部100个片段(索引0至99)
数据特征
数据集包含以下特征字段:
| 特征名称 | 数据类型 | 形状 | 说明 |
|---|---|---|---|
| action | float32 | [6] | 6维动作向量,对应机械臂关节位置 |
| observation.state | float32 | [6] | 6维观测状态,对应机械臂关节位置 |
| observation.images.front | 视频 | 480×640×3 | 前方摄像头RGB视频流 |
| observation.images.wrist | 视频 | 480×640×3 | 手腕摄像头RGB视频流 |
| timestamp | float32 | [1] | 时间戳 |
| frame_index | int64 | [1] | 帧索引 |
| episode_index | int64 | [1] | 片段索引 |
| index | int64 | [1] | 全局索引 |
| task_index | int64 | [1] | 任务索引 |
动作/状态空间
动作和状态均包含6个维度,对应以下机械臂关节:
- shoulder_pan.pos(肩部旋转)
- shoulder_lift.pos(肩部抬升)
- elbow_flex.pos(肘部弯曲)
- wrist_flex.pos(腕部弯曲)
- wrist_roll.pos(腕部旋转)
- gripper.pos(夹爪位置)
视觉数据规格
- 分辨率:480×640像素
- 通道数:3(RGB)
- 视频编码:AV1
- 像素格式:yuv420p
- 帧率:30 FPS
- 视频后端:pyav
数据文件
- 数据格式:Parquet文件
- 数据存储路径:
data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet - 视频存储路径:
videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4 - 分块大小:1000帧
- 数据文件大小:约100 MB
- 视频文件大小:约200 MB
可视化
可通过LeRobot的可视化工具预览此数据集,访问地址为:https://huggingface.co/spaces/lerobot/visualize_dataset?path=sammy-labs/brickbot_so101_wall_v1
引用信息
暂无BibTeX引用信息。