FR5_task2_transfer_the_gray_tablets_from_the_brown_bottle_into_another_brown_bottle
收藏资源简介:
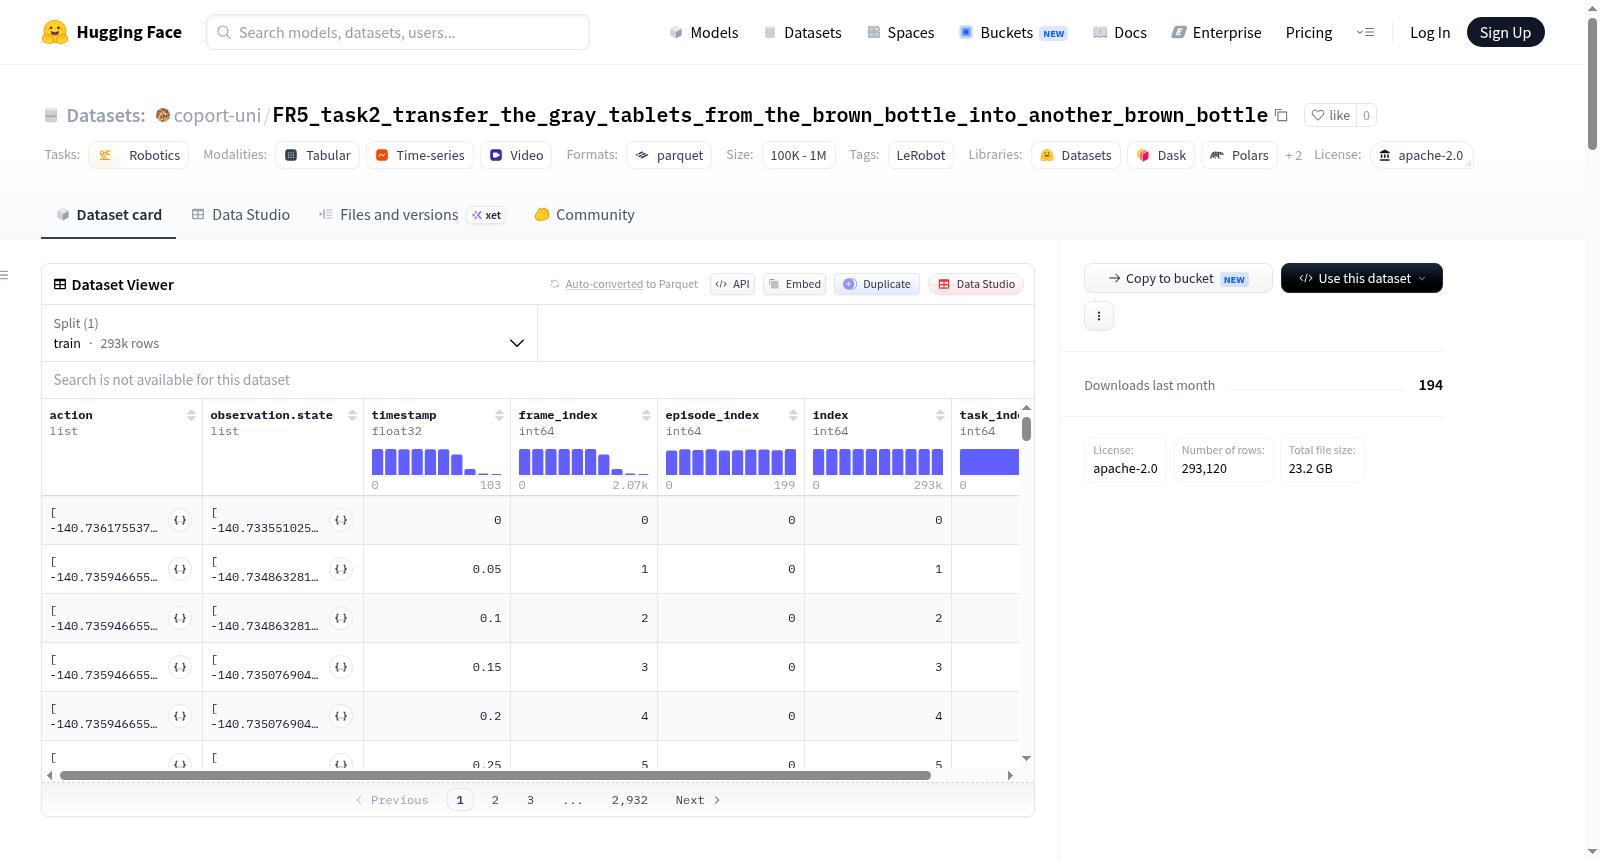
该数据集是使用LeRobot框架创建的机器人操作数据集,专门用于机器人技术领域的研究与应用。数据集包含一个单一任务:将灰色药片从棕色瓶子转移到另一个棕色瓶子。数据规模为200个完整的操作序列(episodes),总计293,120帧数据,数据文件大小为100MB,视频文件大小为200MB,采集帧率为20fps。数据以Parquet文件格式存储,并全部划分为训练集。数据集提供了丰富的多模态信息,包括:1. 机器人动作:7维浮点数组,表示6个关节和夹爪的位置指令。2. 机器人状态观测:7维浮点数组,表示6个关节和夹爪的实际位置。3. 多视角视觉观测:包含三个同步的RGB视频流,分辨率均为480x640,分别来自左上角摄像头、右上角摄像头和手部摄像头,用于提供环境与操作的多角度视觉信息。4. 元数据:包括时间戳、帧索引、episode索引和任务索引,用于数据的时间对齐和序列组织。该数据集适用于机器人模仿学习、强化学习、视觉运动策略学习等任务,为研究多模态感知与机器人操作控制提供了结构化的真实数据。
This dataset is a robot manipulation dataset created using the LeRobot framework, specifically designed for research and applications in robotics. It contains a single task: transferring a gray pill from one brown bottle to another brown bottle. The dataset comprises 200 complete operation sequences (episodes), totaling 293,120 frames, with a data file size of 100MB and a video file size of 200MB, captured at a frame rate of 20fps. The data is stored in Parquet format and is entirely allocated to the training set. It provides rich multimodal information, including: 1. Robot actions: 7-dimensional floating-point arrays representing position commands for 6 joints and the gripper. 2. Robot state observations: 7-dimensional floating-point arrays representing the actual positions of 6 joints and the gripper. 3. Multi-view visual observations: three synchronized RGB video streams, each with a resolution of 480x640, from the top-left camera, top-right camera, and hand camera, offering multi-angle visual information of the environment and operations. 4. Metadata: including timestamps, frame indices, episode indices, and task indices, used for temporal alignment and sequence organization. This dataset is suitable for tasks such as robot imitation learning, reinforcement learning, and visual-motor policy learning, providing structured real-world data for research on multimodal perception and robot manipulation control.
数据集概述
- 数据集名称:FR5_task2_transfer_the_gray_tablets_from_the_brown_bottle_into_another_brown_bottle
- 许可证:Apache-2.0
- 任务类别:机器人学(Robotics)
- 标签:LeRobot
- 创建工具:LeRobot (https://github.com/huggingface/lerobot)
数据集规模
| 指标 | 数值 |
|---|---|
| 总轮次(Episodes) | 200 |
| 总帧数(Frames) | 293,120 |
| 总任务数 | 1 |
| 数据文件大小 | 100 MB |
| 视频文件大小 | 200 MB |
| 帧率(FPS) | 20 |
| 数据分块大小 | 1,000 帧/块 |
| 机器人类型 | fairino_follower |
数据集分割
- 训练集:索引 0 至 199(共 200 个轮次)
数据特征
| 特征名称 | 数据类型 | 形状 | 说明 |
|---|---|---|---|
| action | float32 | (7,) | 7 维关节位置与夹爪位置动作 |
| observation.state | float32 | (7,) | 7 维关节与夹爪状态观测 |
| observation.images.top_left | video (AV1) | (480, 640, 3) | 左上角摄像头视频,20 FPS |
| observation.images.top_right | video (AV1) | (480, 640, 3) | 右上角摄像头视频,20 FPS |
| observation.images.hand | video (AV1) | (480, 640, 3) | 手部摄像头视频,20 FPS |
| timestamp | float32 | (1,) | 时间戳 |
| frame_index | int64 | (1,) | 帧索引 |
| episode_index | int64 | (1,) | 轮次索引 |
| index | int64 | (1,) | 全局索引 |
| task_index | int64 | (1,) | 任务索引(固定为 0) |
数据存储路径
- 数据文件:
data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet - 视频文件:
videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4
引用信息
- 暂无提供 BibTeX 引用格式。