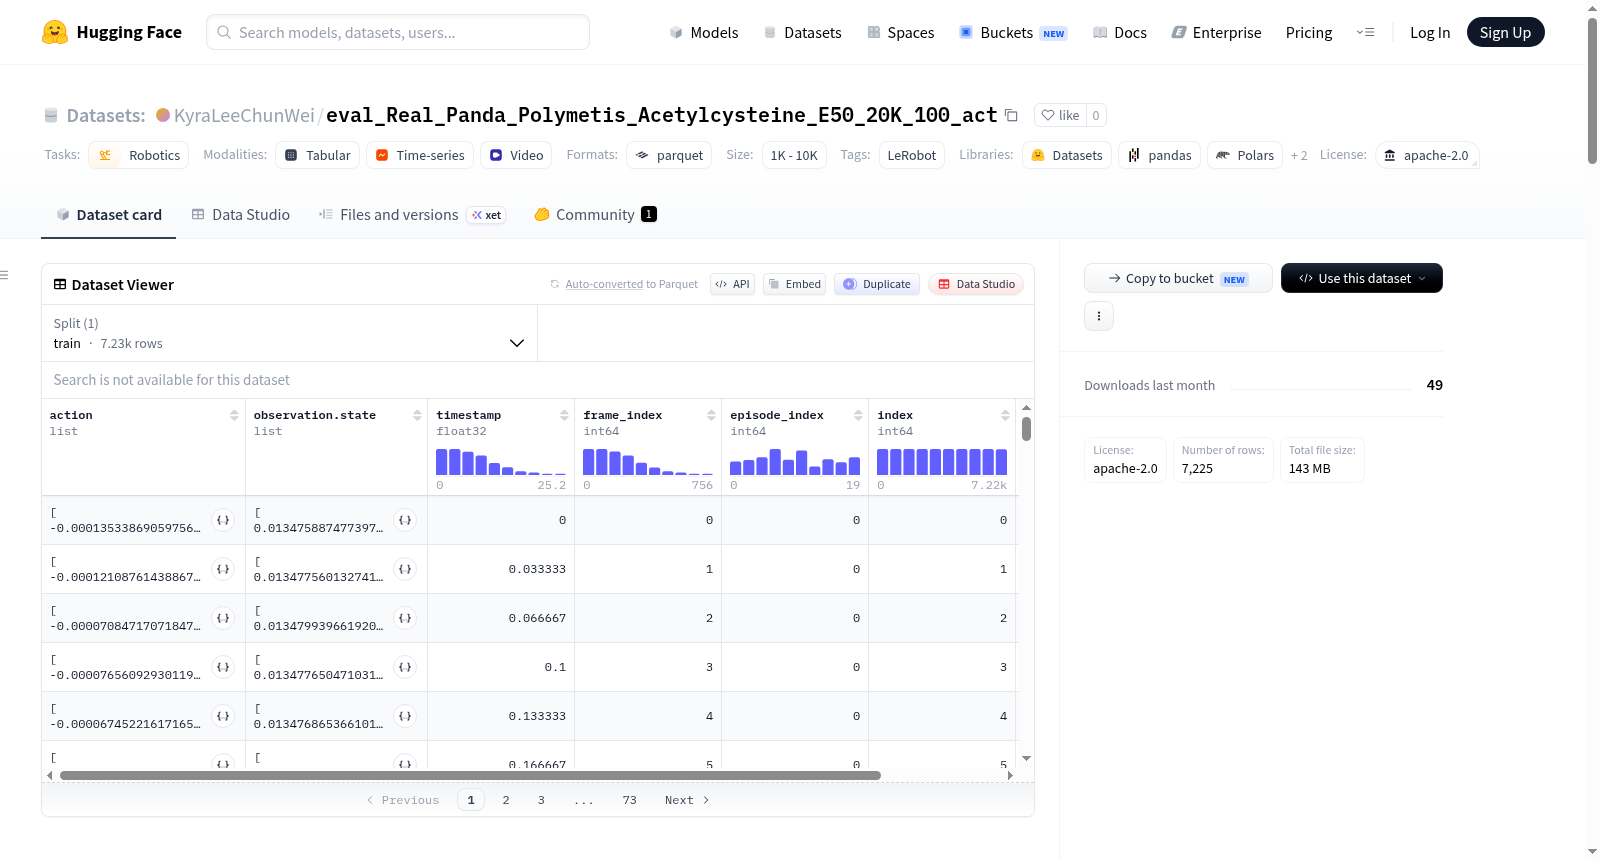
eval_Real_Panda_Polymetis_Acetylcysteine_E50_20K_100_act
收藏资源简介:
该数据集是使用LeRobot框架创建的机器人操作数据集,采用Franka机器人平台。数据集包含20个完整episode,共计7225帧,覆盖单一任务。数据以30fps的帧率采集,总大小约300MB(数据文件100MB,视频文件200MB)。每个样本包含7维动作指令(末端执行器位姿增量及夹爪指令)、15维机器人状态观测(关节位置、夹爪状态、末端执行器位姿)、两个视角的RGB视频(分辨率480x640,AV1编码,30fps)、时间戳、帧索引、episode索引等字段。数据以parquet格式存储,视频以mp4格式存储。该数据集可用于机器人模仿学习、行为克隆、强化学习中的策略学习等任务,训练数据已按单个episode划分,无需额外分割。
This dataset is a robot manipulation dataset created using the LeRobot framework on a Franka robot platform. It contains 20 complete episodes with a total of 7225 frames covering a single task. Data is collected at 30fps with a total size of approximately 300MB (100MB for data files, 200MB for video files). Each sample includes 7-dimensional action commands (end-effector pose increments and gripper commands), 15-dimensional robot state observations (joint positions, gripper state, end-effector pose), RGB videos from two viewpoints (resolution 480x640, AV1 codec, 30fps), timestamps, frame indices, episode indices, and other fields. Data is stored in parquet format, and videos are stored in mp4 format. This dataset can be used for robot imitation learning, behavior cloning, and policy learning in reinforcement learning. The training data is already divided into individual episodes and does not require additional splitting.
数据集概述
该数据集由 LeRobot 创建,用于机器人学习领域,基于 Franka 机器人平台采集。
基本信息
- 许可证: Apache-2.0
- 任务类别: 机器人技术
- 数据集版本: LeRobot v3.0
- 机器人类型: Franka
数据规模
- 总片段数: 20 个片段
- 总帧数: 7,225 帧
- 任务数: 1 个任务
- 数据分割: 全部 20 个片段用于训练集
- 帧率: 30 fps
数据文件
- 数据格式: Parquet 文件 (data//.parquet)
- 视频文件: MP4 格式 (videos/.../*.mp4)
- 数据文件大小: 约 100 MB
- 视频文件大小: 约 200 MB
- 块大小: 1000 帧/块
数据特征
动作数据
- 包含7维动作向量,具体为:
- 末端执行器位置增量 (Δx, Δy, Δz)
- 末端执行器姿态增量 (Δrx, Δry, Δrz)
- 夹爪指令 (二进制值)
观测状态数据
- 包含15维状态向量,具体为:
- 7个关节位置
- 夹爪归一化状态
- 夹爪指令 (二进制值)
- 末端执行器位置 (x, y, z)
- 末端执行器姿态 (rx, ry, rz)
视觉观测
- 两个摄像头:
camera_1和camera_2 - 图像分辨率: 480×640 像素,3 通道 RGB
- 视频编码: AV1 编码,yuv420p 像素格式,30 fps,无音频
其他字段
- 时间戳: float32,1维
- 帧索引: int64,1维
- 片段索引: int64,1维
- 索引: int64,1维
- 任务索引: int64,1维