maximellerbach/omx_screwing_test_20260527_153336
收藏资源简介:
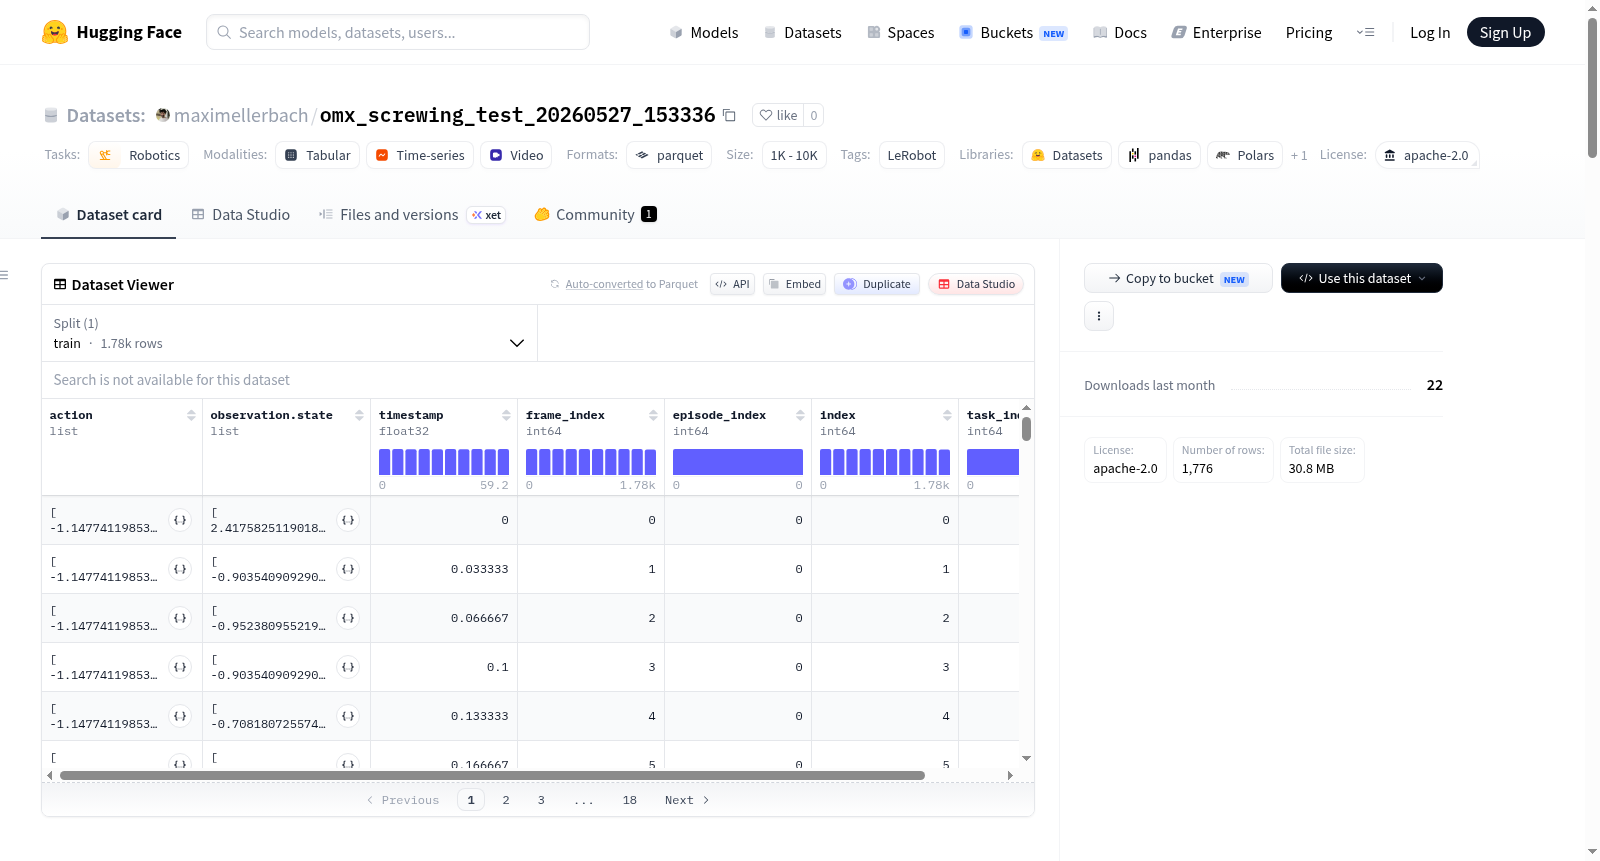
该数据集是一个机器人操作数据集,由LeRobot创建。它包含一个完整的机器人操作片段(总片段数为1),总帧数为1776帧,帧率为30fps。数据集记录了omx_follower机器人在执行任务过程中的动作和观察数据。具体特征包括:6维浮点动作向量(控制肩部平移、肩部提升、肘部弯曲、腕部弯曲、腕部旋转和夹爪位置)、6维浮点观察状态向量(与动作向量相同)、来自腕部和顶部摄像头的视频观察(分辨率480x640,RGB三通道,编码为av1格式)、时间戳、帧索引、片段索引、任务索引等。数据以parquet格式存储,视频数据单独存储为mp4文件。数据集主要用于机器人学习和控制任务研究。
This dataset is a robotic manipulation dataset created using LeRobot. It contains one complete robotic episode (total episodes: 1) with 1776 total frames at 30fps. The dataset records actions and observations from an omx_follower robot during task execution. Key features include: 6-dimensional float32 action vectors (controlling shoulder pan, shoulder lift, elbow flex, wrist flex, wrist roll, and gripper positions), 6-dimensional float32 observation state vectors (same as action vectors), video observations from wrist and top cameras (resolution 480x640, RGB three channels, encoded in av1 format), timestamps, frame indices, episode indices, and task indices. Data is stored in parquet format with video data stored separately as mp4 files. The dataset is primarily intended for robotic learning and control task research.