base4-plate-croissant-01-BC-FV-v3
收藏资源简介:
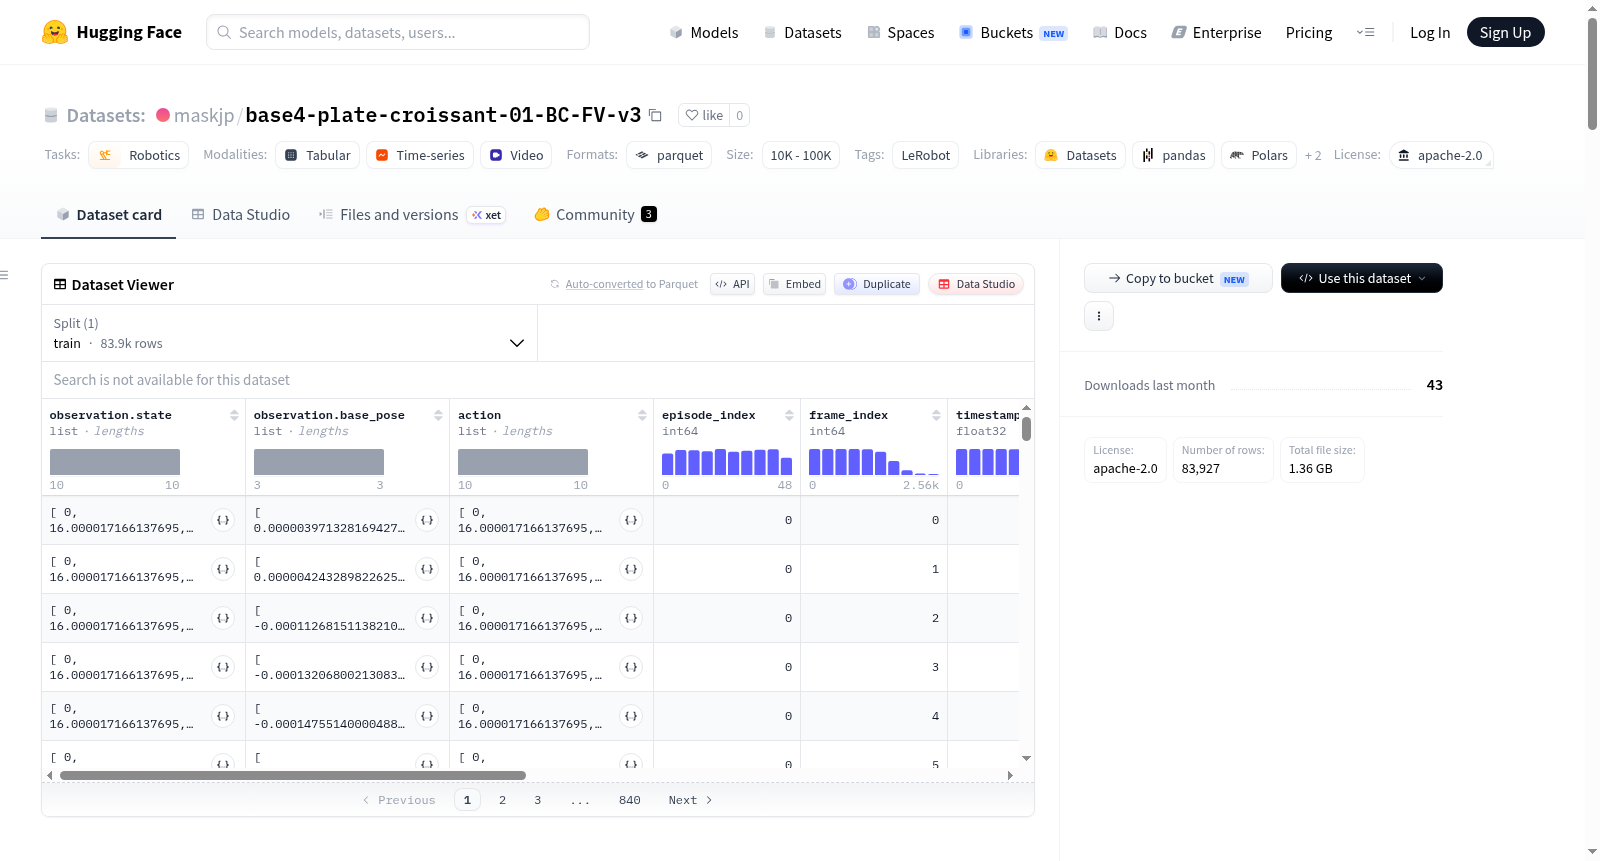
该数据集基于LeRobot框架构建,用于机器人操作任务。数据集包含由u850型机器人执行单一任务(如放置牛角包)的示教数据。数据共包含49个完整episode,总计83927帧,以50fps频率采集。每个episode包含多模态观测:10维关节状态(包括6个关节、夹爪和基座x、y、偏航角)、3个视角的RGB图像(左、右、腕部,分辨率480×640,H.264编码视频)、基座位姿(3维),以及对应的10维动作指令。此外还记录了episode索引、帧索引、时间戳、任务索引等辅助信息。数据集分为训练集(0-48episode)和测试集(未指定),总数据量约100MB,视频文件约200MB。该数据集适用于机器人模仿学习、离线强化学习等任务。
This dataset is built on the LeRobot framework for robot manipulation tasks. It contains demonstration data of a single task (e.g., placing a croissant) performed by a u850 robot. The dataset includes 49 complete episodes with a total of 83,927 frames collected at 50fps. Each episode consists of multimodal observations: 10-dimensional joint states (including 6 joints, gripper, and base x, y, yaw), RGB images from three viewpoints (left, right, wrist, resolution 480×640, H.264 encoded video), base pose (3-dimensional), and corresponding 10-dimensional action commands. Auxiliary information such as episode index, frame index, timestamp, and task index is also recorded. The dataset is split into training set (episodes 0-48) and test set (unspecified), with a total data size of approximately 100MB and video files of about 200MB. It is suitable for robot imitation learning, offline reinforcement learning, and other tasks.
数据集概述
- 数据集名称: base4-plate-croissant-01-BC-FV-v3
- 许可证: Apache-2.0
- 任务类型: 机器人技术 (Robotics)
- 标签: LeRobot
- 创建工具: 该数据集使用 LeRobot 创建
数据集规模
- 总片段数: 49
- 总帧数: 83,927
- 总任务数: 1
- 数据划分: 训练集 (train): 0-49
- 数据文件大小: 100 MB
- 视频文件大小: 200 MB
数据详情
- 机器人类型: u850
- 录制帧率 (fps): 50
- 块大小 (chunks_size): 1000
- 代码库版本: v3.0
数据特征
观测状态 (observation.state)
- 数据类型: float32
- 形状: [10](对应10个电机:joint1至joint6、gripper、base_x、base_y、base_yaw)
- 帧率: 50 fps
图像观测
共有三个摄像头视图,均为视频格式,分辨率480x640x3,H264编码,无音频,帧率50 fps:
- observation.images.left: 左侧摄像头
- observation.images.right: 右侧摄像头
- observation.images.wrist: 腕部摄像头
基础位姿 (observation.base_pose)
- 数据类型: float32
- 形状: [3](base_x、base_y、base_yaw)
- 帧率: 50 fps
动作 (action)
- 数据类型: float32
- 形状: [10](对应10个电机:joint1至joint6、gripper、base_x、base_y、base_yaw)
- 帧率: 50 fps
其他特征
- episode_index: int64 类型,帧率 50
- frame_index: int64 类型,帧率 50
- timestamp: float32 类型,帧率 50
- next.done: bool 类型,帧率 50
- correction: bool 类型,帧率 50
- index: int64 类型,帧率 50
- task_index: int64 类型,帧率 50
数据集可视化
可通过 可视化页面 查看数据集内容。
引用信息
该数据集的引用信息暂未提供(BibTeX 待补充)。