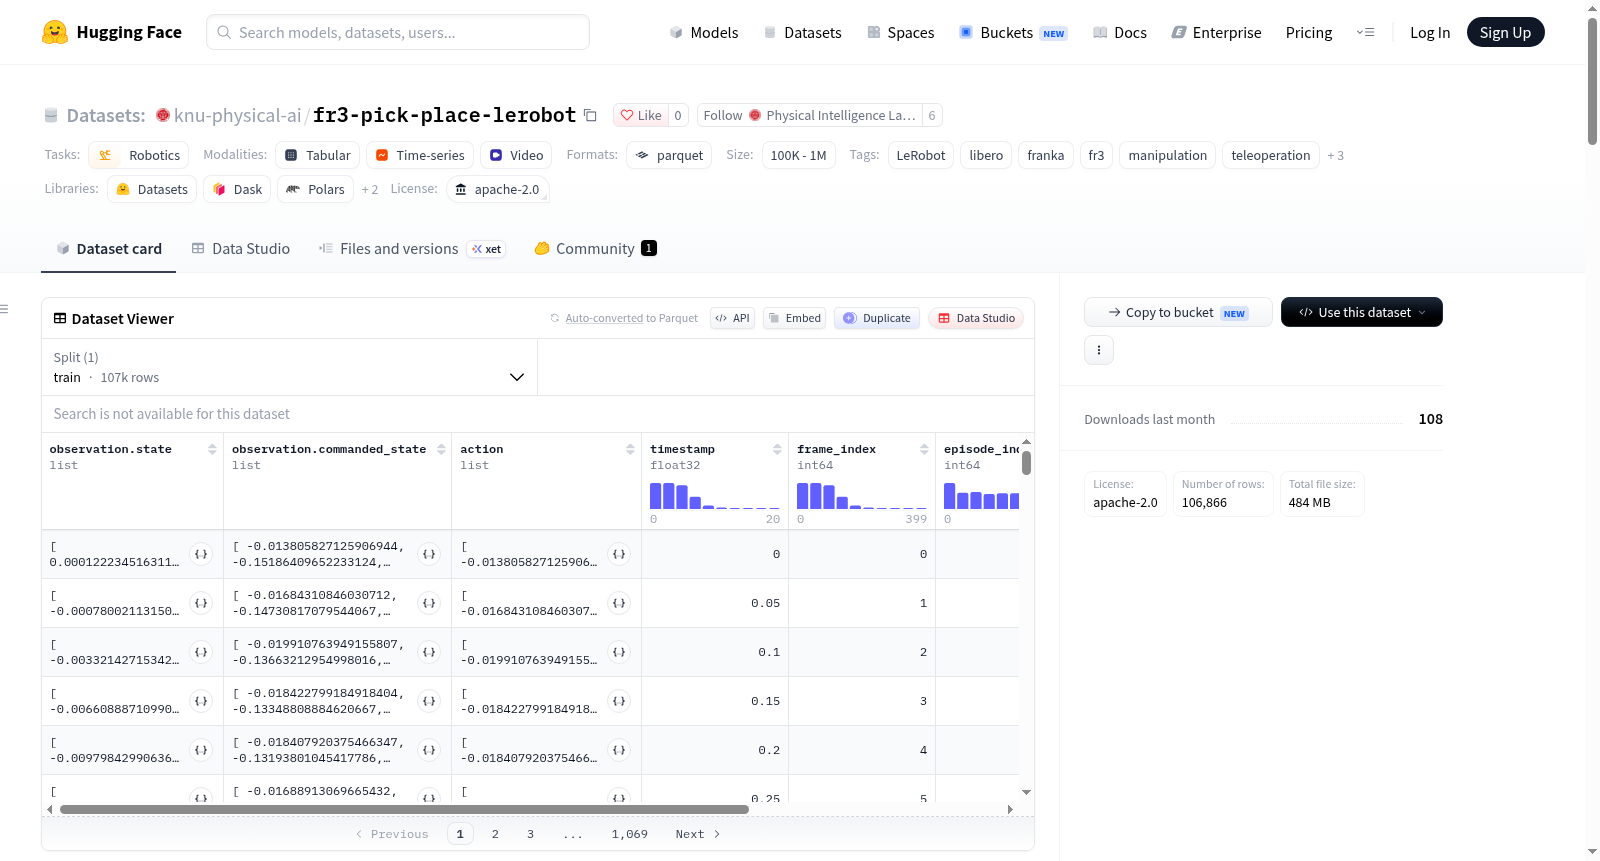
fr3-pick-place-lerobot
收藏资源简介:
该数据集基于LeRobot框架创建,旨在为机器人操控任务(特别是拾取和放置任务)提供训练数据。数据集包含121个演示片段,共计17626帧视频和传感器数据,涵盖4个不同任务。数据使用Franka Research 3(FR3)机器人搭配Gello遥操作设备在真实环境中采集,以20 FPS的帧率录制。数据特征包括:8维机器人关节状态(7个关节位置+夹爪位置)、来自两个摄像头(agent视角和wrist视角)的256x256 RGB视频、命令状态(commanded state)以及8维动作指令。所有数据以Parquet和MP4视频文件格式存储,并按照LeRobot标准组织。该数据集适用于模仿学习、行为克隆、机器人操控策略训练等任务,并可用于多任务学习场景。
This dataset is created based on the LeRobot framework, aiming to provide training data for robot manipulation tasks, especially pick-and-place tasks. It contains 121 demonstration episodes, totaling 17,626 frames of video and sensor data, covering 4 different tasks. Data was collected in a real environment using a Franka Research 3 (FR3) robot with a Gello teleoperation device, recorded at 20 FPS. Data features include: 8-dimensional robot joint states (7 joint positions + gripper position), 256x256 RGB videos from two cameras (agent view and wrist view), commanded states, and 8-dimensional action commands. All data is stored in Parquet and MP4 video file formats, organized according to LeRobot standards. This dataset is suitable for imitation learning, behavior cloning, robot manipulation policy training, and can be used for multi-task learning scenarios.
数据集概述
该数据集名为 fr3-pick-place-lerobot,由 knu-physical-ai 发布,是一个面向机器人操作任务的真实机器人数据集,基于 LeRobot 框架创建。
基本信息
- 许可证: Apache-2.0
- 任务类别: 机器人技术(robotics)
- 标签: LeRobot
- 机器人类型: fr3_gello_real(Franka FR3 机械臂搭配 Gello 遥操作设备)
- 采样频率: 20 fps
- 数据格式: Parquet 文件(数据)+ MP4 视频文件(图像)
- 数据文件大小: 约 100 MB(数据文件)+ 约 200 MB(视频文件)
数据规模
- 总回合数(episodes): 121
- 总帧数(frames): 17,626
- 总任务数(tasks): 4
- 数据划分: 仅包含训练集(train),共 121 个回合
数据特征
每个样本包含以下特征字段:
| 特征名 | 数据类型 | 形状 | 说明 |
|---|---|---|---|
observation.state |
float32 | [8] | 机器人观测状态(7 个关节位置 + 1 个夹爪位置) |
observation.images.agent |
video | [256, 256, 3] | 第三人称视角摄像头图像(AV1 编码) |
observation.images.wrist |
video | [256, 256, 3] | 腕部摄像头图像(AV1 编码) |
observation.commanded_state |
float32 | [8] | 指令状态(7 个关节位置 + 1 个夹爪位置) |
action |
float32 | [8] | 动作指令(7 个关节位置 + 1 个夹爪位置) |
timestamp |
float32 | [1] | 时间戳 |
frame_index |
int64 | [1] | 帧索引 |
episode_index |
int64 | [1] | 回合索引 |
index |
int64 | [1] | 样本索引 |
task_index |
int64 | [1] | 任务索引 |
图像规格
- 分辨率: 256 × 256 像素,3 通道(RGB)
- 视频编码: AV1(codec: av1),像素格式 yuv420p
- 视频帧率: 20 fps
- 无音频
使用
- 可通过 LeRobot 框架进行数据集的可视化和训练:
- 可视化工具:https://huggingface.co/spaces/lerobot/visualize_dataset?path=knu-physical-ai/fr3-pick-place-lerobot
- 数据路径:
data/*/*.parquet,视频路径:videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4