cube_to_plate
收藏资源简介:
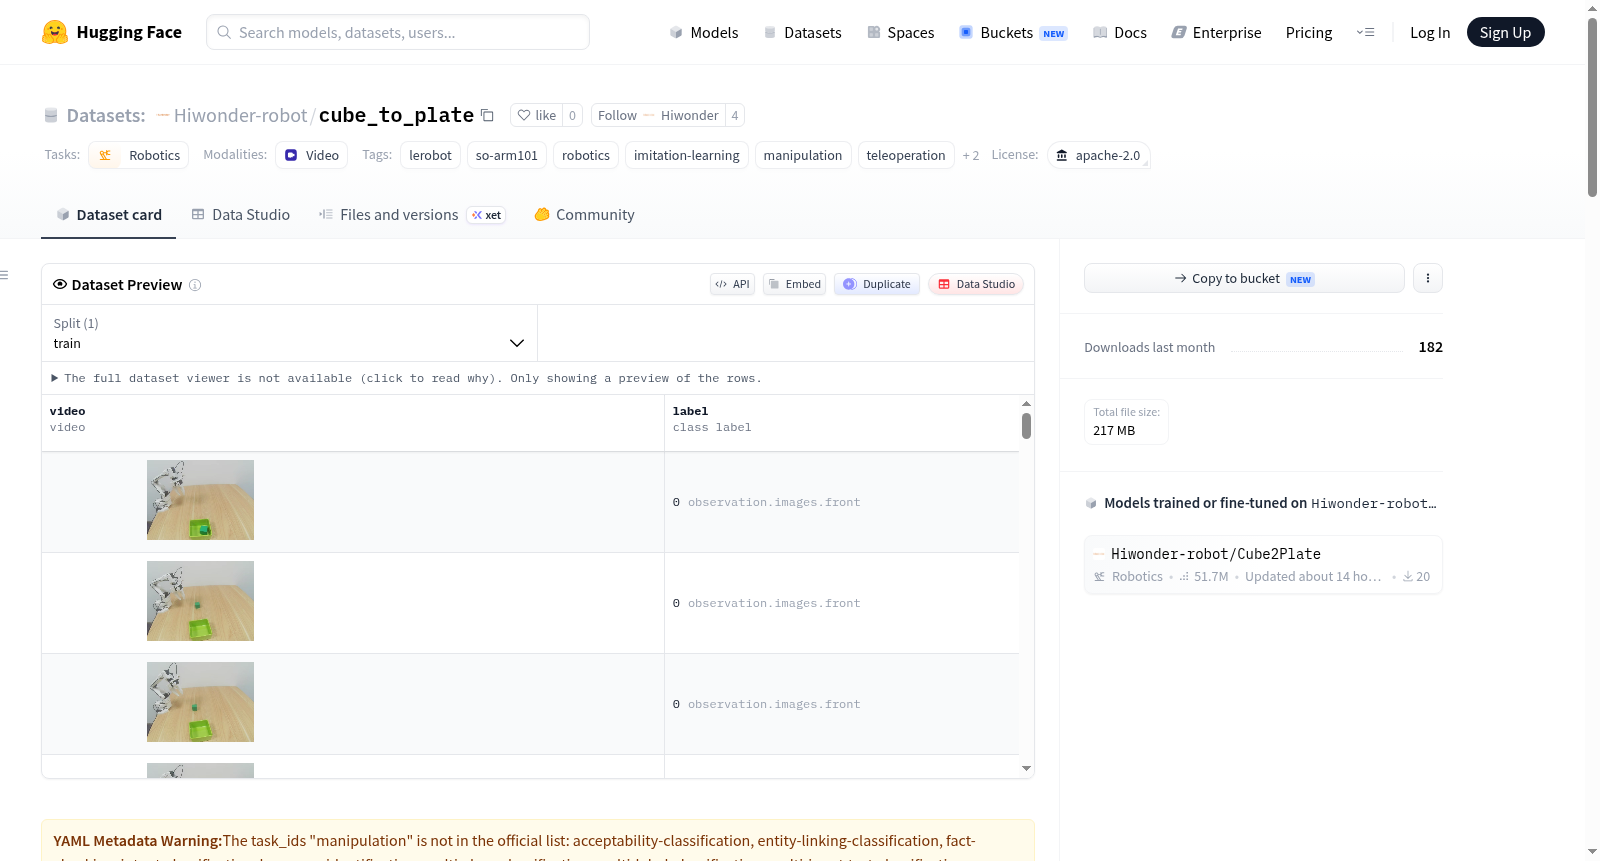
SO-ARM101 Cube2Plate数据集是一个用于机器人模仿学习的开源数据集,专为Cube2Plate任务设计。该任务要求机器人手臂拾取一个立方体并将其放置到一个盘子上。数据集通过遥操作方式使用SO-ARM101机械臂收集,包含完整的演示轨迹数据,适用于在LeRobot框架下训练和评估模仿学习策略。数据格式遵循LeRobot标准,包括机器人演示轨迹、视觉观察(如前视图像observation.images.front和手眼图像observation.images.handeye),以及可能的机器人状态、动作、时间戳、片段索引和帧索引。数据集旨在支持SO-ARM101操作策略训练、行为克隆实验和立方体到盘子机器人操控研究。但需注意,数据集仅针对特定任务,性能可能受摄像头位置、光照条件、物体放置和机器人校准等因素影响,且泛化能力有限,实际部署时应谨慎测试以避免碰撞或硬件损坏。
The SO-ARM101 Cube2Plate dataset is an open-source dataset for robot imitation learning, specifically designed for the Cube2Plate task. This task requires a robotic arm to pick up a cube and place it onto a plate. The dataset is collected via teleoperation using the SO-ARM101 robotic arm and contains complete demonstration trajectory data, suitable for training and evaluating imitation learning strategies within the LeRobot framework. The data format follows the LeRobot standard, including robot demonstration trajectories, visual observations (such as front-view images observation.images.front and hand-eye images observation.images.handeye), as well as possible robot states, actions, timestamps, segment indices, and frame indices. The dataset aims to support SO-ARM101 operational strategy training, behavior cloning experiments, and research on cube-to-plate robotic manipulation. However, it should be noted that the dataset is task-specific, and its performance may be affected by factors such as camera position, lighting conditions, object placement, and robot calibration, with limited generalization capabilities. Careful testing is recommended during real-world deployment to avoid collisions or hardware damage.
数据集概述
- 数据集名称:SO-ARM101 Cube2Plate 数据集
- 存储库:Hiwonder-robot/cube_to_plate
- 许可证:Apache-2.0
任务描述
机器人需抓取一个立方体并将其放置到盘子上(Pick-and-Place 任务)。
机器人平台
- 机器人型号:SO-ARM101
- 采集方式:远程操控(Teleoperation)
- 框架:LeRobot
数据格式
数据集遵循 LeRobot 格式,包含机器人演示轨迹和视觉观测。可用的图像观测包括:
observation.images.front(前部相机)observation.images.handeye(手眼相机)
此外,根据 LeRobot 记录配置,数据可能包含机器人状态、动作、时间戳、回合索引和帧索引。
数据采集
通过人工操作 SO-ARM101 机械臂完成 Cube2Plate 任务,每个回合记录一个完整的演示轨迹。
预期用途
- 训练 SO-ARM101 操作策略
- 模仿学习实验
- 行为克隆
- LeRobot 策略训练与评估
- 立方体到盘子操作研究
使用方法
在 LeRobot 中使用以下数据集 ID 加载: bash Hiwonder-robot/cube_to_plate
示例代码: python from lerobot.common.datasets.lerobot_dataset import LeRobotDataset dataset = LeRobotDataset("Hiwonder-robot/cube_to_plate") frame = dataset[0] print(frame.keys())
相关模型
基于该数据集训练的模型: text Hiwonder-robot/Cube2Plate
局限性
- 仅适用于 Cube2Plate 任务
- 性能受相机位置、光照条件、物体放置和机器人校准影响
- 可能无法泛化到不同物体、环境或机器人配置
- 实际部署前需仔细测试,避免碰撞或硬件损坏
引用方式
使用本数据集时,请引用 Hugging Face 数据集存储库: text Hiwonder-robot/cube_to_plate