pepijn223/super_poulain_qwen36moe-10
收藏资源简介:
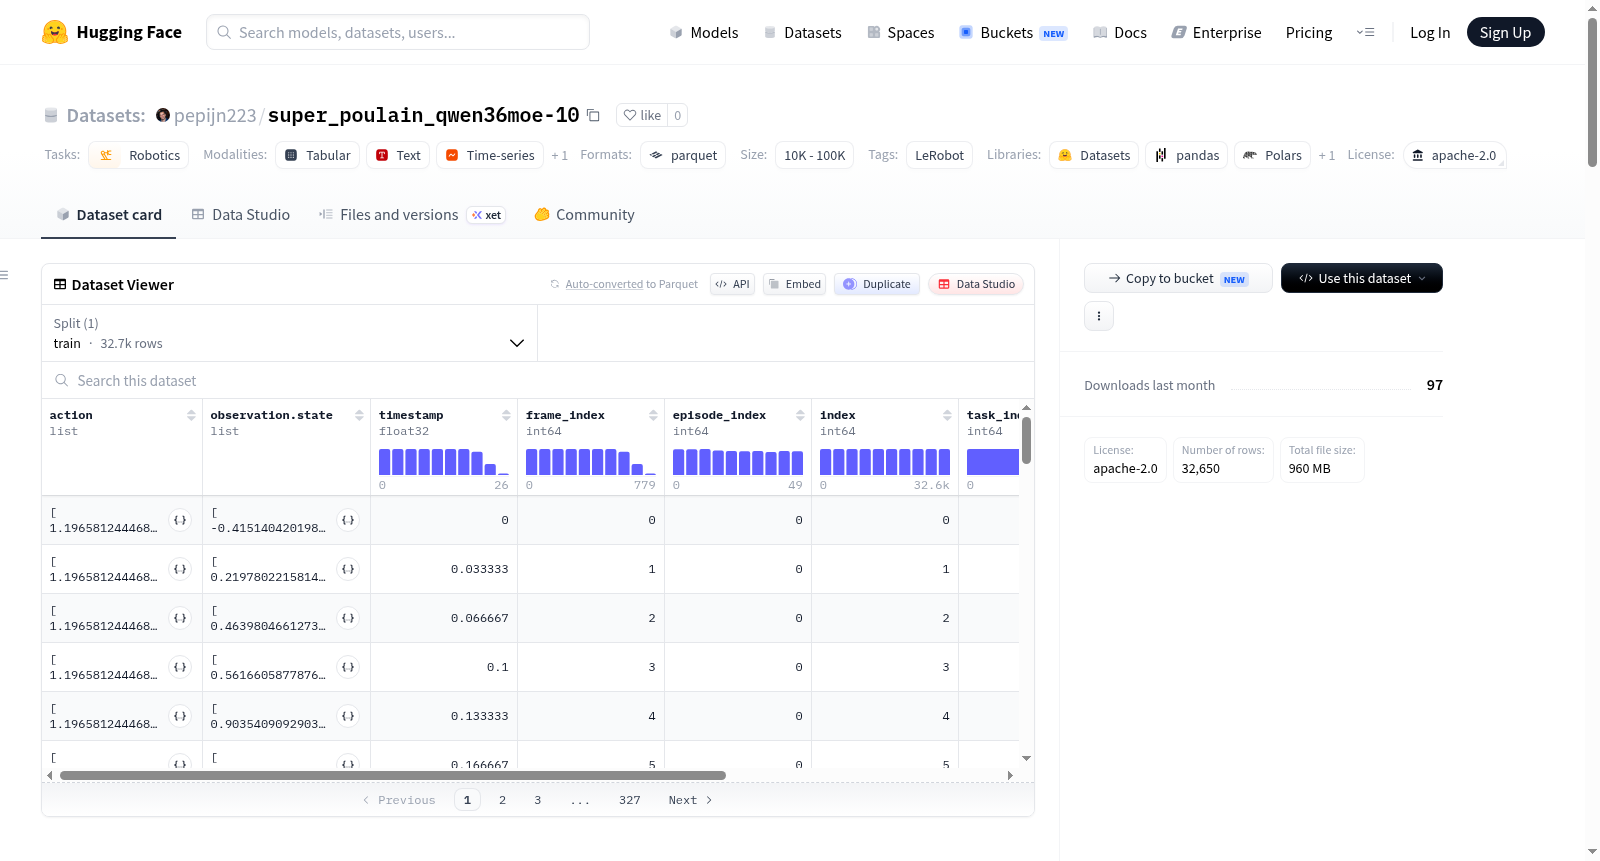
该数据集是通过LeRobot创建的,主要用于机器人技术领域。数据集包含50个episodes,总计32650帧,帧率为30fps。数据以parquet格式存储,总数据文件大小为100MB,视频文件大小为200MB。数据集记录了omx_follower类型机器人的动作和状态信息,包括6个关节位置(shoulder_pan.pos、shoulder_lift.pos、elbow_flex.pos、wrist_flex.pos、wrist_roll.pos、gripper.pos),以及来自前端和腕部的图像观测(480x640分辨率,RGB三通道)。
This dataset was created using LeRobot and is primarily used in the field of robotics. It contains 50 episodes with a total of 32,650 frames at 30fps. The data is stored in parquet format, with a total data file size of 100MB and video file size of 200MB. The dataset records action and state information of an omx_follower type robot, including 6 joint positions (shoulder_pan.pos, shoulder_lift.pos, elbow_flex.pos, wrist_flex.pos, wrist_roll.pos, gripper.pos), as well as image observations from front and wrist cameras (480x640 resolution, RGB three channels).