
IsaacSkill
收藏资源简介:
IsaacSkill是由NVIDIA Isaac Lab平台支持构建的高保真机器人操作技能数据集,专注于基础技能的多任务覆盖与仿真到现实的迁移评估。该数据集包含丰富的物体操作任务,通过高精度仿真环境捕捉任务动态特性,旨在解决传统数据集在技能粒度评估方面的不足。其数据来源基于模块化设计的技能演示,支持对抓取、放置、倾倒等核心技能的独立分析,为机器人泛化能力研究提供标准化测试基准。
IsaacSkill is a high-fidelity robotic manipulation skill dataset built on the NVIDIA Isaac Lab platform, focusing on multi-task coverage of basic robotic skills and sim-to-real transfer evaluation. This dataset includes a rich set of object manipulation tasks, captures task dynamics via high-precision simulation environments, and aims to address the limitations of traditional datasets in skill granularity assessment. Its data originates from modularly designed skill demonstrations, which supports independent analysis of core skills such as grasping, placing, and pouring, and provides a standardized test benchmark for research on robotic generalization capabilities.
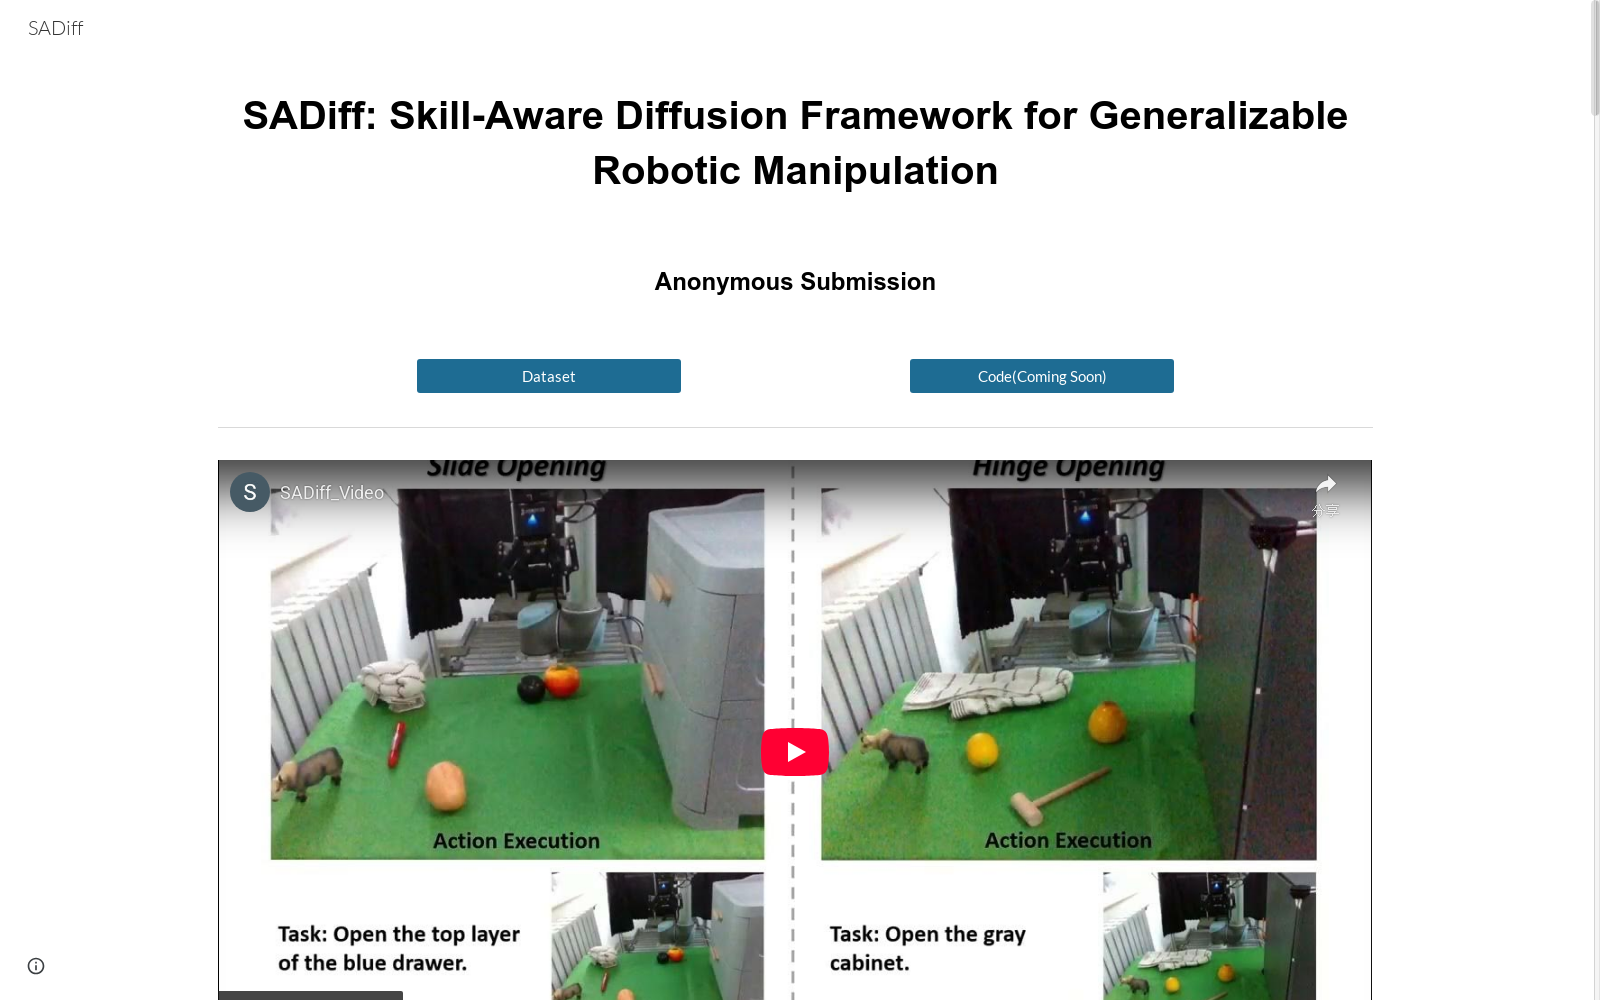
- 1Skill-Aware Diffusion for Generalizable Robotic Manipulation山东大学·控制科学与工程学院; 曼彻斯特大学·计算机科学系 · 2026年


