ecappiell/weighted_boxes_experiment_20260529_090003
收藏资源简介:
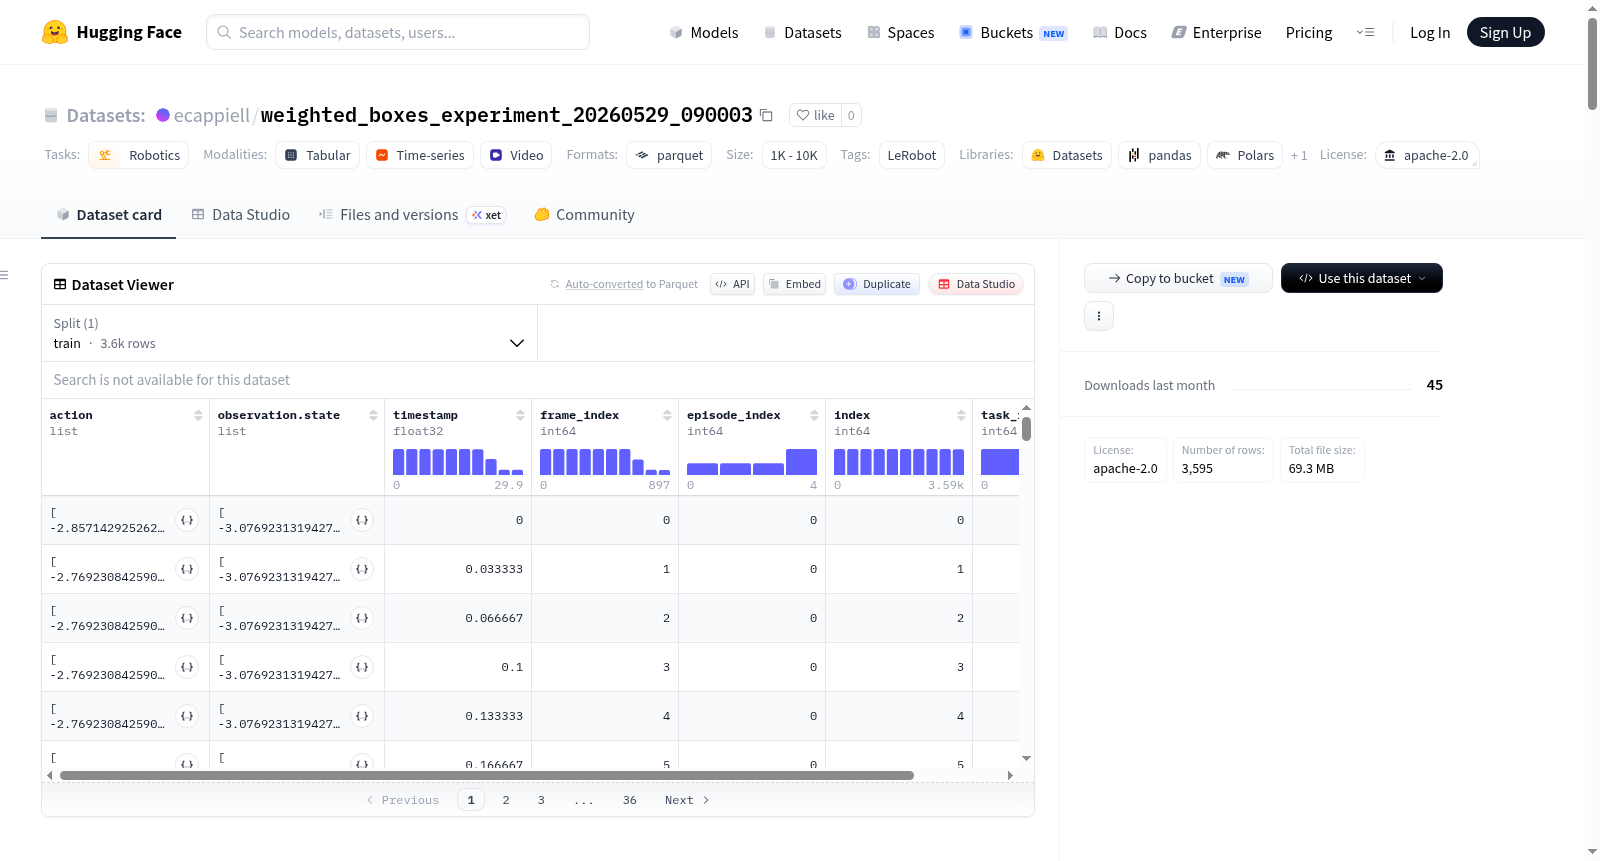
该数据集是使用LeRobot创建的机器人数据集,专注于机器人控制任务。它包含机器人动作和观测数据,其中动作数据包括6个关节(如肩部平移、肩部提升、肘部弯曲、腕部弯曲、腕部旋转和夹爪)的位置信息。观测数据包括111维的状态特征,涵盖关节位置、原始电流、负载、硬件速度、滤波速度、估计外部扭矩、模型扭矩(如重力、摩擦、科里奥利力、惯性力)以及工具中心点(TCP)的力和扭矩。此外,数据集还提供来自顶部和角落摄像头的视频观测,分辨率为480x640,帧率为30fps,视频编码为AV1。数据集总共有5个episodes,3595帧,1个任务,数据以Parquet文件(总大小100MB)和视频文件(总大小200MB)格式存储,适用于机器人学习和强化学习应用。
This dataset is a robotics dataset created using LeRobot, focusing on robot control tasks. It includes robot actions and observations, where action data consists of position information for 6 joints (e.g., shoulder pan, shoulder lift, elbow flex, wrist flex, wrist roll, and gripper). Observation data includes 111-dimensional state features covering joint positions, raw currents, loads, hardware velocities, filtered velocities, estimated external torques, model torques (e.g., gravity, friction, coriolis, inertial), and tool center point (TCP) forces and torques. Additionally, the dataset provides video observations from top and corner cameras with a resolution of 480x640, a frame rate of 30fps, and AV1 video encoding. The dataset contains a total of 5 episodes, 3595 frames, and 1 task, stored in Parquet files (total size 100MB) and video files (total size 200MB), suitable for robotics learning and reinforcement learning applications.