dddw123/bimanual_gauze_recording
收藏资源简介:
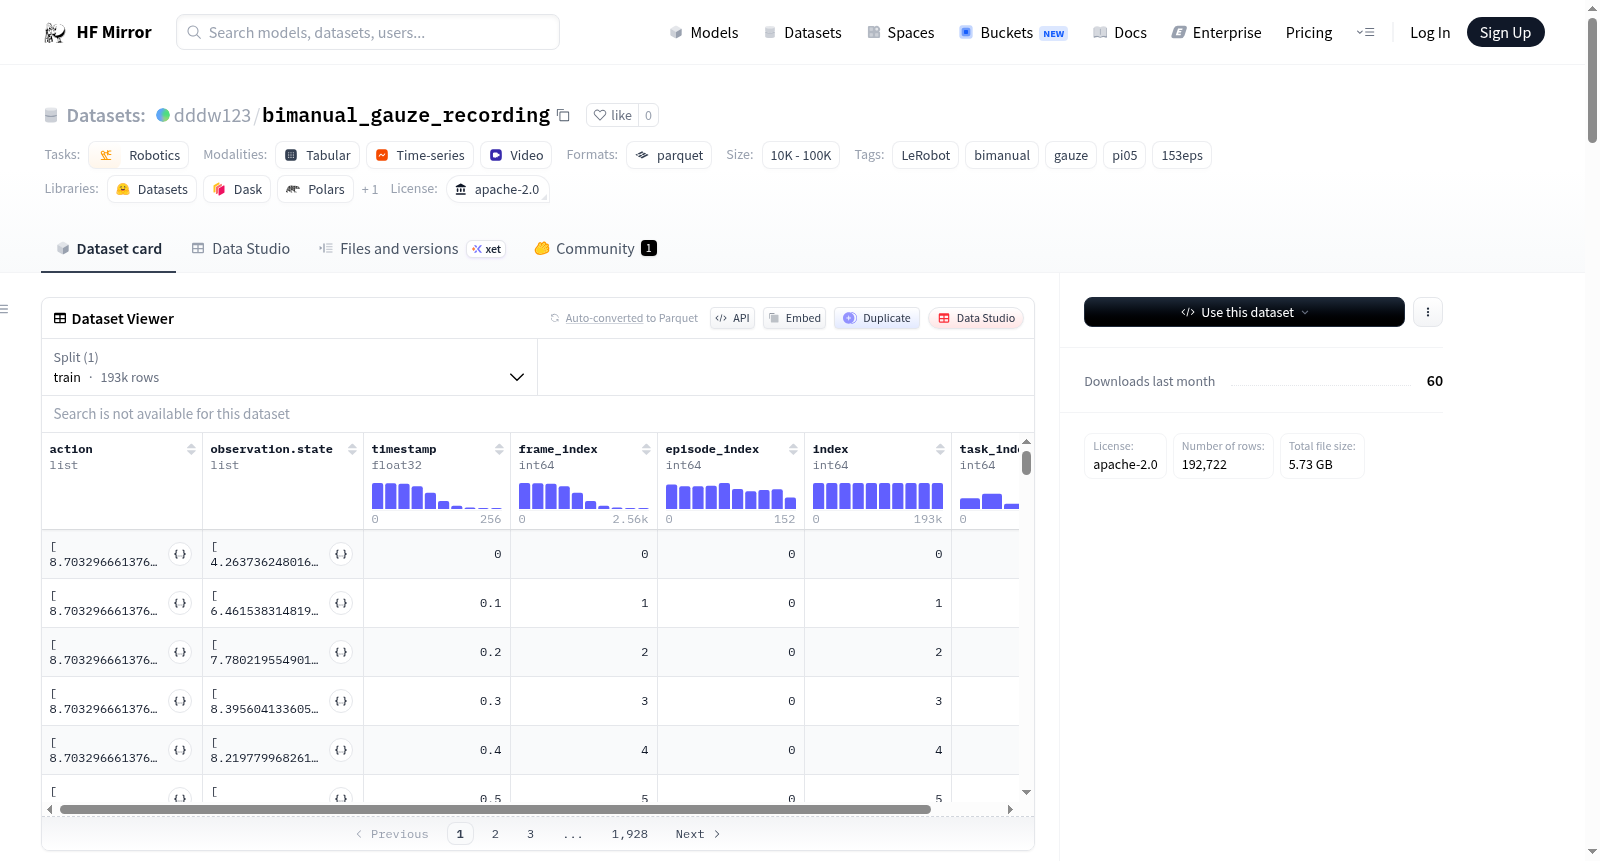
该数据集是通过LeRobot创建的,主要用于机器人技术领域,特别是双手机器人操作。数据集包含153个集,192722帧,涉及13个任务。数据以parquet格式存储,视频以mp4格式存储。数据集的特征包括12个浮点型动作数据(左右肩、肘、腕和抓手的位姿),12个浮点型观察状态数据(与动作数据相同),以及来自三个不同视角的图像数据(左前、顶部和右前),每个视角的图像分辨率为480x640,3通道,帧率为10fps。此外,数据集还包括时间戳、帧索引、集索引、索引和任务索引等元数据。
This dataset was created using LeRobot and is primarily used in the field of robotics, specifically for bimanual robot operations. The dataset contains 153 episodes, 192722 frames, and involves 13 tasks. The data is stored in parquet format, and videos are stored in mp4 format. The features of the dataset include 12 float32 action data (positions of left and right shoulders, elbows, wrists, and grippers), 12 float32 observation state data (same as action data), and image data from three different perspectives (left front, top, and right front), each with a resolution of 480x640, 3 channels, and a frame rate of 10fps. Additionally, the dataset includes metadata such as timestamps, frame indices, episode indices, indices, and task indices.