jellyho/droid_move_banana
收藏资源简介:
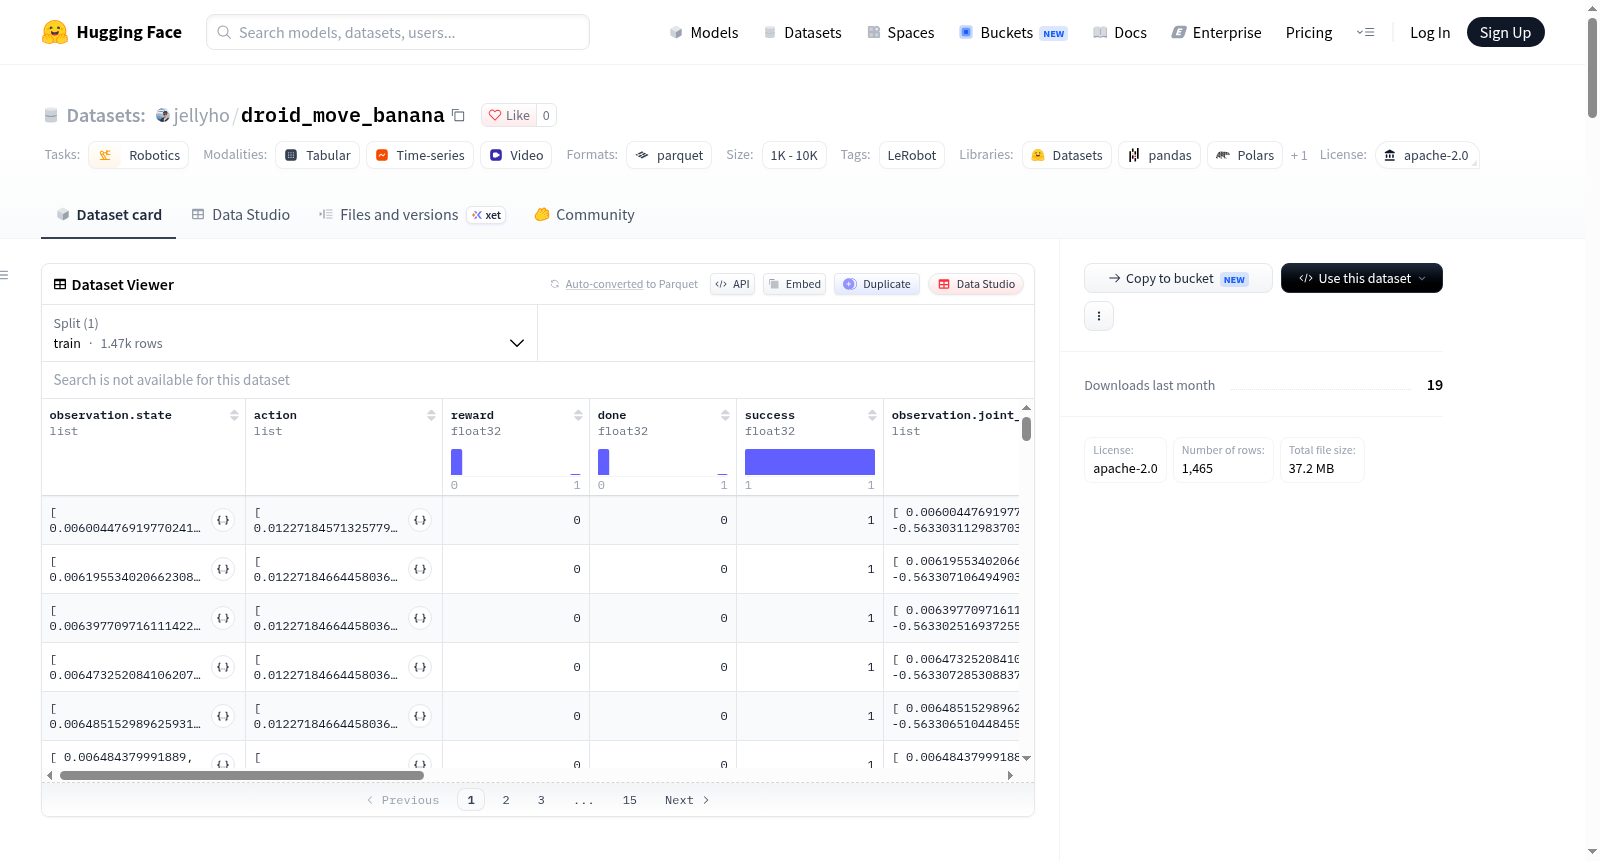
该数据集使用LeRobot创建,是一个机器人学习数据集,专门用于Franka机器人执行任务。数据集包含21个训练片段,总计1465帧,帧率为10fps,涉及一个任务。数据特征丰富,包括机器人的状态观测(如关节位置、关节速度、笛卡尔位置、夹爪位置)、动作、奖励、完成标志、成功标志,以及来自两个摄像头的视频观测(左侧手腕摄像头和左侧侧视摄像头1),视频分辨率为720x1280,编码为AV1。数据集结构以Parquet文件格式存储,总数据文件大小为100MB,视频文件大小为200MB。
This dataset is a robotics learning dataset developed using the LeRobot framework, specifically tailored for tasks executed by Franka robots. It contains 21 training episodes, with a total of 1465 frames at a frame rate of 10 fps, corresponding to one single task. The dataset includes rich data modalities: robot state observations such as joint positions, joint velocities, Cartesian positions, and gripper positions, actions, rewards, completion flags, success flags, as well as visual observations captured by two cameras, namely the left wrist camera and the left side-view camera 1. The video observations have a resolution of 720×1280 and are encoded using the AV1 codec. The dataset is stored in Parquet file format, with a total data file size of 100 MB and a total video file size of 200 MB.