andreaskoepf/dk1_cutlery_basket_2026-04-22
收藏资源简介:
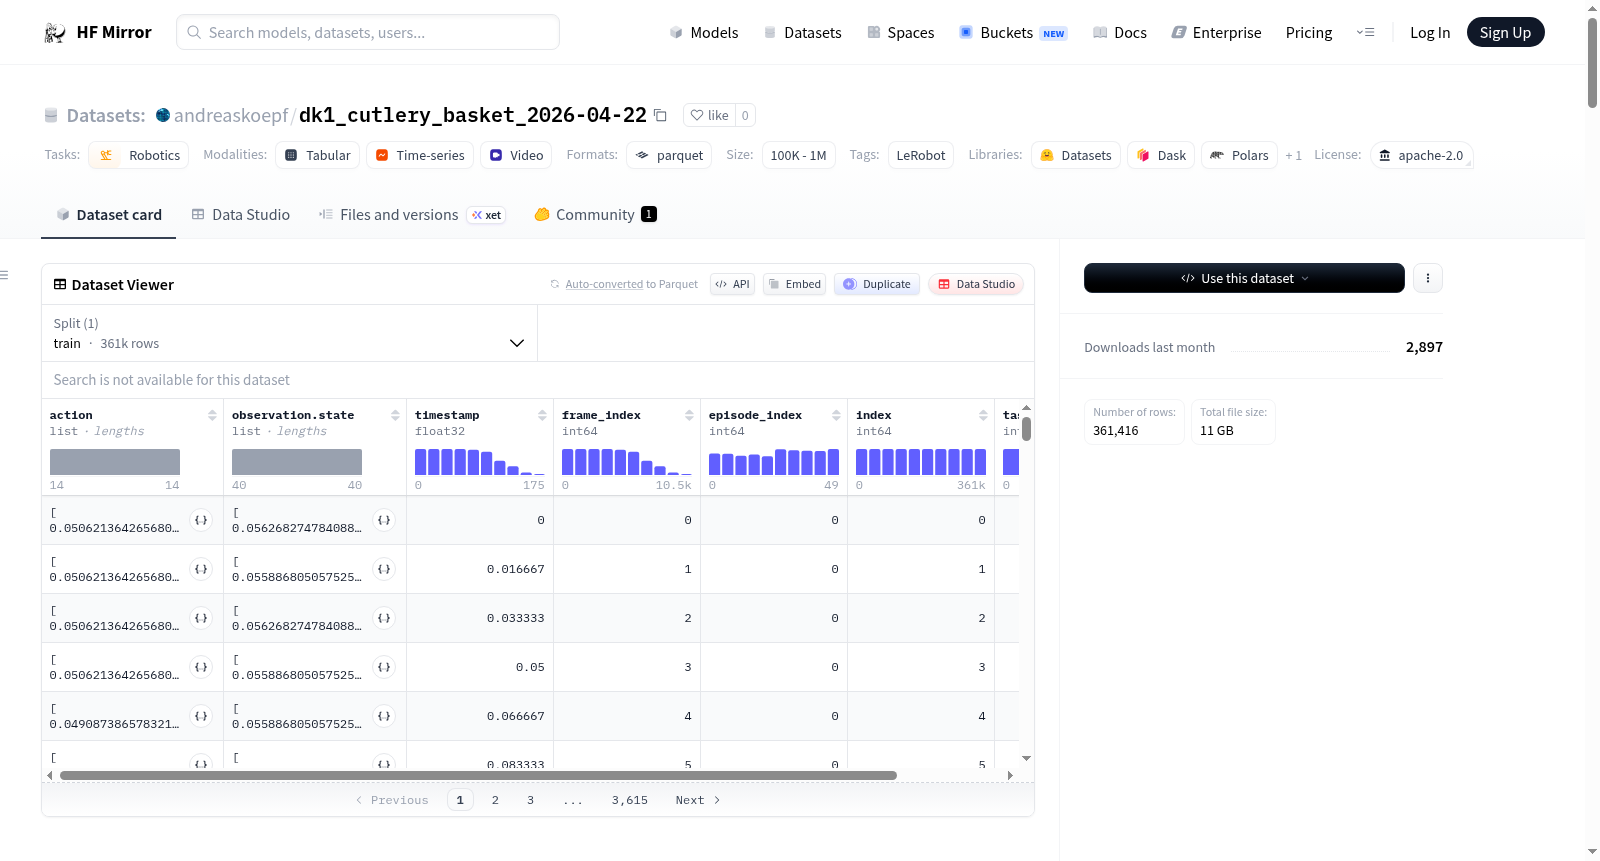
该数据集记录了使用TRLC DK1双机械臂机器人(bi_dk1_follower)执行将餐具从篮子分类到抽屉整理器中的任务。数据集包含50个episodes,总计361,416帧(约100.4分钟,60fps),平均每个episode长度为120.5秒。数据集中包括了三个摄像头的视频流(头部、左腕、右腕),分辨率均为640x360,编码格式为hevc,帧率为60fps。观察空间包括40维的浮点数数组(关节位置、速度、扭矩等),动作空间包括14维的浮点数数组(关节目标位置)。数据集采用Apache-2.0许可证。
This dataset captures the task of sorting cutlery from a basket into drawer compartments using the TRLC DK1 bimanual robot (`bi_dk1_follower`). It includes 50 episodes, totaling 361,416 frames (100.4 minutes @ 60 fps), with an average episode length of 120.5s. The dataset features three camera streams (head, left wrist, right wrist) at 640x360 resolution, HEVC codec, and 60 fps. The observation space consists of a float32[40] array (joint positions, velocities, torques), while the action space is a float32[14] array (joint position targets). The dataset is licensed under Apache-2.0.