ankile/real01c-insert-marker-d1-ours-sobol-r1-25k-nocf
收藏资源简介:
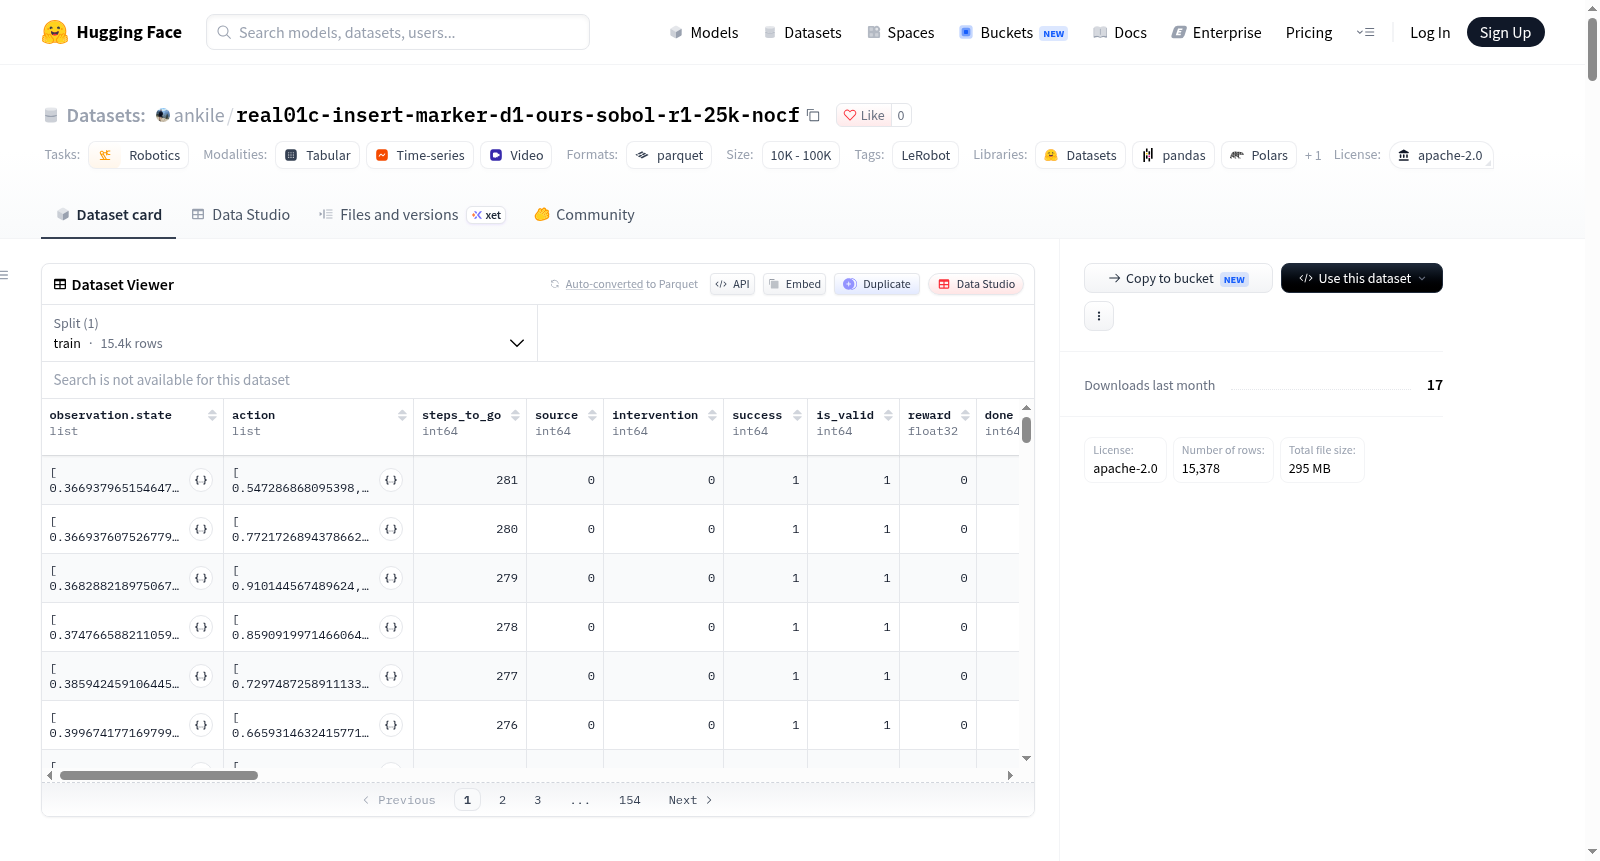
该数据集是一个机器人学习数据集,使用LeRobot工具创建,专注于Franka机器人的操作任务。数据集包含50个训练episodes,总计15378帧,帧率为15fps,数据以parquet格式分块存储。特征包括机器人的状态观测(如笛卡尔位置、关节位置、速度、夹爪位置)、动作(如笛卡尔速度、关节速度、夹爪动作)、以及任务相关指标(如剩余步数、干预标志、成功标志、奖励、完成标志)。此外,数据集提供来自两个摄像头(标识符为18650758_left和25916956_left)的视频观察,分辨率为480x640,编码为h264。数据集适用于机器人控制、强化学习等研究,许可证为Apache 2.0。
This is a robotic learning dataset developed with the LeRobot toolkit, focusing on manipulation tasks for the Franka robot. The dataset consists of 50 training episodes, totaling 15378 frames at a frame rate of 15 fps, with data stored in chunked parquet format. The included features cover robot state observations (e.g., Cartesian position, joint position, velocity, and gripper position), actions (e.g., Cartesian velocity, joint velocity, and gripper commands), as well as task-related metrics including remaining steps, intervention flag, success flag, reward, and completion flag. Additionally, the dataset provides video observations from two cameras with identifiers 18650758_left and 25916956_left, with a resolution of 480x640 and encoded in h264. This dataset is applicable to research in robot control, reinforcement learning and related fields, and is released under the Apache 2.0 license.