rospai_sim_place_cubes_on_tray
收藏资源简介:
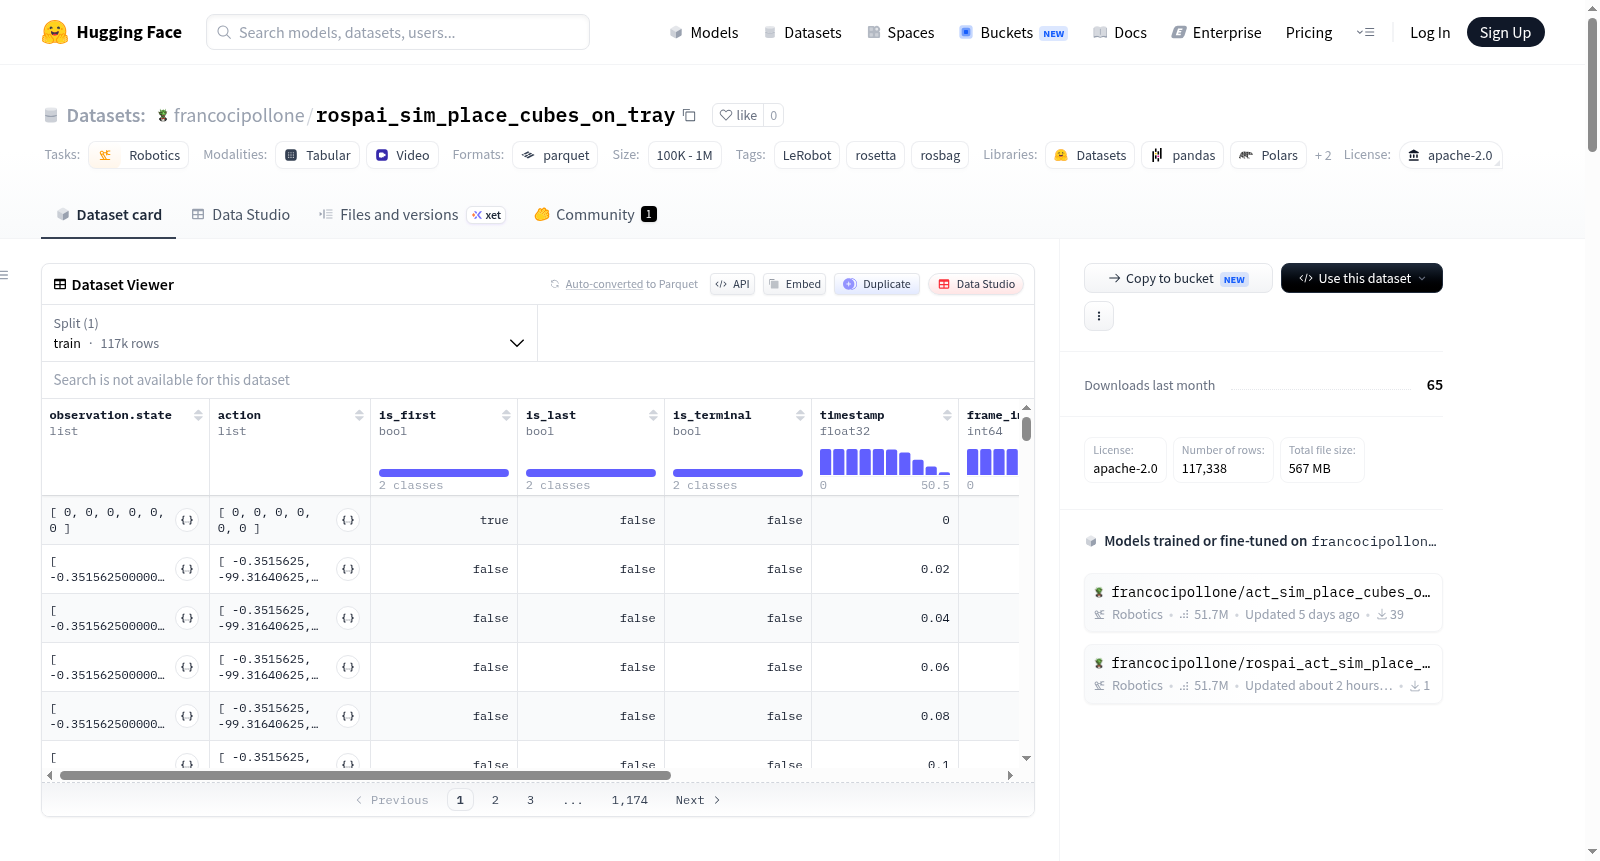
该数据集是一个用于机器人学习的模拟环境数据集,专注于将立方体放置到托盘上的任务。它由LeRobot框架创建,旨在支持机器人操作策略的学习与评估。数据集包含59个完整的任务执行序列(episodes),总计117,338个数据帧,以50fps的帧率采集。数据以分块形式存储,包含100MB的parquet格式数据文件和200MB的mp4格式视频文件。数据集仅包含训练分割。数据特征丰富:观测部分包括来自机器人手腕摄像头和静态固定摄像头的RGB视频流(分辨率均为480x480),以及机器人的6维关节位置状态(包括肩部平移、肩部抬升、肘部弯曲、腕部弯曲、腕部旋转、夹爪关节)。动作空间为对应的6维关节位置命令。此外,数据集还提供了每个帧的时间戳、帧索引、episode索引、任务索引,以及标识episode开始(is_first)、结束(is_last)和终止状态(is_terminal)的布尔标志。机器人平台为so_arm101型。该数据集适用于机器人模仿学习、强化学习或行为克隆等任务,特别是针对涉及抓取与放置操作的策略学习。
This dataset is a simulated environment dataset for robotic learning, focusing on the task of placing a cube onto a tray. It was created using the LeRobot framework to support the learning and evaluation of robotic manipulation policies. The dataset contains 59 complete task execution sequences (episodes), totaling 117,338 data frames collected at a frame rate of 50 fps. The data is stored in chunks, including 100MB parquet-format data files and 200MB mp4-format video files. Only the training split is provided in this dataset. The dataset features rich observation and annotation data: The observation modalities include RGB video streams from the robot's wrist camera and a static fixed camera, both with a resolution of 480x480, as well as the robot's 6-dimensional joint position states (including shoulder translation, shoulder lift, elbow flexion, wrist flexion, wrist rotation, and gripper joint). The action space corresponds to the 6-dimensional joint position commands. Additionally, the dataset provides per-frame information such as timestamps, frame indices, episode indices, task indices, as well as boolean flags marking the start (is_first), end (is_last), and terminal state (is_terminal) of each episode. The robotic platform used is the so_arm101 model. This dataset is suitable for tasks such as robotic imitation learning, reinforcement learning, or behavioral cloning, especially for policy learning involving grasping and placement operations.
数据集概述
- 数据集名称: rospai_sim_place_cubes_on_tray
- 许可证: Apache-2.0
- 任务类别: 机器人学(Robotics)
- 标签: LeRobot, rosetta, rosbag
数据集结构
- 机器人类型: so_arm101
- 总片段数(episodes): 59
- 总帧数: 117,338
- 总任务数: 1
- 数据块大小: 1000 帧
- 数据文件大小: 100 MB
- 视频文件大小: 200 MB
- 帧率(FPS): 50
- 数据分割: 训练集包含全部 59 个片段(0:59)
特征描述
数据集包含以下特征:
| 特征名称 | 数据类型 | 形状 | 说明 |
|---|---|---|---|
observation.images.wrist |
视频 | (480, 480, 3) | 腕部摄像头图像,AV1 编码,50 FPS |
observation.images.static |
视频 | (480, 480, 3) | 静态摄像头图像,AV1 编码,50 FPS |
observation.state |
float64 | (6,) | 机器人关节位置(肩关节、肘关节、腕关节、夹爪等) |
action |
float64 | (6,) | 动作指令(各关节位置目标值) |
is_first |
bool | (1,) | 是否为每个片段的起始帧 |
is_last |
bool | (1,) | 是否为每个片段的结束帧 |
is_terminal |
bool | (1,) | 是否为终止帧 |
timestamp |
float32 | (1,) | 时间戳 |
frame_index |
int64 | (1,) | 帧索引 |
episode_index |
int64 | (1,) | 片段索引 |
index |
int64 | (1,) | 全局索引 |
task_index |
int64 | (1,) | 任务索引 |
数据文件
- 数据存储格式: Parquet(路径:
data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet) - 视频存储格式: MP4(路径:
videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4)
引用信息
目前无具体引用文献(BibTeX 信息待补充)。