ecappiell/weighted_boxes_experiment_20260529_091235
收藏资源简介:
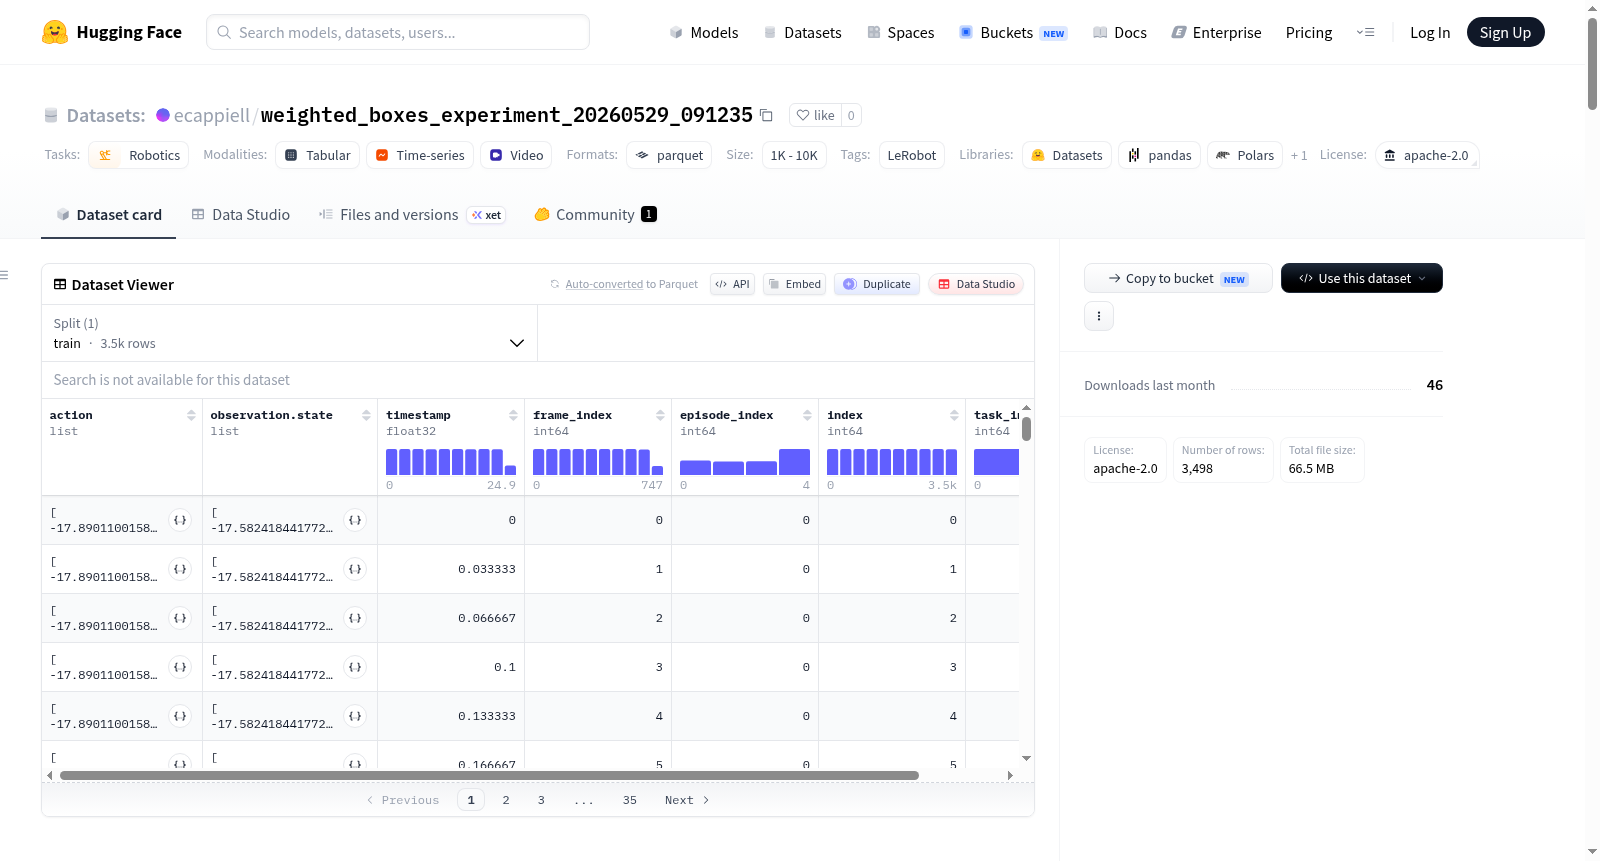
该数据集是使用LeRobot创建的机器人学数据集,专注于机器人控制与感知任务。数据集包含动作和观测数据,其中动作由6个浮点数值组成,对应机器人关节(肩部平移、肩部升降、肘部弯曲、腕部弯曲、腕部旋转和抓取器)的位置控制。观测数据包括状态和图像:状态特征有111个维度,涵盖所有关节的位置、原始电流、负载、硬件速度、速度、原始扭矩、带符号的电流和扭矩、滤波速度、估计外部扭矩以及模型计算的多种扭矩(电机、重力、摩擦、科里奥利、惯性和模型扭矩),还包括TCP(工具中心点)的力和力矩,以及HPI抓取器的外部扭矩、位置和速度;图像特征提供两个视角的视频(顶部和角落),分辨率均为480x640,3通道,帧率30fps,使用AV1编解码器。数据集总共有5个剧集、3498帧和1个任务,数据以parquet文件存储,视频以mp4文件存储,适用于机器人学习和强化学习应用。
This dataset is a robotics dataset created using LeRobot, focusing on robot control and perception tasks. It includes action and observation data: actions consist of 6 float values corresponding to position control of robot joints (shoulder pan, shoulder lift, elbow flex, wrist flex, wrist roll, and gripper). Observations comprise state and images: state features have 111 dimensions, covering joint positions, raw currents, loads, hardware velocities, velocities, raw torques, signed currents and torques, filtered velocities, estimated external torques, and model-calculated torques (motor, gravity, friction, coriolis, inertial, and model torques) for all joints, as well as TCP (Tool Center Point) forces and torques, and HPI gripper external torque, position, and velocity; image features provide video from two perspectives (top and corner), each with a resolution of 480x640, 3 channels, 30fps frame rate, using AV1 codec. The dataset totals 5 episodes, 3498 frames, and 1 task, with data stored in parquet files and videos in mp4 files, suitable for robotics learning and reinforcement learning applications.