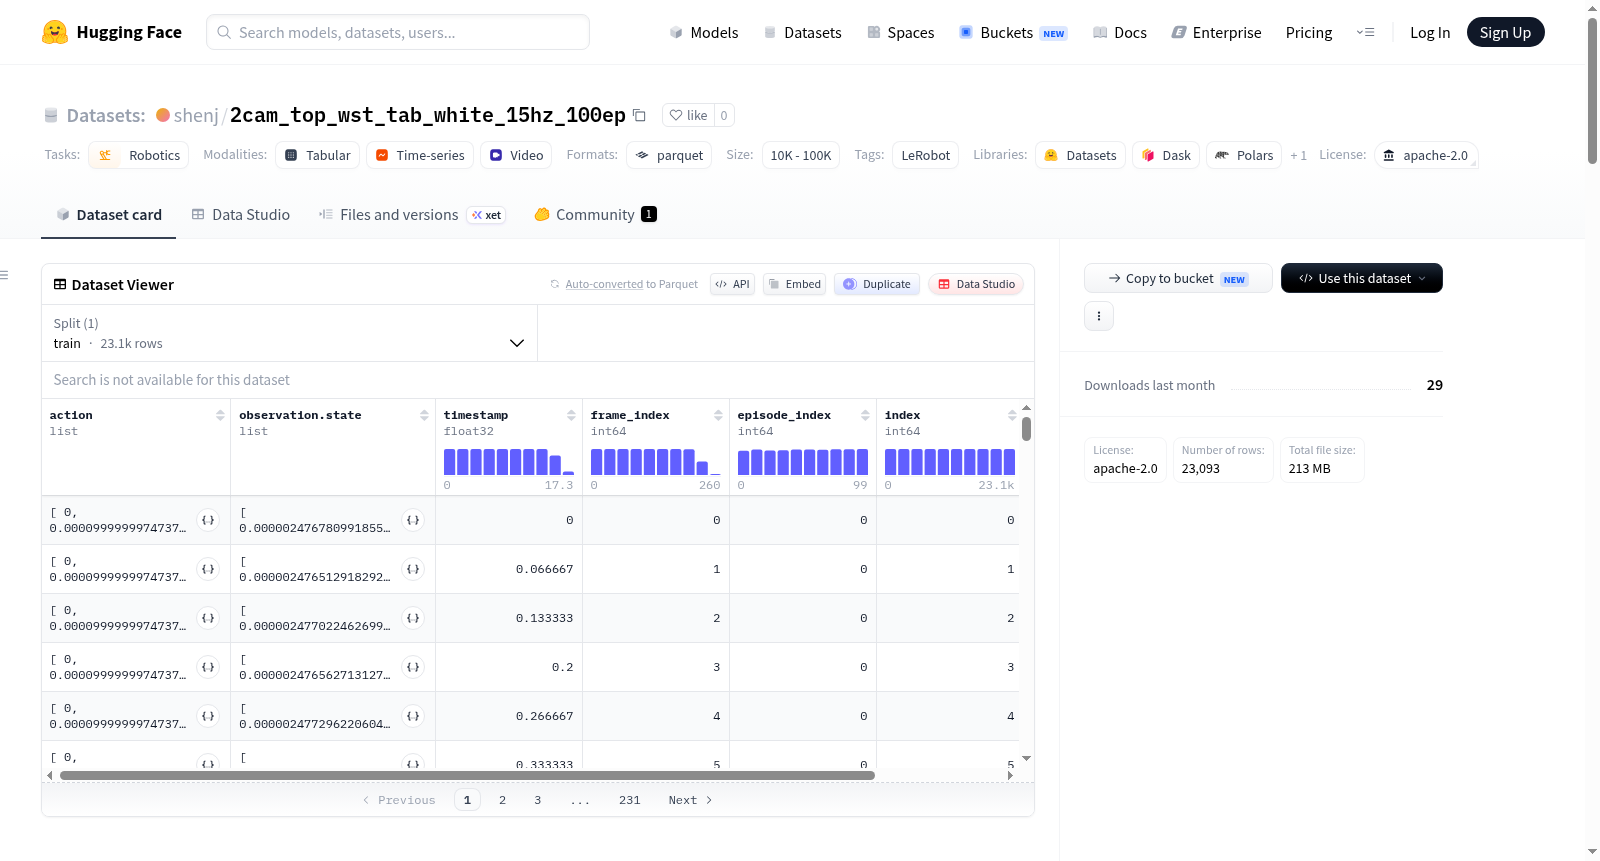
2cam_top_wst_tab_white_15hz_100ep
收藏资源简介:
该数据集是一个机器人操作数据集,使用LeRobot工具创建,采用Apache-2.0许可证,属于LeRobot生态系统的一部分,专门用于机器人技术研究。数据集包含100个完整的情节,总计23,093帧数据,涵盖1个任务。数据以分块形式组织,每个数据块约1000帧,原始数据文件总大小约100 MB,对应的视频文件总大小约200 MB。数据采集自isaac_piper机器人平台。核心内容包括:8维浮点向量的机器人动作指令(对应joint1至joint8的8个关节控制量)和机器人状态观测(对应joint1至joint8的8个关节实时状态),以及来自顶部摄像头和腕部摄像头的视觉观测(两个摄像头均提供分辨率为640x480、帧率15 FPS的RGB彩色视频流,视频采用AV1编解码器编码)。此外,数据还包含时间戳、帧索引、情节索引、全局索引和任务索引等元数据,用于时间对齐和数据检索。所有数据被划分为训练集,涵盖全部100个情节。该数据集适用于机器人模仿学习、强化学习、视觉-动作策略学习以及多模态感知与控制等任务。
This dataset is a robotic manipulation dataset created using the LeRobot toolkit, licensed under Apache-2.0, and is part of the LeRobot ecosystem specifically for robotics research. It contains 100 complete episodes, totaling 23,093 frames, covering a single task. The data is organized in chunks, with each chunk containing approximately 1,000 frames. The total size of the raw data files is around 100 MB, while the corresponding video files total approximately 200 MB. The data was collected on the isaac_piper robotic platform. The core content includes: 8-dimensional floating-point vector robot action commands (corresponding to 8 joint control values for joint 1 to joint 8) and robot state observations (corresponding to real-time states of the 8 joints from joint 1 to joint 8), as well as visual observations from the top camera and the wrist camera. Both cameras deliver RGB color video streams with a resolution of 640×480 and a frame rate of 15 FPS, and the videos are encoded with the AV1 codec. In addition, the dataset includes metadata such as timestamps, frame indices, episode indices, global indices, and task indices for time alignment and data retrieval. All data is split into the training set, covering all 100 episodes. This dataset is applicable to tasks such as robotic imitation learning, reinforcement learning, vision-action policy learning, and multimodal perception and control.
数据集概述
该数据集是一个用于机器人操控的仿真数据集,由 LeRobot 框架创建,采用 Apache-2.0 许可证。
核心信息
- 机器人类型: isaac_piper
- 总片段数 (Episodes): 100
- 总帧数 (Frames): 23,093
- 总任务数 (Tasks): 1
- 帧率 (FPS): 15
- 数据集大小 (数据文件): 约 100 MB
- 视频文件大小: 约 200 MB
- 数据集分割: 训练集 (train) 包含全部 100 个片段 (0:100)。
数据结构
数据以 Parquet 文件和 MP4 视频文件的形式组织。
特征 (Features)
| 特征名称 | 数据类型 | 形状 (Shape) | 描述 |
|---|---|---|---|
action |
float32 | (8,) | 8 个关节的动作指令。 |
observation.state |
float32 | (8,) | 8 个关节的观测状态。 |
observation.images.top |
video | (480, 640, 3) | 顶部摄像头图像,分辨率 480x640,3 通道 (RGB),AV1 编码,15 FPS。 |
observation.images.wrist |
video | (480, 640, 3) | 腕部摄像头图像,分辨率 480x640,3 通道 (RGB),AV1 编码,15 FPS。 |
timestamp |
float32 | (1,) | 时间戳。 |
frame_index |
int64 | (1,) | 帧索引。 |
episode_index |
int64 | (1,) | 片段索引。 |
index |
int64 | (1,) | 全局索引。 |
task_index |
int64 | (1,) | 任务索引。 |
可视化
您可以通过以下链接在 LeRobot 可视化空间中预览此数据集:
https://huggingface.co/spaces/lerobot/visualize_dataset?path=shenj/2cam_top_wst_tab_white_15hz_100ep