libero_goal
收藏资源简介:
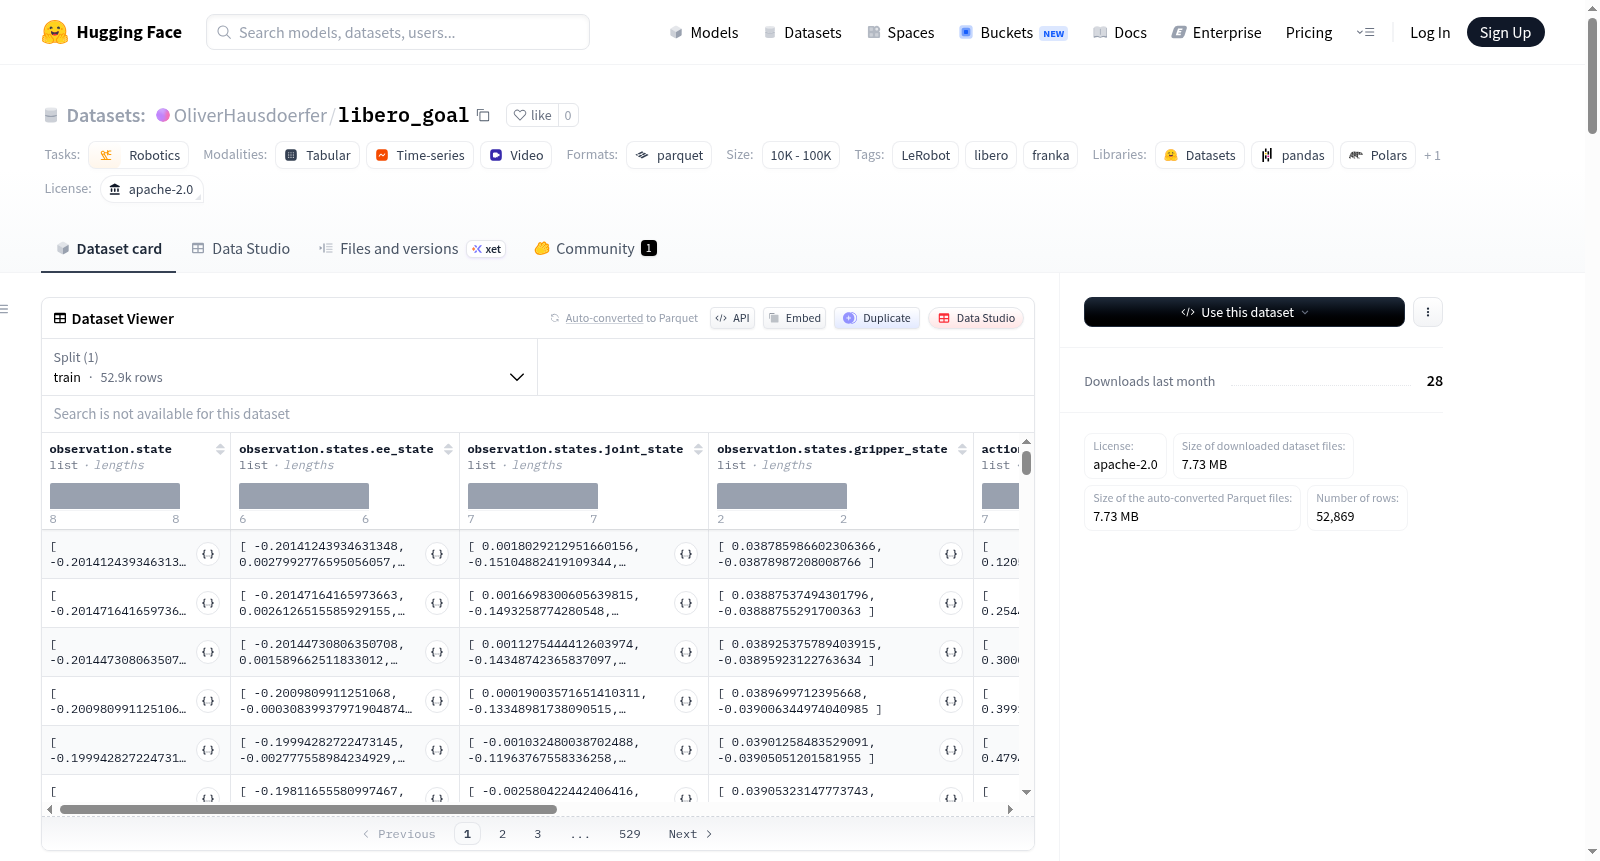
该数据集由LeRobot项目创建,包含机器人操作相关的多模态数据。数据集采用Apache 2.0许可协议,包含431个episodes、52869帧数据,覆盖10个不同任务。数据以parquet文件格式存储,总数据文件大小为100MB,视频文件大小为200MB,帧率为20fps。数据集包含多种观测数据,如图像(256x256 RGB)、机械臂状态(8维浮点数)、末端执行器状态(6维浮点数)、关节状态(7维浮点数)和夹爪状态(2维浮点数),以及7维的动作数据。所有数据均配有详细的结构描述和元数据信息。该数据集适用于机器人学习、控制算法开发等任务。
This dataset was developed by the LeRobot project and encompasses multimodal data for robotic manipulation tasks. Licensed under the Apache 2.0 open-source license, the dataset comprises 431 episodes and 52,869 frames spanning 10 distinct tasks. The data is stored in Parquet file format, with the total size of Parquet data files being 100 MB, the total size of video files being 200 MB, and a frame rate of 20 fps. It includes diverse observational modalities: 256×256 RGB images, 8-dimensional floating-point robot arm states, 6-dimensional floating-point end-effector states, 7-dimensional floating-point joint states, 2-dimensional floating-point gripper states, as well as 7-dimensional action data. All data is accompanied by comprehensive structural descriptions and metadata. This dataset is applicable to tasks including robotic learning and control algorithm development.
数据集概述
基本信息
- 数据集名称: libero_goal
- 创建工具: LeRobot
- 许可证: Apache 2.0
- 任务类别: 机器人学
- 标签: LeRobot, libero, franka
数据集规模
- 总任务数: 10
- 总情节数: 431
- 总帧数: 52869
- 数据块大小: 1000
- 帧率: 20 FPS
- 数据文件总大小: 100 MB
- 视频文件总大小: 200 MB
- 数据格式: Parquet
- 视频格式: MP4 (AV1 编码)
- 数据拆分: 训练集 (0:431)
机器人平台
- 机器人类型: Franka
数据特征
观测数据
- observation.images.image: RGB 图像,形状 (256, 256, 3),视频格式
- observation.images.wrist_image: 腕部 RGB 图像,形状 (256, 256, 3),视频格式
- observation.state: 状态向量,形状 (8),数据类型 float32,包含位置、轴角、夹爪状态
- observation.states.ee_state: 末端执行器状态,形状 (6),数据类型 float32,包含位置和轴角
- observation.states.joint_state: 关节状态,形状 (7),数据类型 float32,包含7个关节角度
- observation.states.gripper_state: 夹爪状态,形状 (2),数据类型 float32
动作数据
- action: 动作向量,形状 (7),数据类型 float32,包含位置、轴角和夹爪控制
元数据
- timestamp: 时间戳,形状 (1),数据类型 float32
- frame_index: 帧索引,形状 (1),数据类型 int64
- episode_index: 情节索引,形状 (1),数据类型 int64
- index: 索引,形状 (1),数据类型 int64
- task_index: 任务索引,形状 (1),数据类型 int64
文件路径
- 数据文件路径:
data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet - 视频文件路径:
videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4
可视化
- 可视化空间: https://huggingface.co/spaces/lerobot/visualize_dataset?path=OliverHausdoerfer/libero_goal
引用信息
- 论文: 未提供
- 主页: 未提供
- BibTeX: 未提供