Gibson Environment 感知数据集
收藏资源简介:
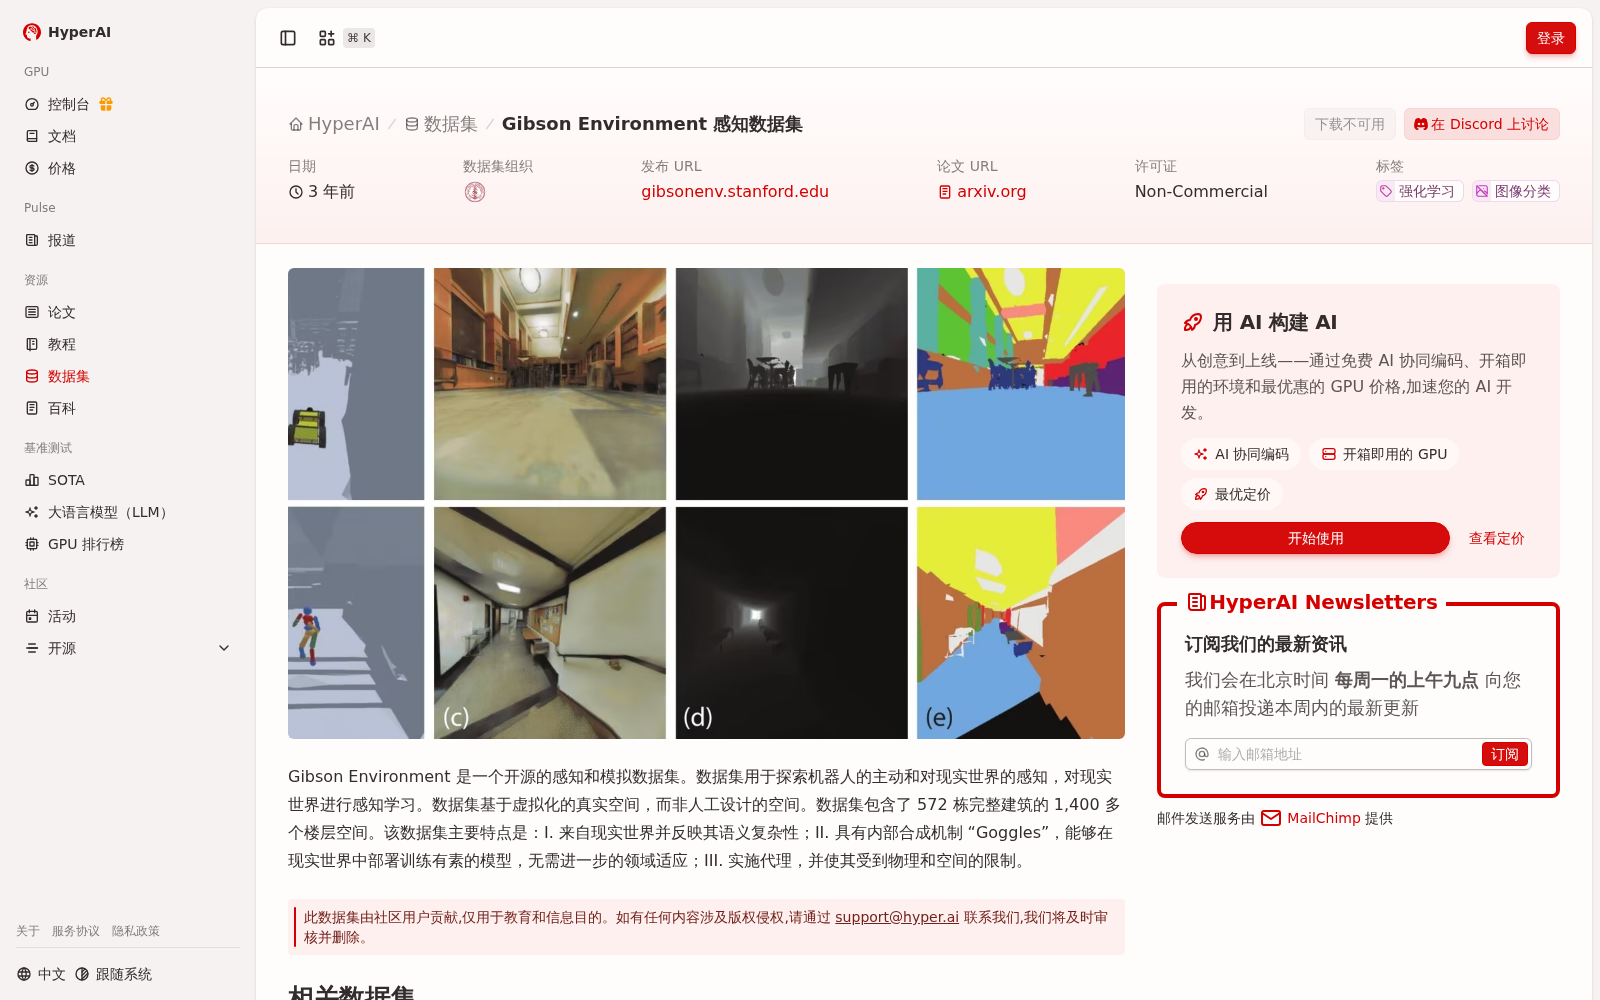
Gibson Environment 是一个开源的感知和模拟数据集。数据集用于探索机器人的主动和对现实世界的感知,对现实世界进行感知学习。数据集基于虚拟化的真实空间,而非人工设计的空间。数据集包含了 572 栋完整建筑的 1,400 多个楼层空间。该数据集主要特点是:I. 来自现实世界并反映其语义复杂性;II. 具有内部合成机制 “Goggles”,能够在现实世界中部署训练有素的模型,无需进一步的领域适应;III. 实施代理,并使其受到物理和空间的限制。
Gibson Environment is an open-source perception and simulation dataset. It is developed to explore robotic active perception, real-world perception, and perceptual learning of the physical world. The dataset is based on virtualized real-world spaces rather than artificially designed environments. It contains over 1,400 floor spaces across 572 complete buildings. The key characteristics of this dataset are as follows: I. It is derived from real-world environments and reflects their semantic complexity; II. It features an internal synthesis mechanism named "Goggles", which enables the deployment of trained models in real-world scenarios without further domain adaptation; III. It implements agents constrained by physical and spatial rules.