Alkatt/eval_LAVLA_Async_VI_100M_40k_b20_whiteblackcube_v2_2026_05_27_white_latency_bench_v6
收藏资源简介:
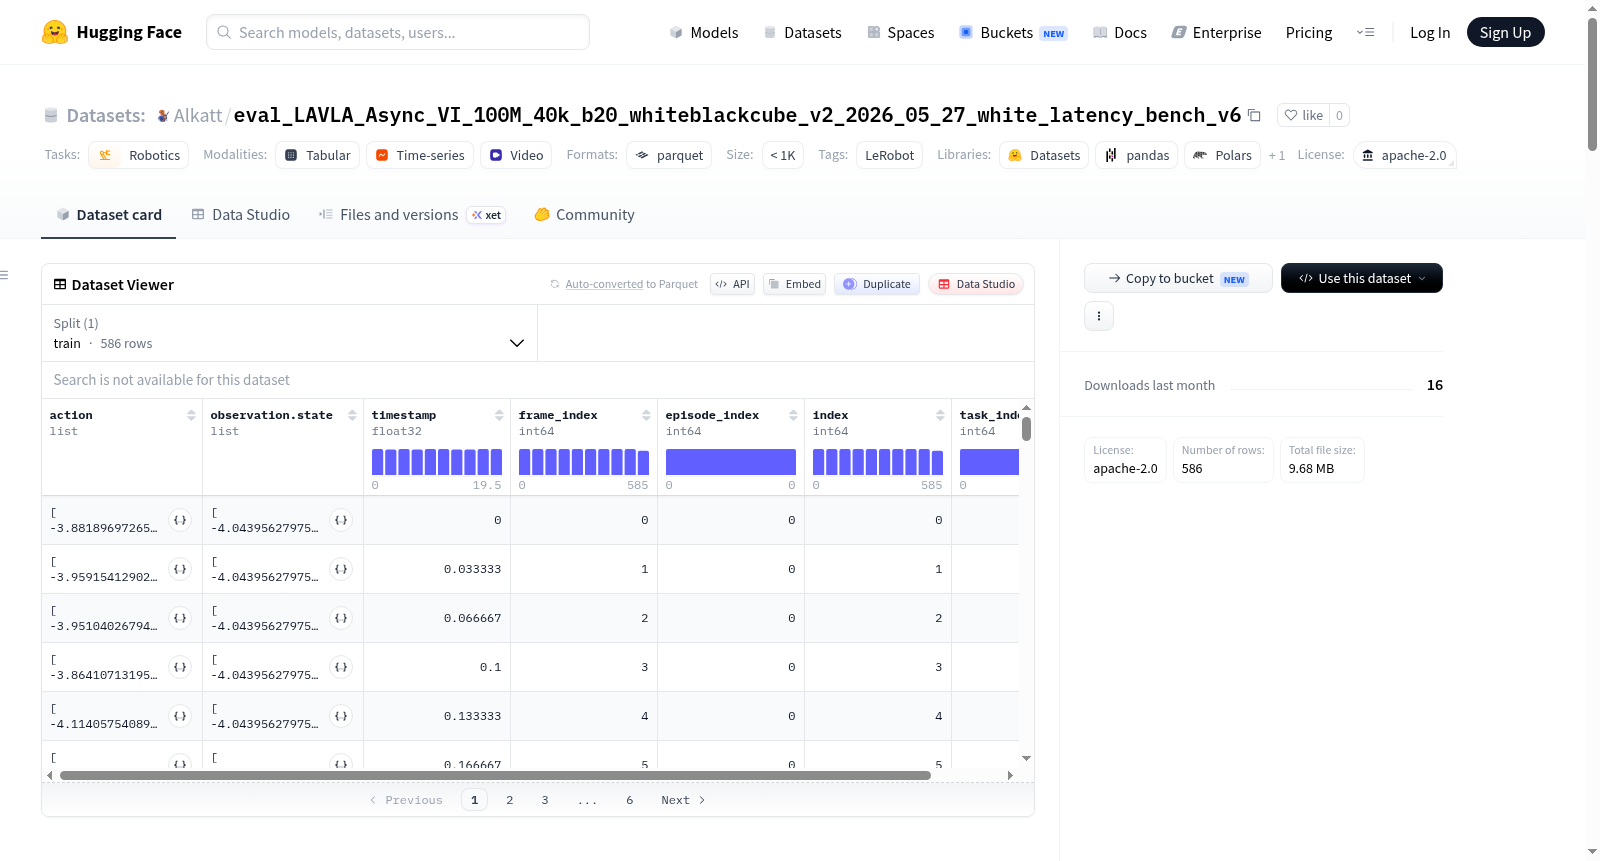
该数据集是一个机器人学数据集,使用LeRobot创建。数据集包含1个任务和1个剧集,总帧数为586,数据文件大小为100MB,视频文件大小为200MB,帧率为30fps。数据格式为Parquet文件,视频格式为MP4。特征包括动作(6个浮点数,对应机械臂关节位置)、观测状态(6个浮点数,对应机械臂关节位置)、三个摄像头图像(每个为480x640x3的视频,编码为av1,无音频)、时间戳、帧索引、剧集索引、索引和任务索引。机器人类型为so_follower,代码库版本为v3.0。数据集适用于机器人控制和研究,并采用Apache 2.0许可证。
This dataset is a robotics dataset created using LeRobot. It contains 1 task and 1 episode, with a total of 586 frames, data file size of 100MB, video file size of 200MB, and a frame rate of 30fps. The data is in Parquet format, and videos are in MP4 format. Features include action (6 float numbers corresponding to robotic arm joint positions), observation state (6 float numbers corresponding to robotic arm joint positions), three camera images (each as a 480x640x3 video, encoded in av1, without audio), timestamp, frame index, episode index, index, and task index. The robot type is so_follower, and the codebase version is v3.0. The dataset is suitable for robotics control and research, and is licensed under Apache 2.0.