rainbowrobotics/icra_0526_compound_rel
收藏资源简介:
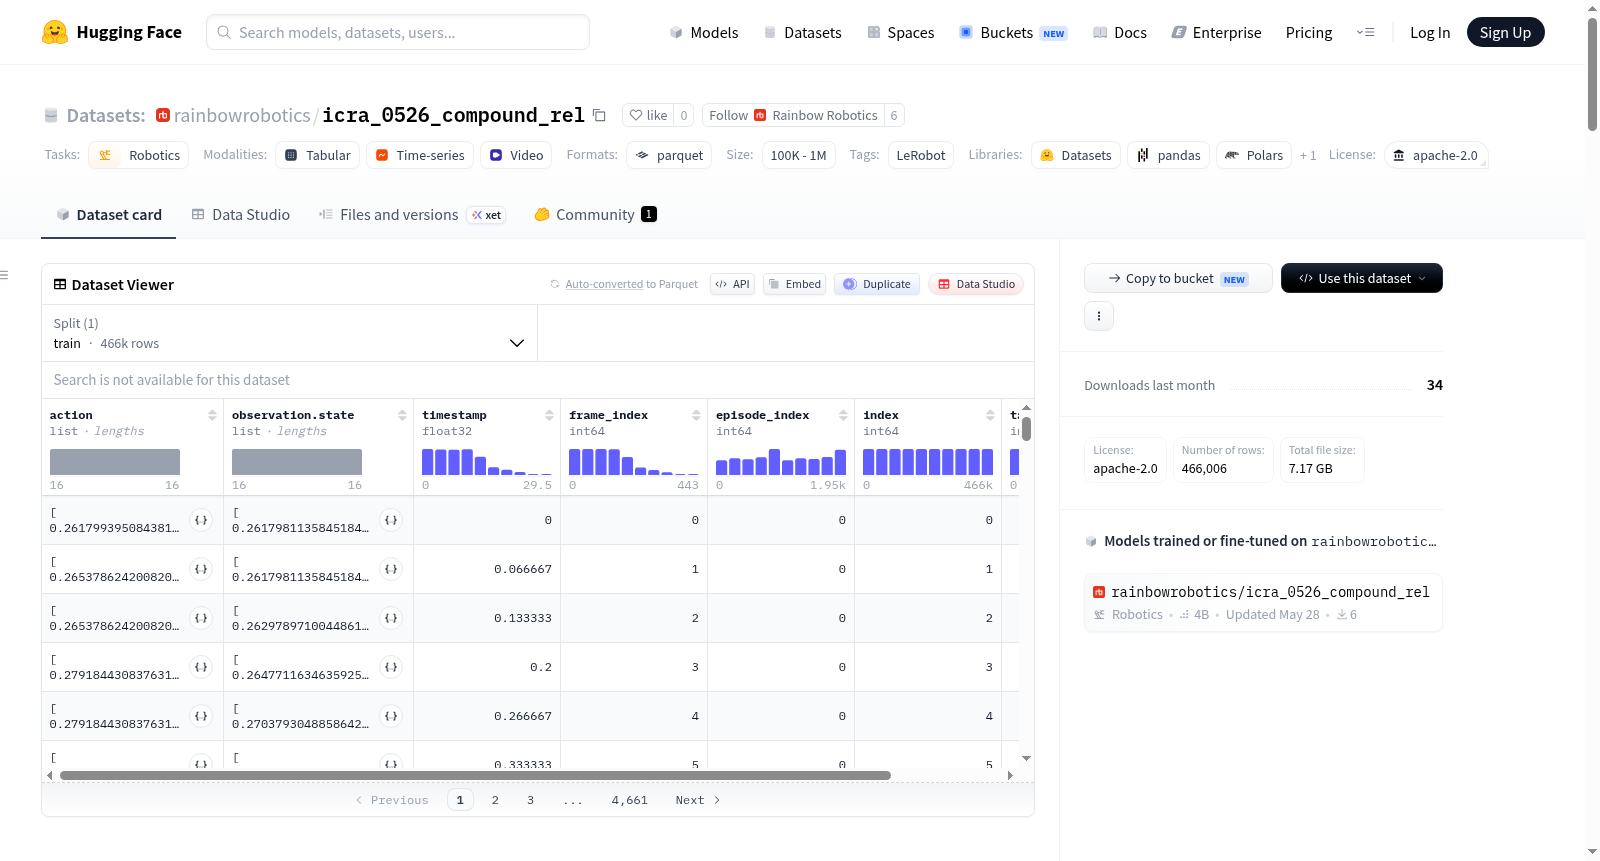
这是一个机器人操作数据集,使用LeRobot创建。数据集包含双臂机器人(左右臂各7个关节和左右夹爪)的动作和观测数据,观测包括机器人状态(关节位置和夹爪状态)以及来自三个视角(前、右、左)的视频图像(分辨率为480x640和640x480,RGB格式)。数据以15fps的帧率采集,总共有1954个episodes、466006帧和3个任务,适用于机器人学习和控制研究。数据格式为parquet,附带视频文件,机器人类型为rby1。
This is a robotic manipulation dataset created using LeRobot. It contains action and observation data for a dual-arm robot (with 7 joints per arm and left/right grippers), where observations include robot state (joint positions and gripper states) and video images from three perspectives (front, right, left) at resolutions of 480x640 and 640x480 in RGB format. Data is collected at 15fps, with a total of 1954 episodes, 466006 frames, and 3 tasks, suitable for robot learning and control research. The data is in parquet format with accompanying video files, and the robot type is rby1.