lyl472324464/2025-11-26-twist-two-bottles-without-rinse
收藏资源简介:
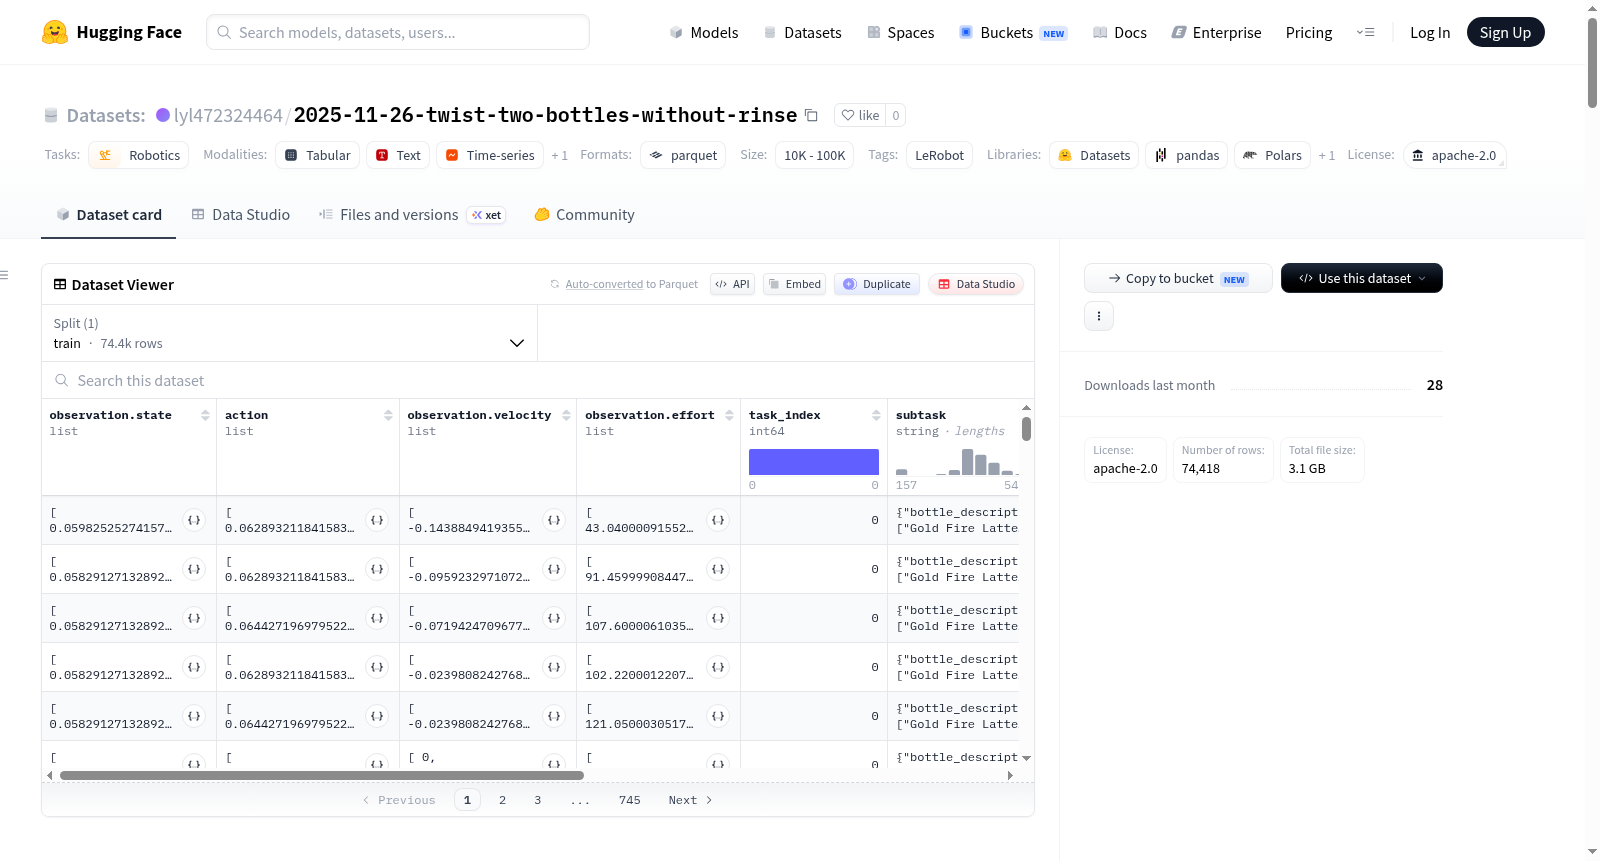
--- license: apache-2.0 task_categories: - robotics tags: - LeRobot configs: - config_name: default data_files: data/*/*.parquet --- This dataset was created using [LeRobot](https://github.com/huggingface/lerobot). ## Dataset Description - **Homepage:** [More Information Needed] - **Paper:** [More Information Needed] - **License:** apache-2.0 ## Dataset Structure [meta/info.json](meta/info.json): ```json { "codebase_version": "v3.0", "robot_type": "aloha", "total_episodes": 48, "total_frames": 74418, "total_tasks": 1, "chunks_size": 1000, "data_files_size_in_mb": 200, "video_files_size_in_mb": 200, "fps": 50, "splits": { "train": "0:48" }, "data_path": "data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet", "video_path": "videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4", "features": { "observation.state": { "dtype": "float32", "shape": [ 14 ], "names": [ [ "left_waist", "left_shoulder", "left_elbow", "left_forearm_roll", "left_wrist_angle", "left_wrist_rotate", "left_gripper", "right_waist", "right_shoulder", "right_elbow", "right_forearm_roll", "right_wrist_angle", "right_wrist_rotate", "right_gripper" ] ] }, "action": { "dtype": "float32", "shape": [ 14 ], "names": [ [ "left_waist", "left_shoulder", "left_elbow", "left_forearm_roll", "left_wrist_angle", "left_wrist_rotate", "left_gripper", "right_waist", "right_shoulder", "right_elbow", "right_forearm_roll", "right_wrist_angle", "right_wrist_rotate", "right_gripper" ] ] }, "observation.velocity": { "dtype": "float32", "shape": [ 14 ], "names": [ [ "left_waist", "left_shoulder", "left_elbow", "left_forearm_roll", "left_wrist_angle", "left_wrist_rotate", "left_gripper", "right_waist", "right_shoulder", "right_elbow", "right_forearm_roll", "right_wrist_angle", "right_wrist_rotate", "right_gripper" ] ] }, "observation.effort": { "dtype": "float32", "shape": [ 14 ], "names": [ [ "left_waist", "left_shoulder", "left_elbow", "left_forearm_roll", "left_wrist_angle", "left_wrist_rotate", "left_gripper", "right_waist", "right_shoulder", "right_elbow", "right_forearm_roll", "right_wrist_angle", "right_wrist_rotate", "right_gripper" ] ] }, "observation.images.cam_high": { "dtype": "video", "shape": [ 3, 480, 640 ], "names": [ "channels", "height", "width" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 50, "video.channels": 3, "has_audio": false } }, "observation.images.cam_low": { "dtype": "video", "shape": [ 3, 480, 640 ], "names": [ "channels", "height", "width" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 50, "video.channels": 3, "has_audio": false } }, "observation.images.cam_left_wrist": { "dtype": "video", "shape": [ 3, 480, 640 ], "names": [ "channels", "height", "width" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 50, "video.channels": 3, "has_audio": false } }, "observation.images.cam_right_wrist": { "dtype": "video", "shape": [ 3, 480, 640 ], "names": [ "channels", "height", "width" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 50, "video.channels": 3, "has_audio": false } }, "task_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "subtask": { "dtype": "string", "shape": [ 1 ], "names": null }, "is_for_training": { "dtype": "bool", "shape": [ 1 ], "names": null }, "timestamp": { "dtype": "float32", "shape": [ 1 ], "names": null }, "frame_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "episode_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "index": { "dtype": "int64", "shape": [ 1 ], "names": null } } } ``` ## Citation **BibTeX:** ```bibtex [More Information Needed] ```
This dataset was created using LeRobot and is designed for robotics control tasks, featuring data from an ALOHA robot with dual arms. It includes 48 training episodes, totaling 74,418 frames at a sampling rate of 50 fps. The features encompass 14-dimensional robot state observations (e.g., positions for left/right arm joints such as waist, shoulder, elbow), actions, velocities, and efforts, along with video observations from four cameras: a high-resolution camera, a low-resolution camera, a left wrist camera, and a right wrist camera, with a resolution of 480x640 and AV1 codec. The dataset is organized in parquet files, with a total data size of approximately 200 MB and video files of about 200 MB, suitable for robot learning and imitation learning research.