ajaysri/long_cable_insertion_2_raw_plus_dagger2x
收藏资源简介:
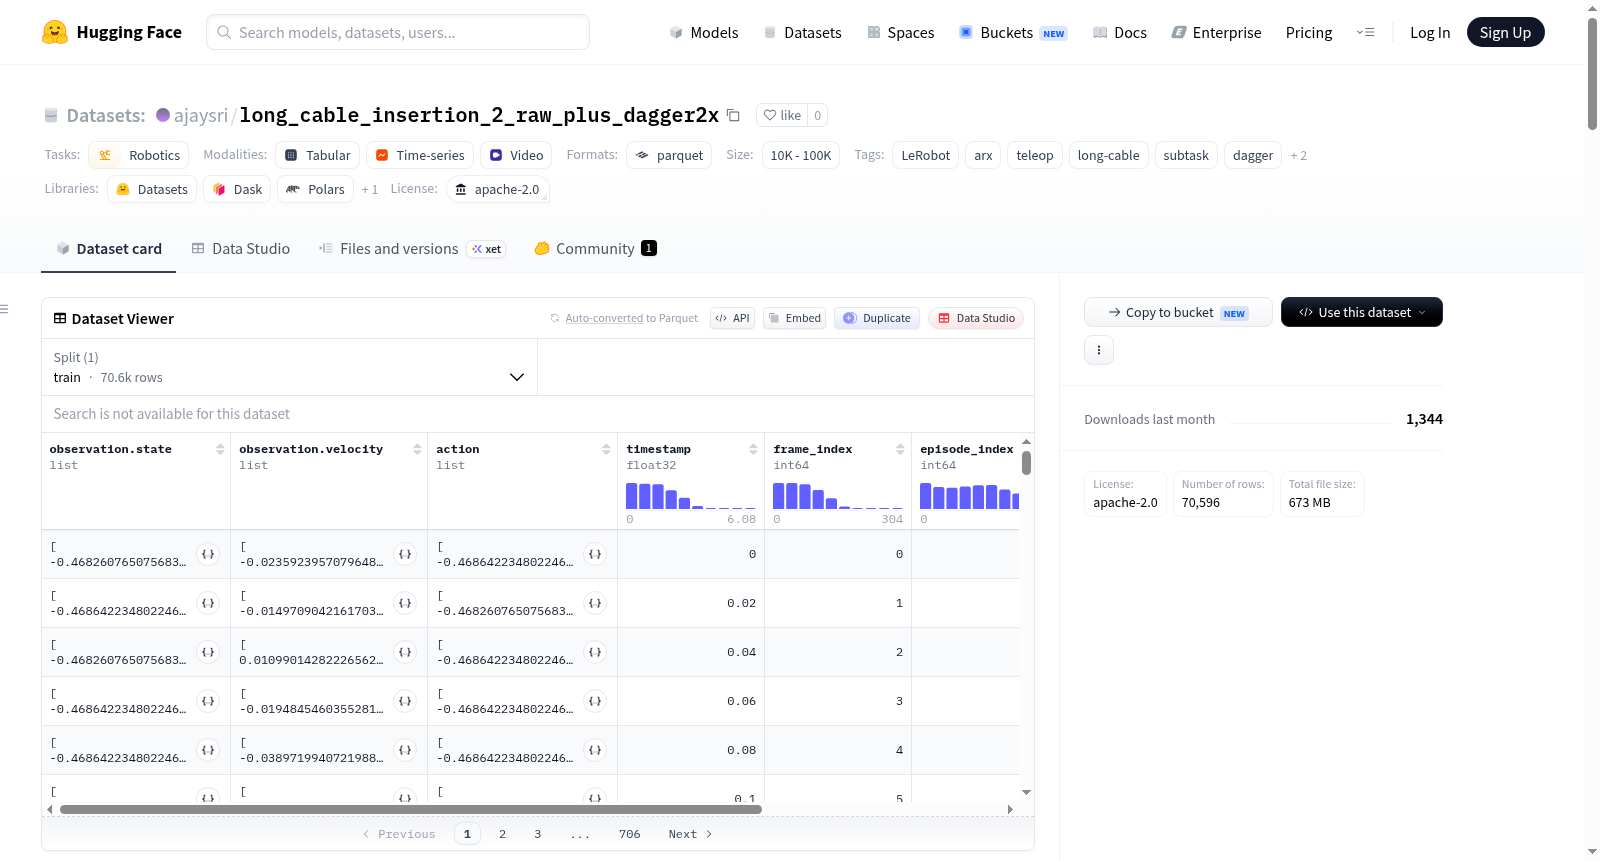
这是一个用于机器人学习的开源数据集,专门针对长电缆插入任务,通过远程操作(teleop)和DAgger算法收集。数据集包含538个总集数、70596个总帧数和3个总任务,数据以50fps的帧率采集。特征包括14维的状态观测、14维的速度观测、14维的动作数据,以及来自三个不同视角(左侧、上方、右侧)的视频观测,每个视频分辨率为360x640像素,采用h264编码。数据集适用于机器人控制、强化学习和模仿学习任务,特别是针对长电缆插入等复杂操作。
This is an open-source dataset for robotics learning, specifically focused on long cable insertion tasks, collected via teleoperation and the DAgger algorithm. It includes 538 total episodes, 70596 total frames, and 3 total tasks, with data captured at 50fps. Features consist of 14-dimensional state observations, 14-dimensional velocity observations, 14-dimensional action data, and video observations from three different perspectives (left, overhead, right), each with a resolution of 360x640 pixels and h264 encoding. The dataset is suitable for robot control, reinforcement learning, and imitation learning tasks, particularly for complex operations like long cable insertion.