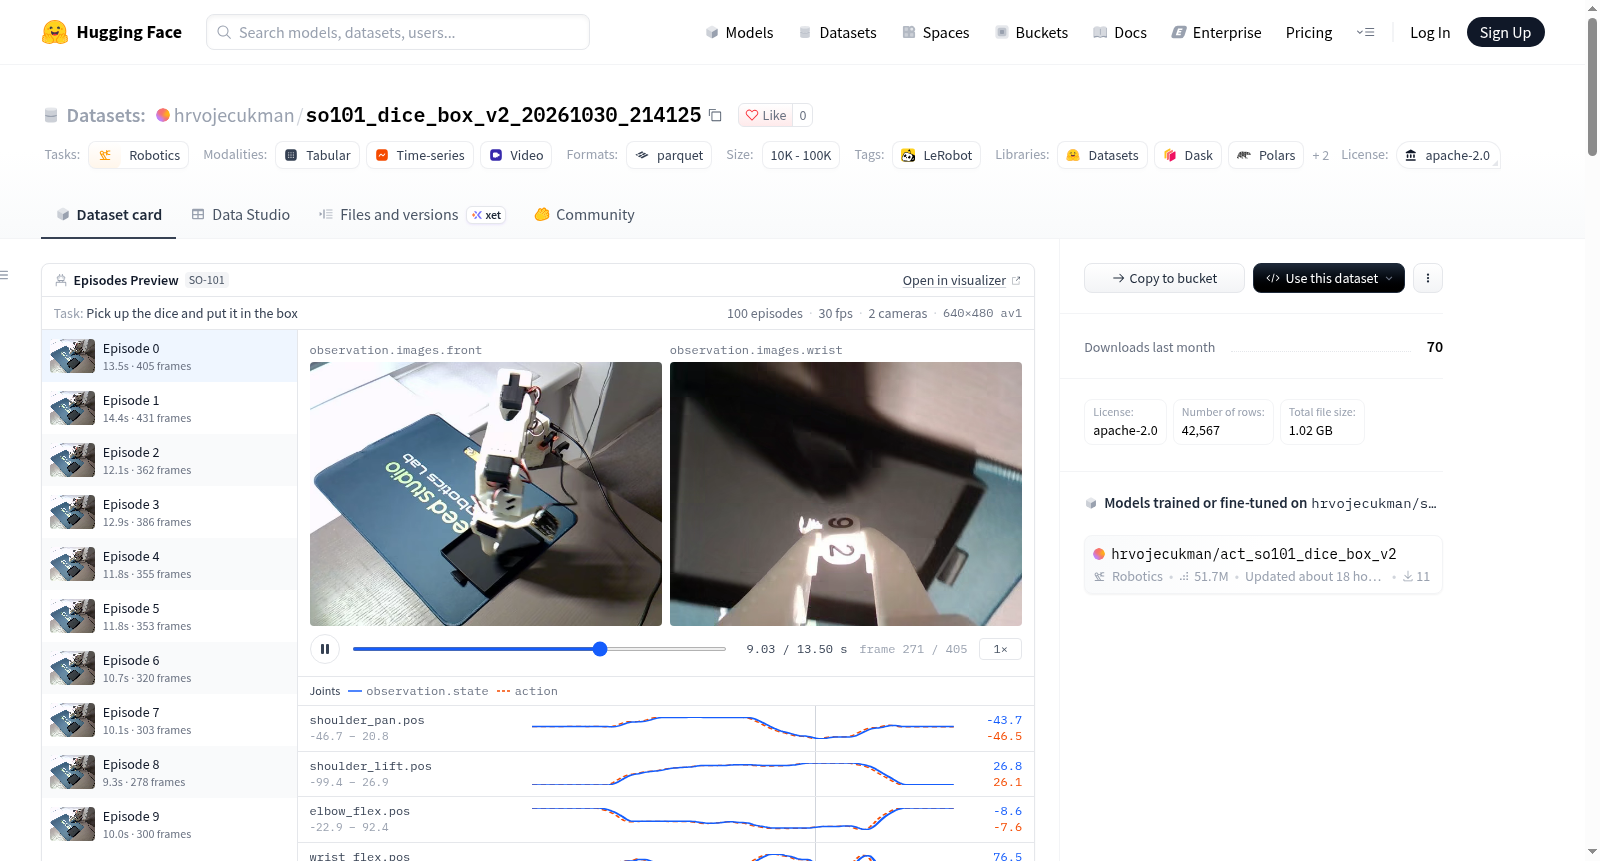
so101_dice_box_v2_20261030_214125
收藏资源简介:
该数据集是由 LeRobot 创建的机器人数据集,许可证为 Apache-2.0,任务类别标注为 robotics,并带有 LeRobot 标签。数据以 HuggingFace 数据集配置 default 提供,数据文件组织为 data/*/*.parquet。根据 meta/info.json,数据集采用 codebase_version v3.0,帧率为 30 fps,机器人类型为 so_follower。数据规模包含 70 个 episode、29,457 帧和 1 个 task,训练集划分为 0:70。特征包括动作 action 和观测状态 observation.state,二者均为 6 维 float32 向量,维度名对应 shoulder_pan.pos、shoulder_lift.pos、elbow_flex.pos、wrist_flex.pos、wrist_roll.pos、gripper.pos;还包括两个视频观测 observation.images.front 和 observation.images.wrist,分辨率 480x640、3 通道,AV1 编码,yuv420p 像素格式,30 fps,无音频。此外包含 timestamp、frame_index、episode_index、index、task_index 等索引与时间字段。数据和视频分别按 data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet 与 videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4 路径组织。README 未提供 homepage、paper 或引用信息,也未给出具体操作任务的文字说明;该数据集适用于机器人相关任务,并可通过 LeRobot 生态进行使用和可视化。
This dataset is a robotics dataset created by LeRobot, licensed under Apache-2.0, with the task category labeled as robotics and tagged with LeRobot. It is provided as a HuggingFace dataset configuration named default, with data files organized as data/*/*.parquet. According to meta/info.json, the dataset uses codebase_version v3.0, has a frame rate of 30 fps, and the robot type is so_follower. The dataset contains 70 episodes, 29,457 frames, and 1 task, with the training split as 0:70. Features include action and observation.state, both 6-dimensional float32 vectors, with dimension names corresponding to shoulder_pan.pos, shoulder_lift.pos, elbow_flex.pos, wrist_flex.pos, wrist_roll.pos, and gripper.pos; it also includes two video observations, observation.images.front and observation.images.wrist, with resolution 480x640, 3 channels, AV1 encoding, yuv420p pixel format, 30 fps, and no audio. It further includes index and time fields such as timestamp, frame_index, episode_index, index, and task_index. Data and videos are organized under paths data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet and videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4, respectively. The README does not provide a homepage, paper, or citation information, nor does it give textual descriptions of specific manipulation tasks; the dataset is suitable for robotics-related tasks and can be used and visualized through the LeRobot ecosystem.
数据集概述
- 数据集名称:
hrvojecukman/so101_dice_box_v2_20261030_214125 - 数据集页面:https://huggingface.co/datasets/hrvojecukman/so101_dice_box_v2_20261030_214125
- 许可证:apache-2.0
- 任务类别:robotics
- 标签:LeRobot
- 创建工具:LeRobot,https://github.com/huggingface/lerobot
- 可视化入口:https://huggingface.co/spaces/lerobot/visualize_dataset?path=hrvojecukman/so101_dice_box_v2_20261030_214125
- 配置名称:default
- 数据文件匹配模式:
data/*/*.parquet
数据集描述
- Homepage:More Information Needed
- Paper:More Information Needed
- License:apache-2.0
- Citation BibTeX:More Information Needed
数据集结构
- 元数据文件:https://huggingface.co/datasets/hrvojecukman/so101_dice_box_v2_20261030_214125/meta/info.json
- codebase_version:v3.0
- fps:30
- total_episodes:100
- total_frames:42567
- total_tasks:1
- chunks_size:1000
- data_files_size_in_mb:100
- video_files_size_in_mb:200
- data_path:
data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet - video_path:
videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4 - robot_type:so_follower
- splits:train:0:100
特征定义
| 特征 | dtype | shape | names / info |
|---|---|---|---|
| action | float32 | [6] | shoulder_pan.pos、shoulder_lift.pos、elbow_flex.pos、wrist_flex.pos、wrist_roll.pos、gripper.pos |
| observation.state | float32 | [6] | shoulder_pan.pos、shoulder_lift.pos、elbow_flex.pos、wrist_flex.pos、wrist_roll.pos、gripper.pos |
| observation.images.front | video | [480, 640, 3] | names:height、width、channels;info:is_depth_map=false,video.height=480,video.width=640,video.codec=av1,video.pix_fmt=yuv420p,video.fps=30,video.channels=3,has_audio=false,video.g=2,video.crf=30,video.preset=12,video.fast_decode=0,video.video_backend=pyav,video.extra_options={} |
| observation.images.wrist | video | [480, 640, 3] | names:height、width、channels;info:is_depth_map=false,video.height=480,video.width=640,video.codec=av1,video.pix_fmt=yuv420p,video.fps=30,video.channels=3,has_audio=false,video.g=2,video.crf=30,video.preset=12,video.fast_decode=0,video.video_backend=pyav,video.extra_options={} |
| timestamp | float32 | [1] | names:null |
| frame_index | int64 | [1] | names:null |
| episode_index | int64 | [1] | names:null |
| index | int64 | [1] | names:null |
| task_index | int64 | [1] | names:null |
引用
- BibTeX:More Information Needed