SP_Relational_Placement
收藏资源简介:
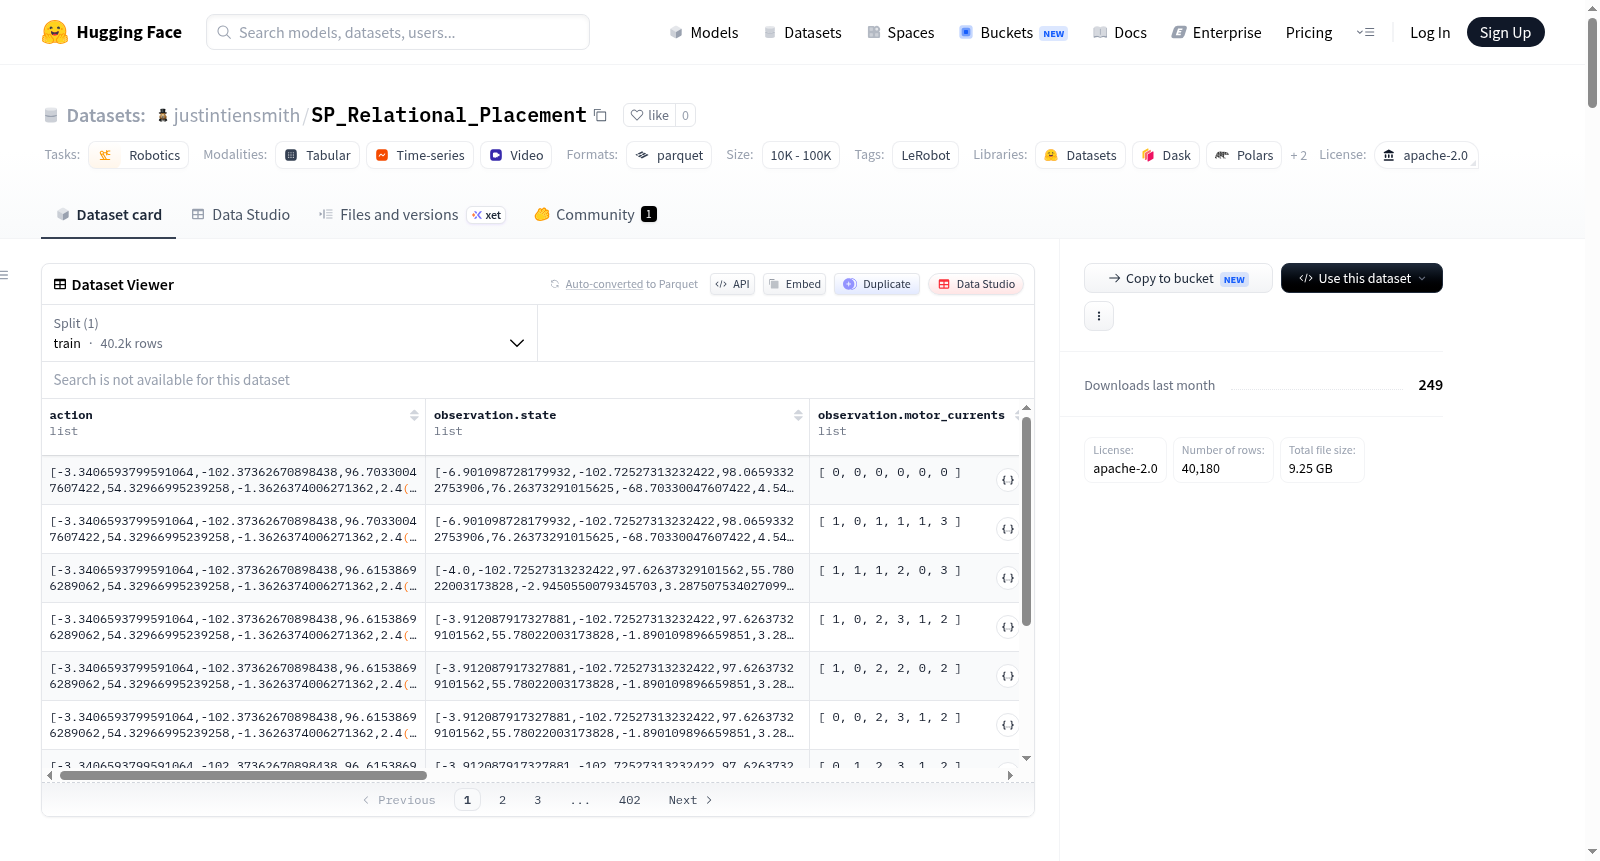
该数据集是一个机器人操作数据集,使用LeRobot工具创建,专注于机器人执行物体操作任务,例如“将粉色标记物放置到绿色方块的后方”。数据集包含51个任务片段(episodes),总计40,180帧数据,涵盖9种不同任务。数据以Parquet文件格式存储,总数据量约100 MB,同时包含约200 MB的配套视频文件,视频帧率为30 FPS。数据集结构包括丰富的多模态观测和机器人控制指令:观测部分有机器人状态(6维关节位置,包括肩部平移、肩部抬升、肘部弯曲、腕部弯曲、腕部旋转、夹爪位置)、多视角视觉输入(来自腕部、中部、上方、右侧和左侧五个固定摄像头的RGB视频流,每个视频分辨率为480x640)、传感器数据(6维电机电流和速度读数,以及精确时间戳)、深度信息(来自中部摄像头的480x640深度图);动作空间由与观测状态同构的6维关节位置指令构成。此外,数据还包含时间戳、帧索引、片段索引和任务索引等元数据字段。该数据集适用于机器人学习领域的研究,特别是用于模仿学习、强化学习或行为克隆等算法的训练与评估,旨在让机器人学习复杂的多步骤操作技能,所有数据均被划分为训练集。
This dataset is a robot manipulation dataset created using the LeRobot tool, focusing on robot execution of object manipulation tasks, such as placing the pink marker behind the green block. It contains 51 task episodes, totaling 40,180 frames of data, covering 9 different tasks. The data is stored in Parquet format with a total size of approximately 100 MB, along with about 200 MB of accompanying video files at a frame rate of 30 FPS. The dataset structure includes rich multimodal observations and robot control commands: observations consist of robot state (6-dimensional joint positions, including shoulder translation, shoulder lift, elbow bend, wrist bend, wrist rotation, and gripper position), multi-view visual inputs (RGB video streams from five fixed cameras: wrist, middle, top, right, and left, each with a resolution of 480x640), sensor data (6-dimensional motor current and speed readings, along with precise timestamps), and depth information (480x640 depth maps from the middle camera). The action space is composed of 6-dimensional joint position commands isomorphic to the observation state. Additionally, the data includes metadata fields such as timestamps, frame indices, episode indices, and task indices. This dataset is suitable for research in robot learning, particularly for training and evaluating algorithms like imitation learning, reinforcement learning, or behavior cloning, aiming to enable robots to learn complex multi-step manipulation skills, with all data partitioned into a training set.
数据集概述:SP_Relational_Placement
- 数据集地址: https://huggingface.co/datasets/justintiensmith/SP_Relational_Placement
- 许可证: Apache-2.0
- 任务类别: 机器人学(robotics)
- 创建工具: 使用 LeRobot 创建
- 备注: 第40个片段是“将粉色标记放到绿色积木的后面”的重复数据。
数据集规模与结构
| 属性 | 值 |
|---|---|
| 总片段数 | 51 |
| 总帧数 | 40,180 |
| 总任务数 | 9 |
| 分块大小 | 1,000 |
| 数据文件大小 | 100 MB |
| 视频文件大小 | 200 MB |
| 帧率(FPS) | 30 |
| 训练集划分 | 全部51个片段用于训练 |
机器人信息
- 机器人类型:
so_follower
数据特征
| 特征名称 | 数据类型 | 形状 | 说明 |
|---|---|---|---|
action |
float32 | (6,) | 6维动作指令:shoulder_pan/shoulder_lift/elbow_flex/wrist_flex/wrist_roll/gripper 位置 |
observation.state |
float32 | (6,) | 机器人6个关节的状态位置,名称与action相同 |
observation.images.wrist |
video | (480, 640, 3) | 腕部摄像头,H264编码,30fps,无深度,无音频 |
observation.images.middle |
video | (480, 640, 3) | 中部摄像头,参数同wrist |
observation.images.above |
video | (480, 640, 3) | 上方摄像头,参数同wrist |
observation.images.right |
video | (480, 640, 3) | 右侧摄像头,参数同wrist |
observation.images.left |
video | (480, 640, 3) | 左侧摄像头,参数同wrist |
observation.motor_currents |
int32 | (6,) | 6个关节的电机电流 |
observation.motor_velocities |
int32 | (6,) | 6个关节的电机速度 |
observation.sensor_timestamps |
float64 | (8,) | 8个传感器时间戳:电机位置、电流、速度及5个摄像头 |
observation.depths.middle |
uint16 | (480, 640) | 中部深度图(高度×宽度) |
timestamp |
float32 | (1,) | 时间戳 |
frame_index |
int64 | (1,) | 帧索引 |
episode_index |
int64 | (1,) | 片段索引 |
index |
int64 | (1,) | 全局索引 |
task_index |
int64 | (1,) | 任务索引 |
数据存储路径
- 数据文件:
data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet - 视频文件:
videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4
主页与论文
- 主页: 暂无信息
- 论文: 暂无信息