BitRobot/G1_WBT_Dex1_Building-Children-Table
收藏资源简介:
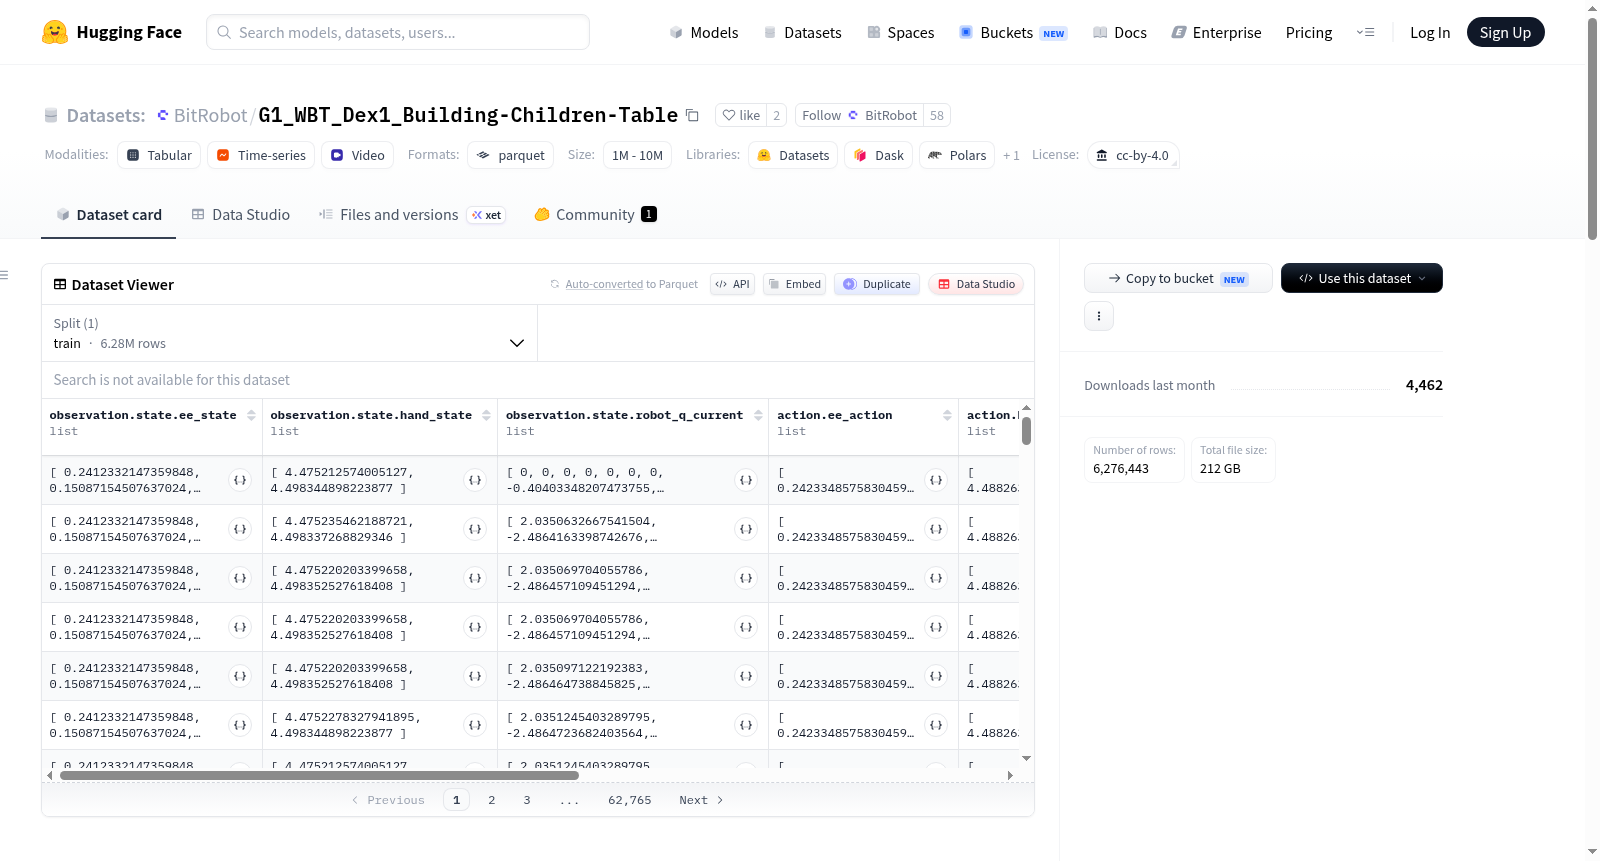
该数据集包含机器人操作任务中的观察和动作数据,用于机器人学习和控制。观察数据包括末端执行器状态(基于正向运动学计算,包含左右末端执行器的位姿)、手部状态(Dex1手的手指开合状态,范围从5.5到0.0,表示从打开到关闭)以及机器人当前配置(根位置、根方向和关节位置)。动作数据包括目标末端执行器状态、手部命令(控制手指动作)和机器人期望配置(目标根位置、根方向和关节位置)。数据集使用LeRobot框架创建,适用于机器人模拟和强化学习任务。
This dataset contains observation and action data for robot manipulation tasks, designed for robot learning and control. Observations include end-effector states (computed via forward kinematics, representing poses of both end-effectors), hand states (finger open/close states for Dex1 hands, with a range from 5.5 to 0.0 indicating open to close), and current robot configuration (root position, root orientation, and joint positions). Actions include target end-effector states, hand commands (for finger actions), and desired robot configuration (target root position, orientation, and joint positions). The dataset was created using the LeRobot framework and is suitable for robot simulation and reinforcement learning applications.