
ReplicaMultiagent Plus
收藏资源简介:
ReplicaMultiagent Plus是由多机构合作构建的用于评估协同高斯SLAM性能的基准数据集。该数据集规模扩展至包含4个智能体的长轨迹序列,并提供了精确的地面真实几何结构与语义标注,支持单目、RGB-D及语义多智能体SLAM的密集重建评估。数据通过合成与真实场景采集,旨在解决现有多智能体数据集中智能体数量有限、轨迹较短的问题,为协作式场景重建算法的几何一致性、光度一致性与语义理解提供全面验证平台。
ReplicaMultiagent Plus is a benchmark dataset developed through multi-institutional collaborative efforts for evaluating the performance of collaborative Gaussian SLAM. This dataset has been scaled to include long trajectory sequences involving 4 agents, and provides precise ground-truth geometric structures and semantic annotations. It supports dense reconstruction evaluation for monocular, RGB-D, and semantic multi-agent SLAM systems. The dataset is collected from both synthetic and real-world scenarios, aiming to address the limitations of existing multi-agent datasets, which typically feature a limited number of agents and short trajectory lengths. It provides a comprehensive validation platform for geometric consistency, photometric consistency, and semantic understanding of collaborative scene reconstruction algorithms.
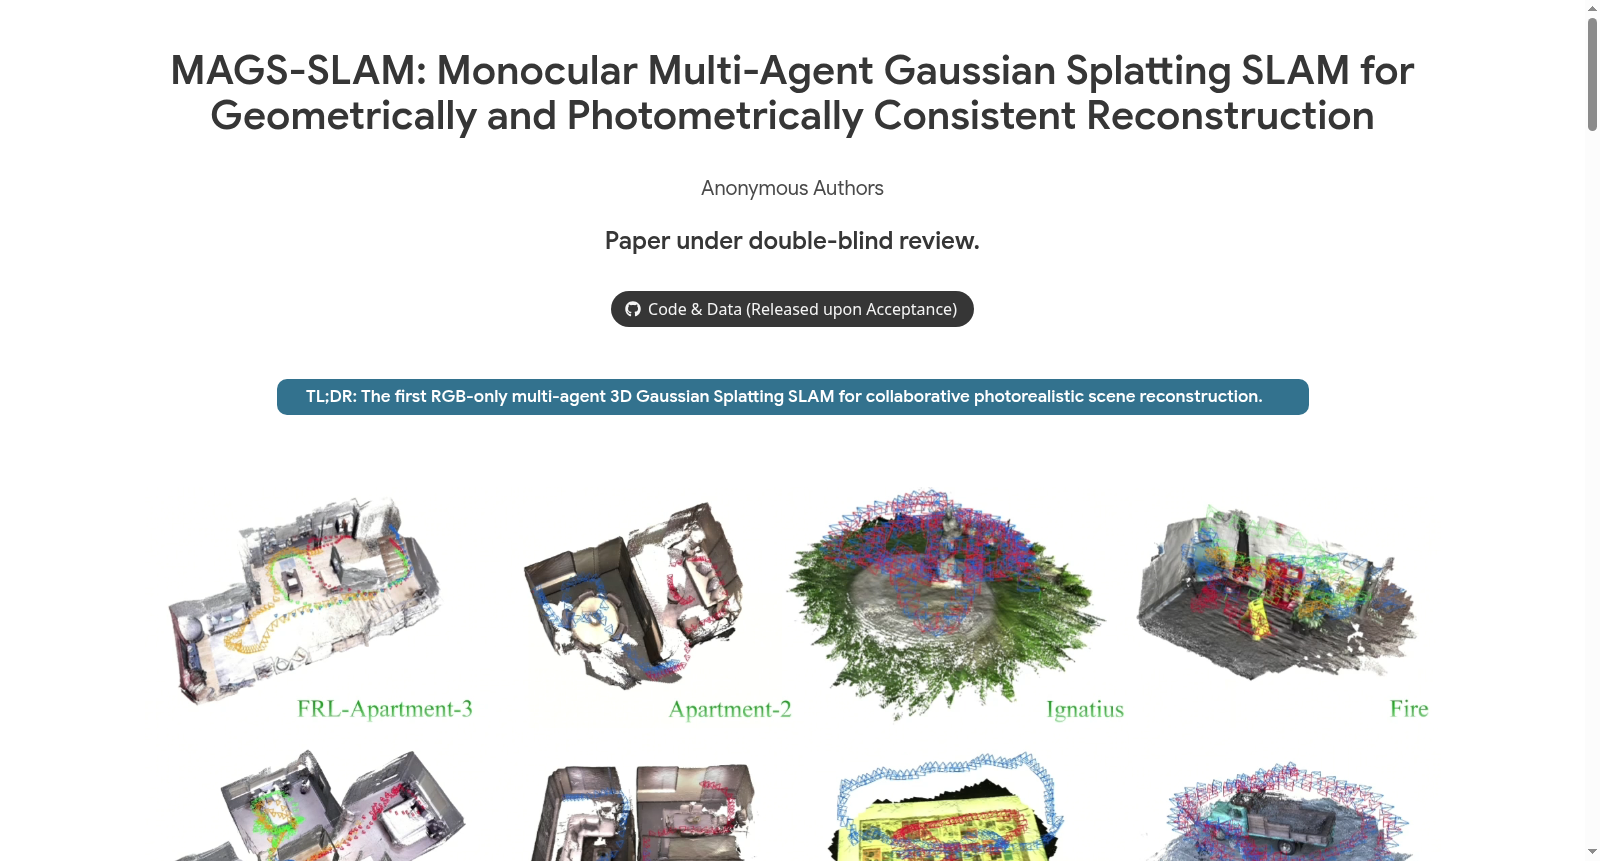
- 1MAGS-SLAM: Monocular Multi-Agent Gaussian Splatting SLAM for Geometrically and Photometrically Consistent Reconstruction苏黎世联邦理工学院; 哈尔滨工程大学; 利物浦大学; 澳门大学; 渥太华大学; 武汉大学; 帝国理工学院 · 2026年


