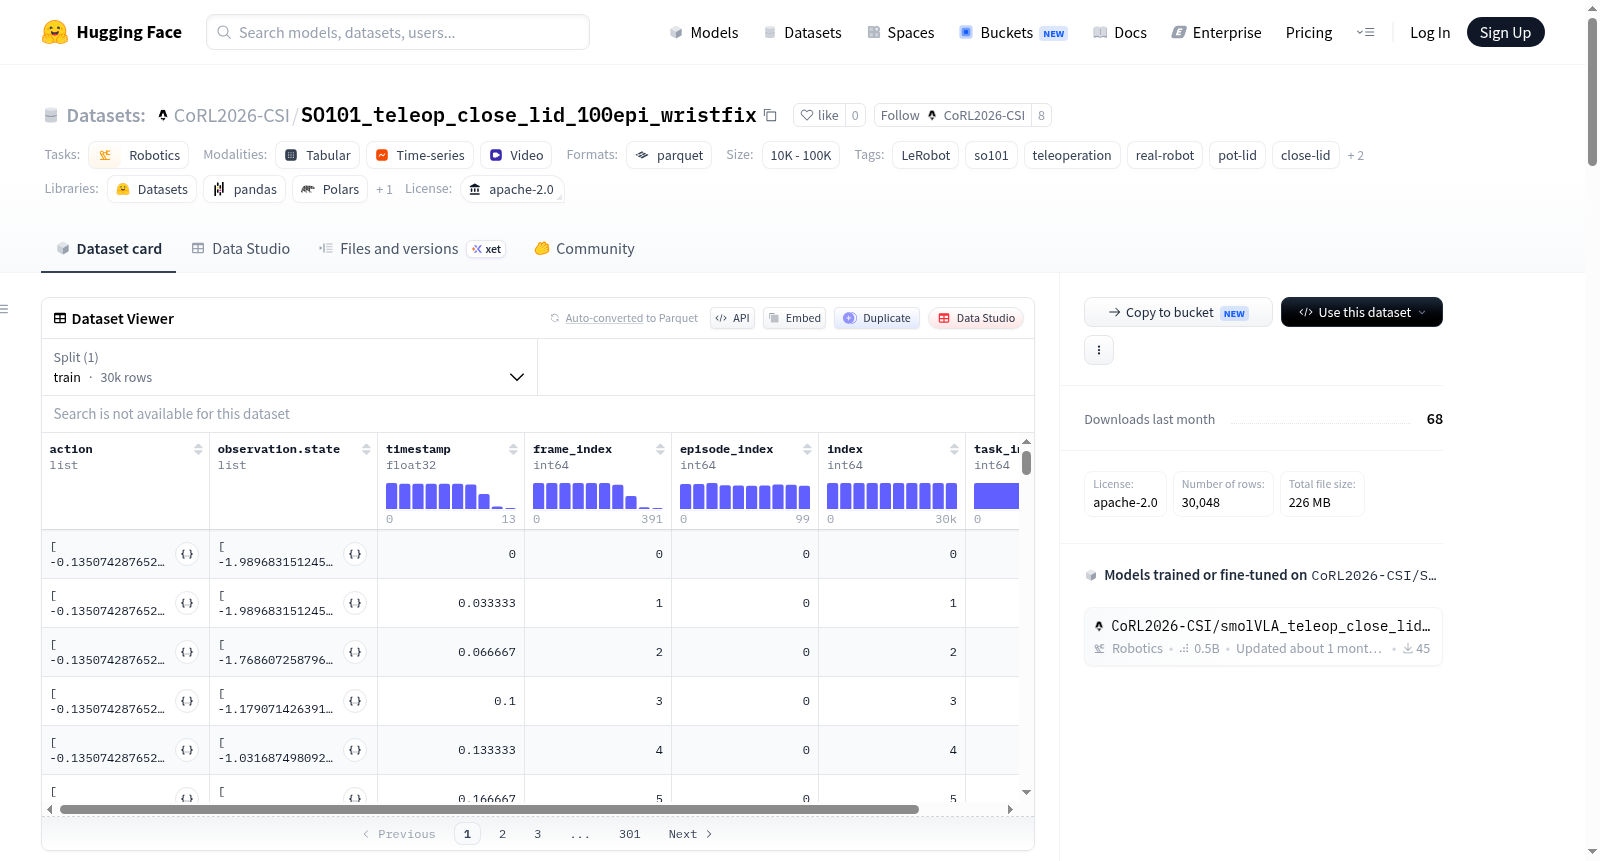
CoRL2026-CSI/SO101_teleop_close_lid_100epi_wristfix
收藏资源简介:
该数据集是一个机器人操作数据集,专注于通过遥操作执行关闭锅盖的任务。它使用真实机器人(类型为so_follower)收集,包含100个情节和30048帧数据。数据集采用手腕固定(wristfix)配置,动作和观察状态包括6个关节位置(肩部平移、肩部提升、肘部弯曲、手腕弯曲、手腕旋转、夹爪位置)。观察数据包括来自左腕摄像头和顶视角摄像头的视频,分辨率为480x640,帧率为30fps,使用h264编解码器。数据格式为Parquet文件,视频为MP4文件,适用于机器人学习和控制研究。
This dataset is a robotics manipulation dataset focused on teleoperation for closing a pot lid. It was collected using a real robot (type: so_follower) and consists of 100 episodes with 30048 frames. The dataset employs a wristfix configuration, with actions and observation states including 6 joint positions (shoulder pan, shoulder lift, elbow flex, wrist flex, wrist roll, gripper). Observations include video from left wrist and top-view cameras at 480x640 resolution, 30fps, using h264 codec. Data is stored in Parquet files and videos in MP4 format, suitable for robot learning and control research.