USC Cloth Sim
收藏资源简介:
USC Cloth Sim 是由南加州大学(University of Southern California)创建的可变形物体操作数据集,专注于布料折叠等任务。该数据集包含多个任务的视觉和运动数据,如绳索拉直和布料折叠等,涵盖了多样化的操作场景和任务类型。数据集的创建过程涉及在模拟环境中部署机器人,通过专家示范和行为克隆策略收集数据。这些数据包括 RGB 图像、机器人本体感觉状态以及动作信息,旨在为机器人学习提供丰富的经验。
USC Cloth Sim is a deformable object manipulation dataset created by the University of Southern California, focusing on tasks such as cloth folding. This dataset contains visual and motion data for multiple tasks including rope straightening and cloth folding, covering diverse manipulation scenarios and task types. The dataset development process involves deploying robots in a simulated environment and collecting data via expert demonstrations and behavior cloning strategies. The collected data includes RGB images, robot proprioceptive states, and action information, aiming to provide rich empirical resources for robot learning.
数据集概述
数据集名称
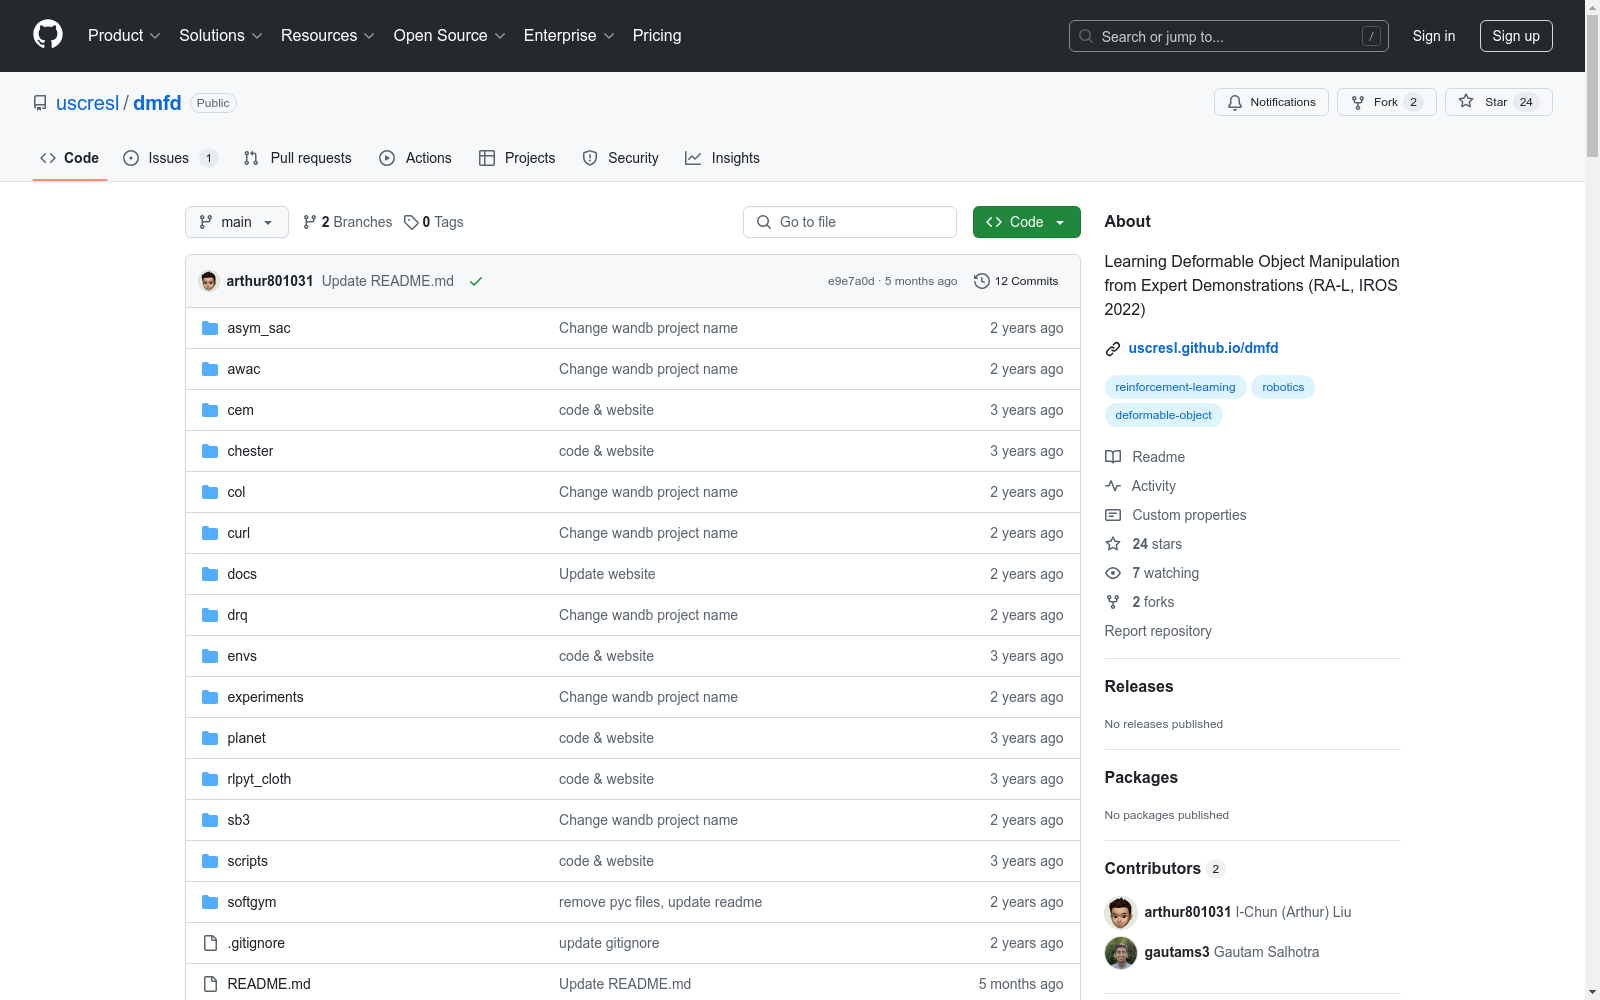
Learning Deformable Object Manipulation from Expert Demonstrations (DMfD)
数据集简介
该数据集是用于学习可变形物体操作的专家演示数据,基于PyTorch实现,相关研究发表于IEEE RA-L和IEEE IROS 2022。数据集包含多个任务,如拉直绳子、折叠布料等,支持多种实验和基准测试。
数据集内容
- 任务类型:包括拉直绳子(Straighten Rope)、折叠布料(ClothFold)、对角固定布料折叠(ClothFoldDiagonalPinned)、对角非固定布料折叠(ClothFoldDiagonalUnpinned)等任务。
- 数据格式:数据集包含专家演示的轨迹数据,支持基于状态和基于图像的实验。
- 下载内容:
cached_initial_states:初始状态缓存数据。checkpoints:用于复现实验结果的模型检查点。
数据集使用
- 环境安装:需通过Conda创建Python 3.7环境,并安装必要的依赖包。支持Docker环境下的PyFlex安装。
- 实验复现:提供了详细的训练和评估脚本,支持多种基准实验(如DMfD、SAC、AWAC、BC等)。
- 专家演示生成:提供了生成专家演示数据的脚本,支持不同任务的演示数据生成。
引用
如果使用该数据集,请引用以下文献: bibtex @article{salhotra2022dmfd, author={Salhotra, Gautam and Liu, I-Chun Arthur and Dominguez-Kuhne, Marcus and Sukhatme, Gaurav S.}, journal={IEEE Robotics and Automation Letters}, title={Learning Deformable Object Manipulation From Expert Demonstrations}, year={2022}, volume={7}, number={4}, pages={8775-8782}, doi={10.1109/LRA.2022.3187843} }
相关链接