jedai2003/record-pickup_bottle
收藏资源简介:
--- license: apache-2.0 task_categories: - robotics tags: - LeRobot configs: - config_name: default data_files: data/*/*.parquet --- This dataset was created using [LeRobot](https://github.com/huggingface/lerobot). ## Dataset Description - **Homepage:** [More Information Needed] - **Paper:** [More Information Needed] - **License:** apache-2.0 ## Dataset Structure [meta/info.json](meta/info.json): ```json { "codebase_version": "v3.0", "robot_type": "so100_follower", "total_episodes": 50, "total_frames": 19526, "total_tasks": 1, "chunks_size": 1000, "data_files_size_in_mb": 100, "video_files_size_in_mb": 500, "fps": 30, "splits": { "train": "0:50" }, "data_path": "data/chunk-{chunk_index:03d}/file-{file_index:03d}.parquet", "video_path": "videos/{video_key}/chunk-{chunk_index:03d}/file-{file_index:03d}.mp4", "features": { "action": { "dtype": "float32", "names": [ "shoulder_pan.pos", "shoulder_lift.pos", "elbow_flex.pos", "wrist_flex.pos", "wrist_roll.pos", "gripper.pos" ], "shape": [ 6 ] }, "observation.state": { "dtype": "float32", "names": [ "shoulder_pan.pos", "shoulder_lift.pos", "elbow_flex.pos", "wrist_flex.pos", "wrist_roll.pos", "gripper.pos" ], "shape": [ 6 ] }, "observation.images.front": { "dtype": "video", "shape": [ 480, 640, 3 ], "names": [ "height", "width", "channels" ], "info": { "video.height": 480, "video.width": 640, "video.codec": "av1", "video.pix_fmt": "yuv420p", "video.is_depth_map": false, "video.fps": 30, "video.channels": 3, "has_audio": false } }, "timestamp": { "dtype": "float32", "shape": [ 1 ], "names": null }, "frame_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "episode_index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "index": { "dtype": "int64", "shape": [ 1 ], "names": null }, "task_index": { "dtype": "int64", "shape": [ 1 ], "names": null } } } ``` ## Citation **BibTeX:** ```bibtex [More Information Needed] ```
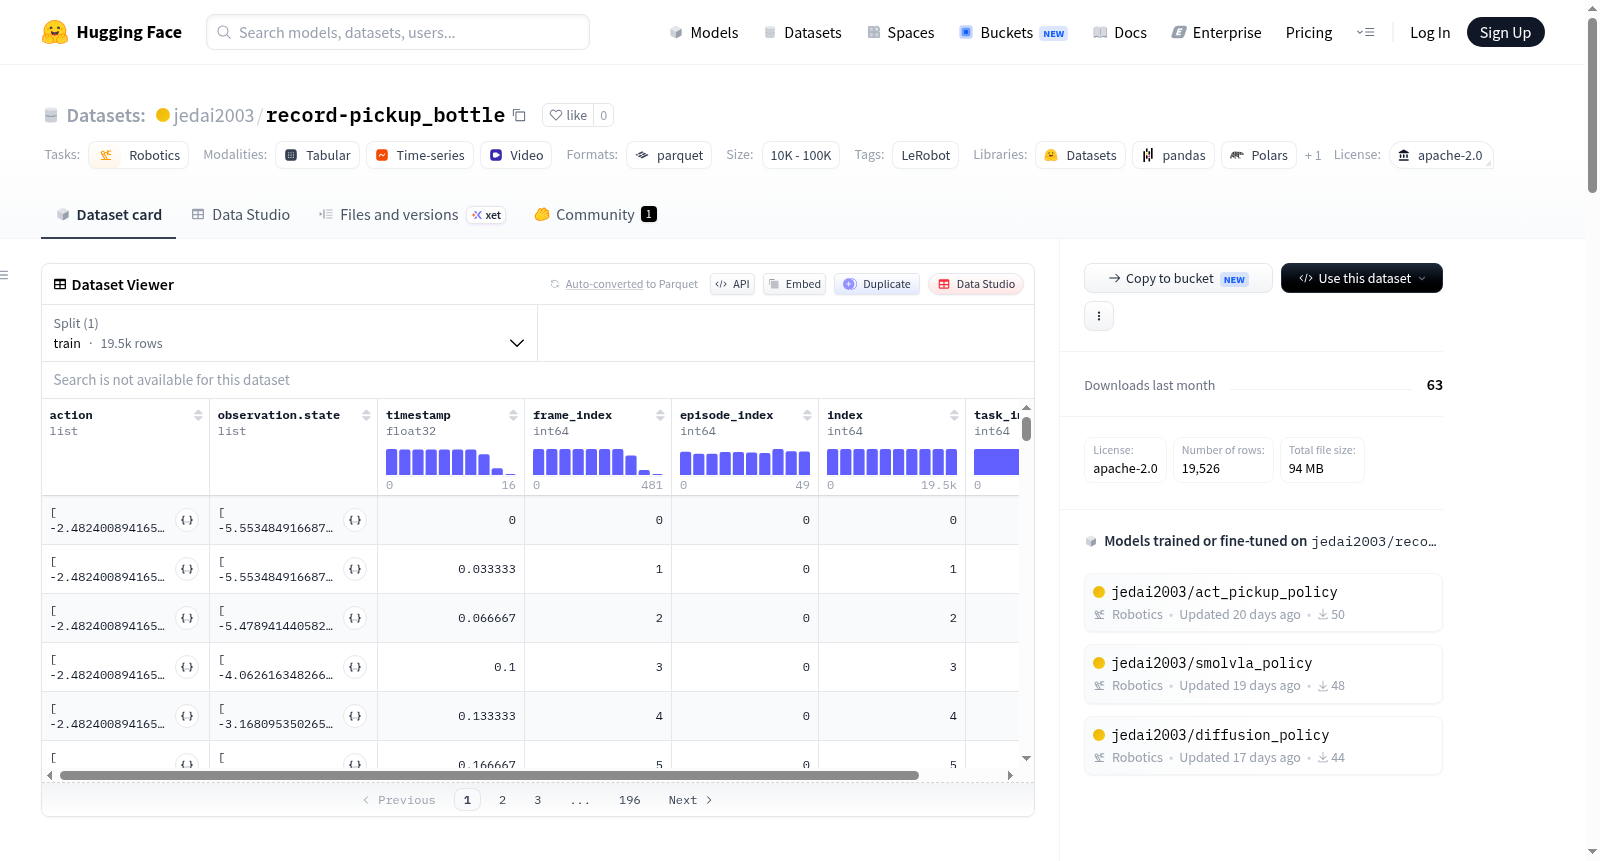
This dataset was created using LeRobot and is primarily used in the field of robotics. The dataset contains 50 episodes, 19526 frames, and 1 task, with data files sized at 100MB and video files at 500MB, running at 30fps. The dataset structure includes multiple features such as actions, observation states, and front images. Both actions and observation states contain 6 joint position information (shoulder_pan.pos, shoulder_lift.pos, elbow_flex.pos, wrist_flex.pos, wrist_roll.pos, gripper.pos). The front images have a resolution of 480x640, 3 channels, with video encoding in av1 and a frame rate of 30fps. Additionally, the dataset includes timestamps, frame indices, episode indices, indices, and task indices.