TrossenRoboticsCommunity/stationary-organize-tools-converted-v3-relative
收藏资源简介:
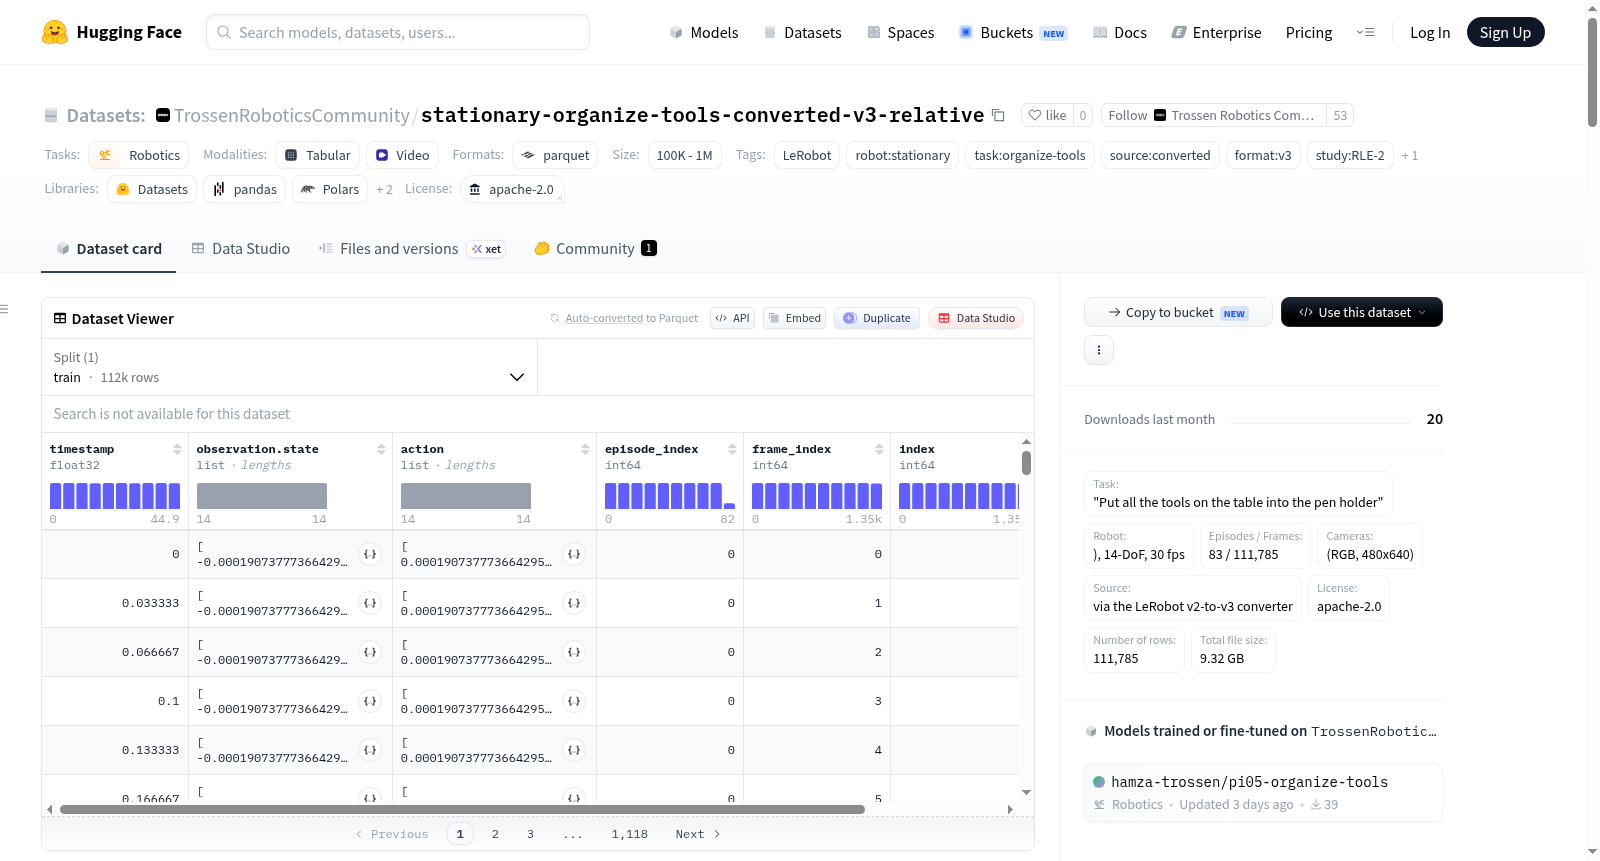
该数据集是使用LeRobot创建的机器人操作数据集,专注于将所有工具放入笔筒的任务。数据集采用Trossen AI双手机器人(bimanual_widowxai,14自由度,30帧/秒)收集,包含83个episodes和111,785帧数据。数据采集使用了四个RGB摄像头:cam_high、cam_low、cam_left_wrist和cam_right_wrist,分辨率均为480x640。该数据集是从v2.1版本的trossen_ai_stationary_organize_tools数据集通过LeRobot v2-to-v3转换器转换而来的相对动作变体,动作归一化统计信息存储在相对空间中(关节动作相对于当前状态,夹爪保持绝对)。数据集遵循Apache-2.0许可证。
This dataset was created using LeRobot. Task: Put all the tools on the table into the pen holder. Robot: Trossen AI bimanual stationary (bimanual_widowxai), 14-DoF, 30 fps. Episodes / Frames: 83 / 111,785. Cameras: cam_high, cam_low, cam_left_wrist, cam_right_wrist (RGB, 480x640). Source: converted from the v2.1 dataset `trossen_ai_stationary_organize_tools` via the LeRobot v2-to-v3 converter. License: apache-2.0. Relative-action variant: Action normalization statistics are stored in relative space (arm joints relative to the current state; grippers kept absolute).