rishgang22/single_lego_pick_place_combined
收藏资源简介:
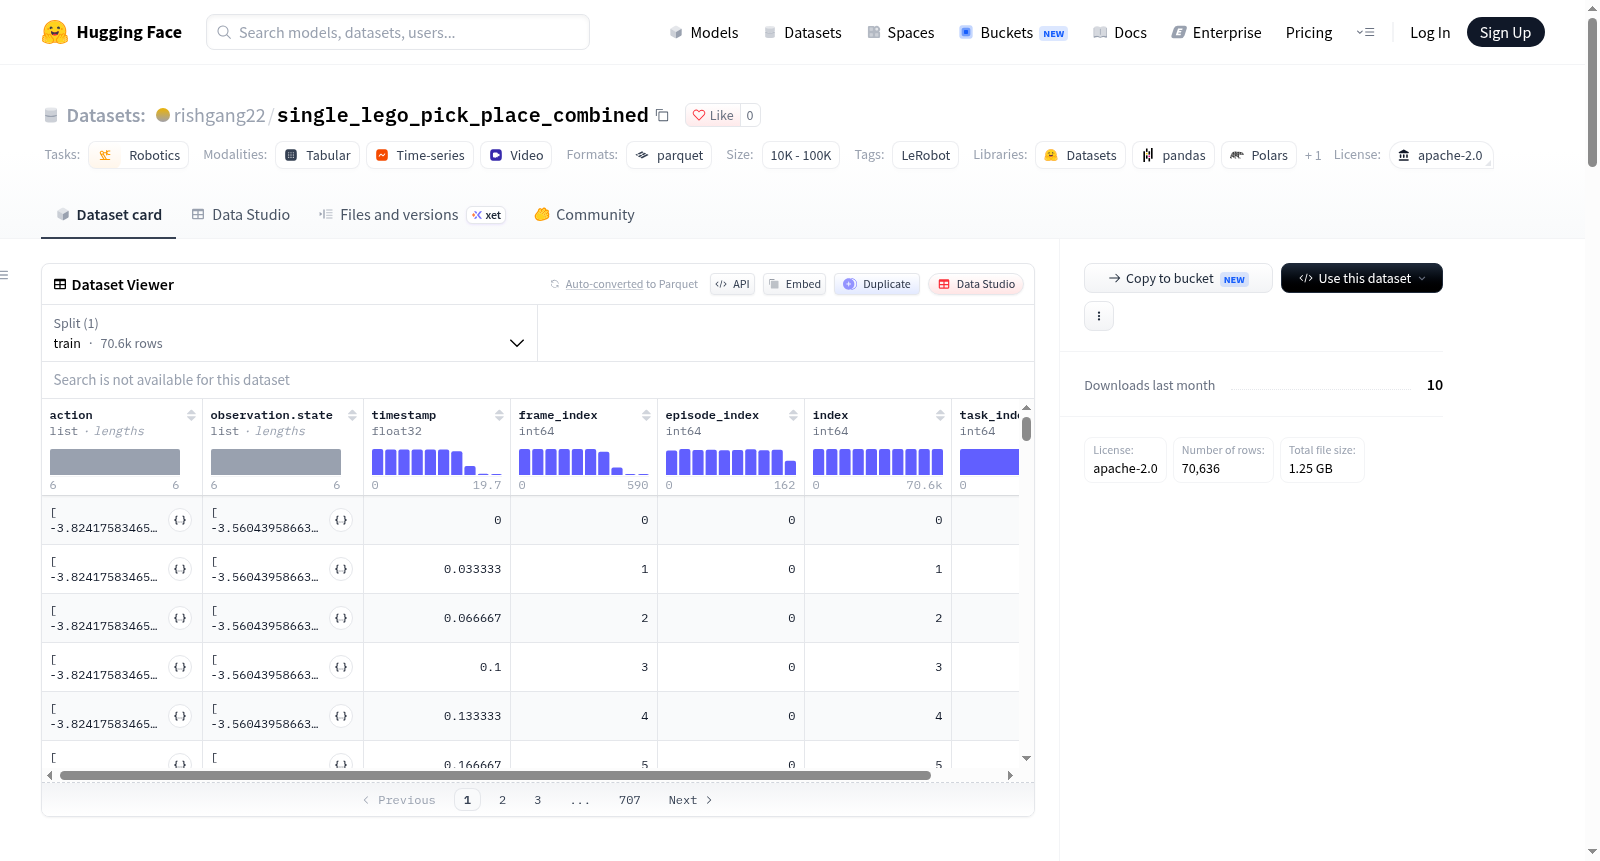
该数据集是使用LeRobot创建的机器人操作数据集,专门用于单乐高块的抓取和放置任务。数据集包含163个episodes,总计70636帧,帧率为30fps。数据特征包括动作(6个浮点数,对应机器人关节位置)、观测状态(6个浮点数,同样对应关节位置)、观测图像(顶部和腕部摄像头视频,分辨率480x640,3通道,视频编码为av1,格式为yuv420p)、时间戳、帧索引、episode索引、索引和任务索引。数据集以parquet文件格式存储,视频文件为mp4格式,总数据大小为100MB,视频大小为200MB。机器人类型为so_follower,所有数据均用于训练集。
This is a robotic manipulation dataset developed using LeRobot, specifically designed for single Lego block grasping and placement tasks. The dataset contains 163 episodes, totaling 70636 frames with a frame rate of 30fps. The data features include actions (6 floating-point numbers corresponding to robot joint positions), observation states (6 floating-point numbers, also corresponding to joint positions), observation images (videos captured by top and wrist cameras, with a resolution of 480x640, 3 channels, encoded in av1 format with yuv420p pixel format), timestamps, frame indices, episode indices, global indices, and task indices. The dataset is stored in parquet file format, while the video files are in mp4 format. The total size of the non-video data is 100 MB, and the total size of the video files is 200 MB. The robot type used is so_follower, and all the data is allocated to the training set.