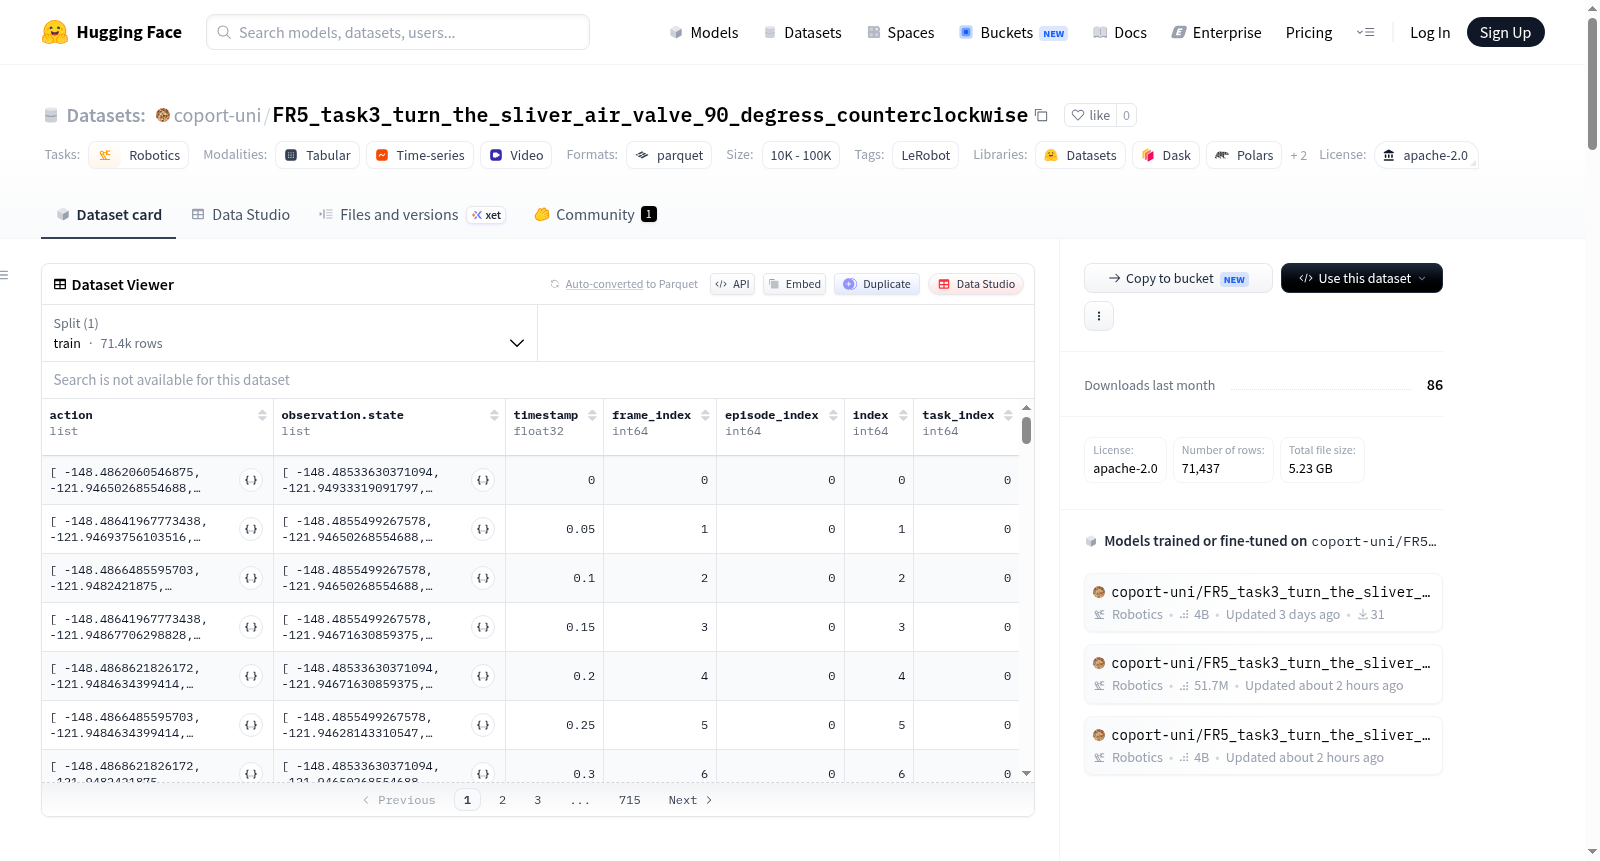
FR5_task3_turn_the_sliver_air_valve_90_degress_counterclockwise
收藏资源简介:
该数据集是一个用于机器人学习的多模态数据集,使用LeRobot工具创建。具体任务为FR5_task3_turn_the_silver_air_valve_90_degress_counterclockwise(将银色气阀逆时针旋转90度)。数据集规模包括100个完整回合(episodes),共计71,437帧数据,涉及1个任务。数据以分块形式组织,每块包含1000帧,数据文件总大小约100 MB,视频文件总大小约200 MB,视频帧率为20 FPS。数据划分为训练集,包含所有100个回合。核心特征字段包括:1) `action`:7维浮点向量,表示机器人动作,对应6个关节位置和1个夹爪位置;2) `observation.state`:7维浮点向量,表示机器人状态观测,内容与`action`相同;3) `observation.images`:包含三个视角的视频观测(左上、右上和手部),每个视频分辨率为640x480,3通道(RGB),使用AV1编码;4) 元数据字段:`timestamp`、`frame_index`、`episode_index`、`index`和`task_index`。该数据集适用于机器人模仿学习、强化学习、行为克隆等任务的研究与模型训练,提供丰富的状态-动作对和多视角视觉观测。数据集采用Apache 2.0许可证。
This is a multimodal dataset for robotic learning, developed using the LeRobot toolkit. The specific task is FR5_task3_turn_the_silver_air_valve_90_degrees_counterclockwise (rotating the silver air valve 90 degrees counterclockwise). The dataset comprises 100 complete episodes, totaling 71,437 frames, and covers a single task. The data is organized in chunks, with each chunk containing 1,000 frames. The total size of the data files is approximately 100 MB, while the total size of the video files is around 200 MB, with a video frame rate of 20 FPS. The dataset is split into a training set that includes all 100 episodes. The core feature fields are as follows: 1) `action`: a 7-dimensional floating-point vector representing the robot's action, which corresponds to 6 joint positions and 1 gripper position; 2) `observation.state`: a 7-dimensional floating-point vector representing the robot's state observation, with content identical to that of `action`; 3) `observation.images`: video observations from three perspectives (top-left, top-right, and hand-mounted camera), each with a resolution of 640×480, 3-channel RGB, encoded using AV1; 4) Metadata fields: `timestamp`, `frame_index`, `episode_index`, `index`, and `task_index`. This dataset is applicable to research and model training for tasks such as robotic imitation learning, reinforcement learning, and behavioral cloning, providing abundant state-action pairs and multi-view visual observations. The dataset is licensed under the Apache 2.0 license.
数据集概述:FR5_task3_turn_the_sliver_air_valve_90_degress_counterclockwise
该数据集旨在为机器人学习任务提供支持,具体任务是控制FR5机械臂将银色的空气阀逆时针旋转90度。
基本信息
- 许可证: Apache-2.0
- 任务类别: 机器人学 (Robotics)
- 标签: LeRobot
- 创建工具: 使用 LeRobot 框架创建。
数据集规模
- 总片段数 (Total Episodes): 100
- 总帧数 (Total Frames): 71,437
- 总任务数 (Total Tasks): 1
- 数据文件大小: 100 MB
- 视频文件大小: 200 MB
- 帧率 (FPS): 20
- 数据分块大小: 1000 帧/块
数据分割
- 训练集 (Train): 包含全部100个片段(索引0至99)。
数据结构与特征
数据通过 Parquet 文件和 MP4 视频文件存储,主要包含以下特征:
| 特征名称 | 数据类型 | 形状/描述 |
|---|---|---|
action |
float32 | 机器人动作指令,包含7个关节位置(joint1.pos ~ joint6.pos)和夹爪位置(gripper.pos),形状为 [7]。 |
observation.state |
float32 | 机器人观测到的状态,与action维度相同(7个关节位置和夹爪位置),形状为 [7]。 |
observation.images.top_left |
video | 左上角摄像头图像,尺寸为 480x640 像素,3通道,AV1编码,20 FPS。 |
observation.images.top_right |
video | 右上角摄像头图像,尺寸为 480x640 像素,3通道,AV1编码,20 FPS。 |
observation.images.hand |
video | 手部摄像头图像,尺寸为 480x640 像素,3通道,AV1编码,20 FPS。 |
timestamp |
float32 | 时间戳,形状为 [1]。 |
frame_index |
int64 | 帧索引,形状为 [1]。 |
episode_index |
int64 | 片段索引,形状为 [1]。 |
index |
int64 | 全局索引,形状为 [1]。 |
task_index |
int64 | 任务索引,形状为 [1]。 |
机器人信息
- 机器人类型 (Robot Type): fairino_follower
可视化
该数据集可通过 LeRobot 可视化页面 进行预览。