KS325/open-upper-drawer-r2-emp-test-spare
收藏资源简介:
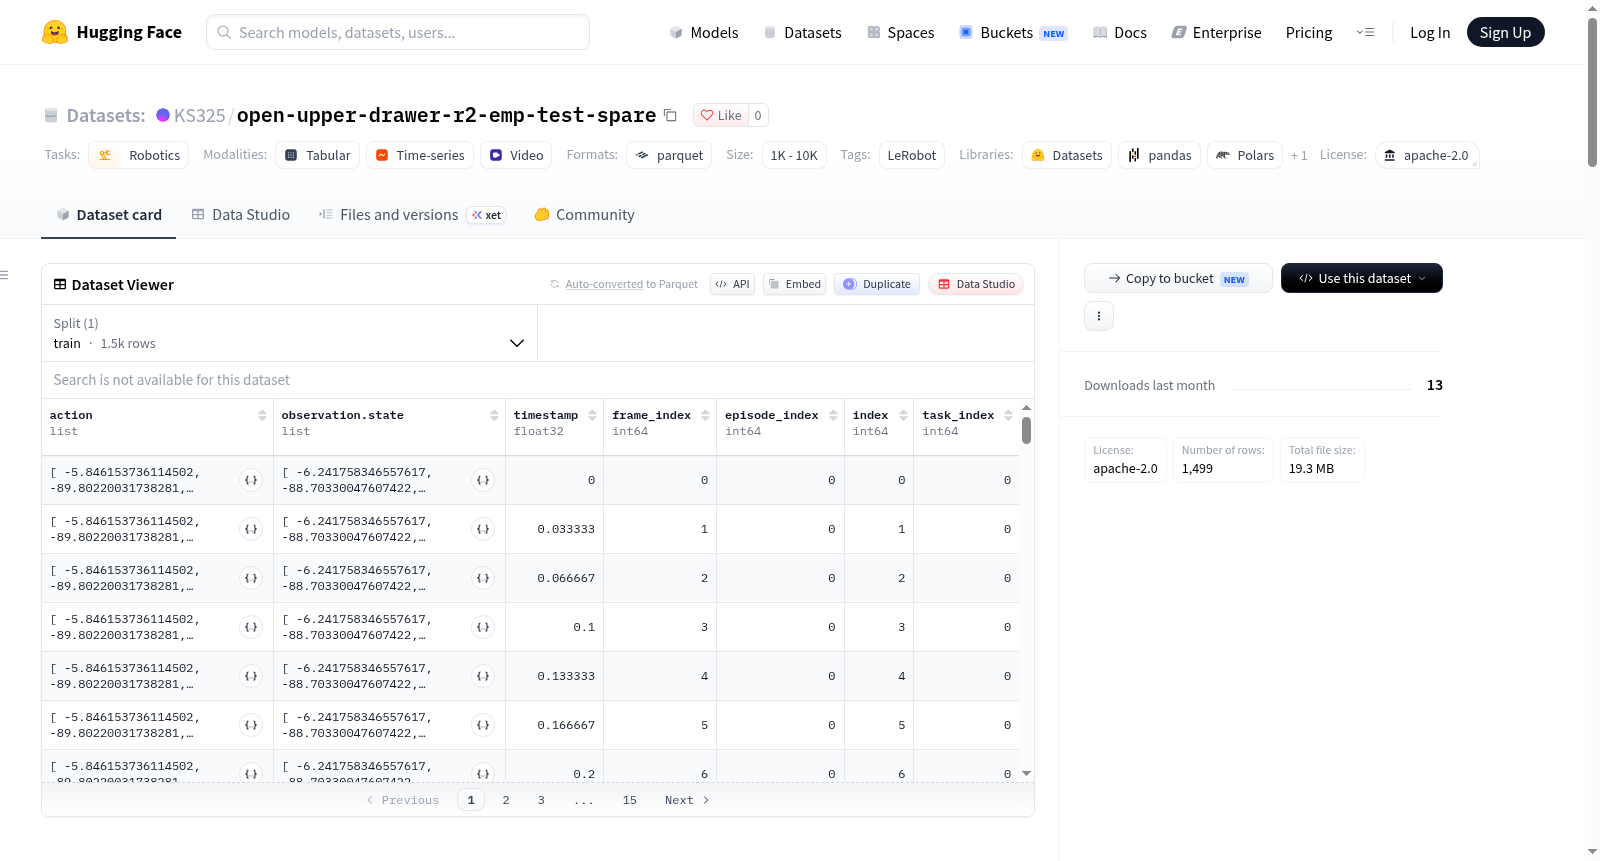
该数据集使用LeRobot工具创建,专注于机器人技术领域,具体涉及so_follower机器人类型。数据集包含2个总集数、1499个总帧数,数据以parquet格式存储,视频以mp4格式存储。特征包括动作(6维浮点数组,对应机器人关节位置)、观测状态(6维浮点数组,与动作相同)、两个摄像头图像(分辨率480x640,3通道,30fps视频)、时间戳、帧索引、集索引、索引和任务索引等。数据集用于机器人控制或模仿学习任务,支持训练和测试。
This dataset was developed using the LeRobot toolkit, focusing on the field of robotics and specifically targeting the so_follower robot type. It contains 2 total episodes and 1499 total frames. The feature data is stored in Parquet format, while the video data is saved in MP4 format. Its features include 6-dimensional floating-point action arrays (corresponding to robot joint positions), 6-dimensional floating-point observation state arrays (identical to the action arrays), two camera images (480×640 resolution, 3 color channels, 30fps frame rate), timestamps, frame indices, episode indices, sample indices, and task indices. This dataset is designed for robot control or imitation learning tasks, and supports both training and testing.